
An open-source ball-balancing robot that sees through a mirror.
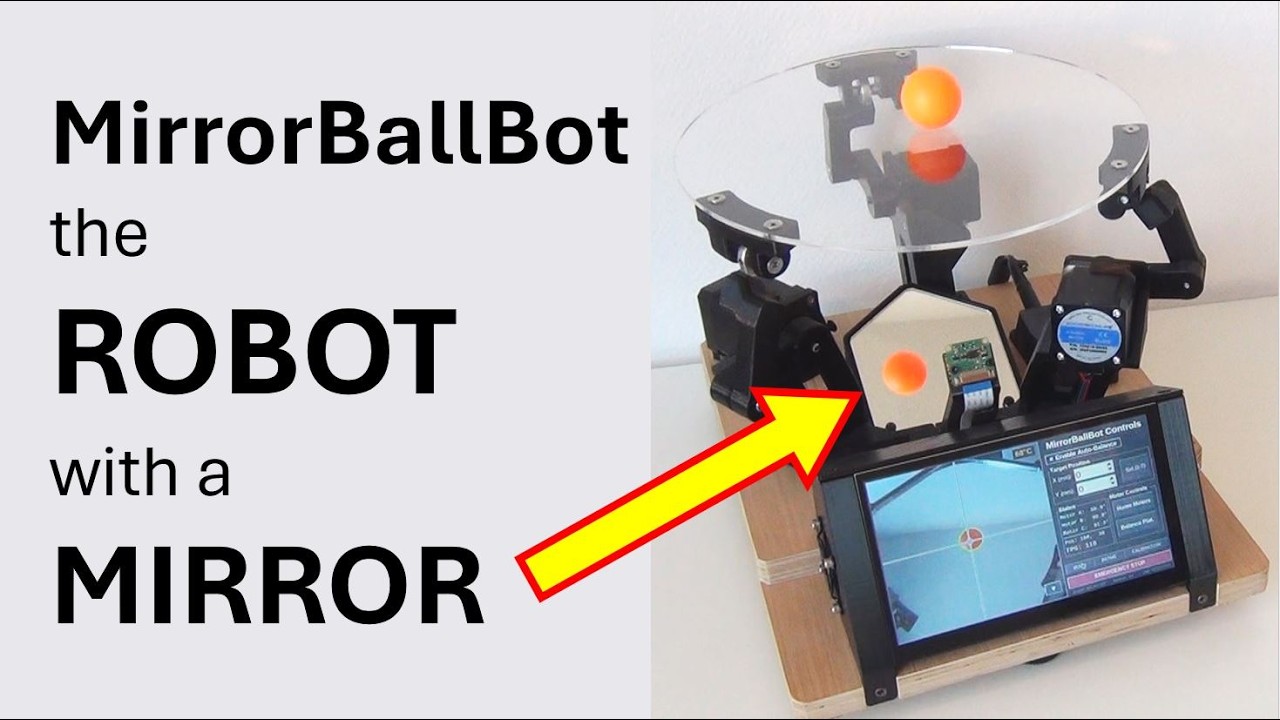
MirrorBallBot keeps a ball centred on a circular platform by tilting it with three stepper motors.
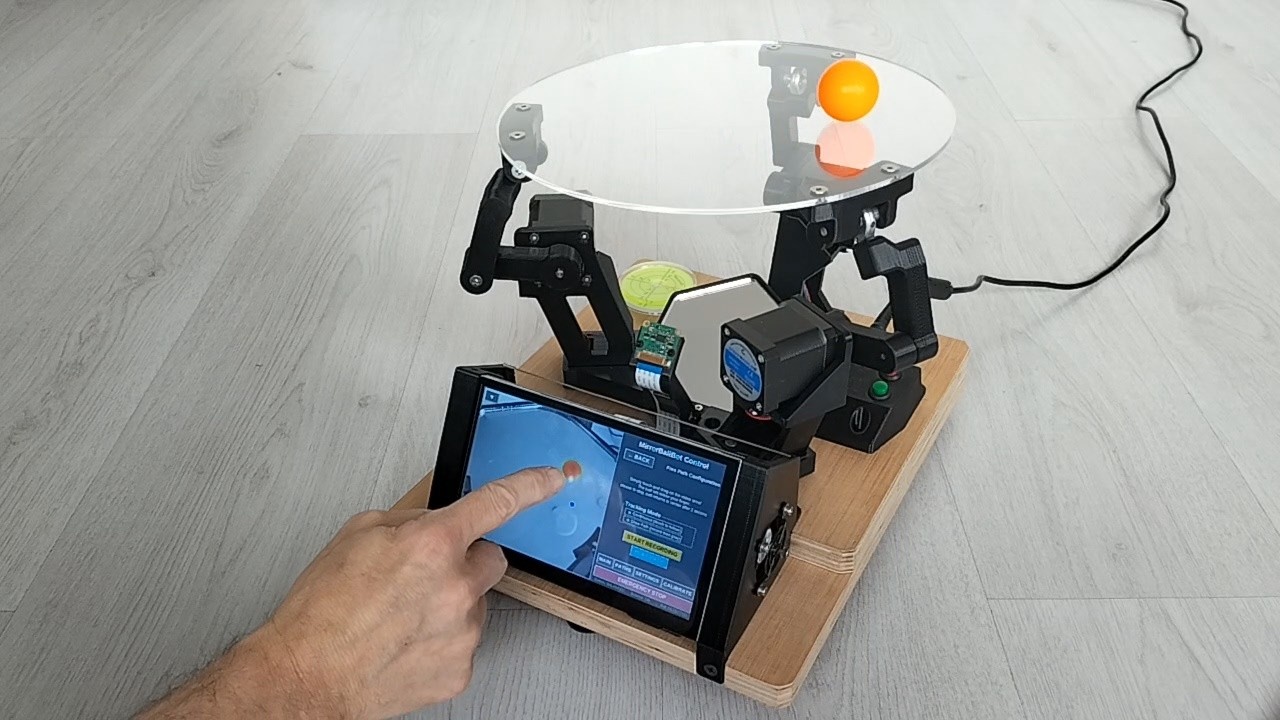
You can control the ball with your finger on a touchscreen, record paths, or let it auto-balance.
MirrorBallBot is fully open-source:
- two instruction manuals (QuickStartGuide and Reference Manual)
- stl and step files
- code
Fully 3D printable version (smaller footprint):


-
Vision system: Unlike most designs, it uses side-mounted camera pointing at a mirror (inclined 27°). By considering the same camera and same robot height, the mirror concept increases the Field of View by 58%. This allows for a larger platform while keeping the robot compact.
-
Finger follower: The ball follows, in real time, the finger's position on the touchscreen.
- Two versions available: Wooden base or fully 3D-printable.
- Touchscreen GUI: 7" DSI display with full control interface.
- Real-Time Video Feed: Live camera images displayed directly on screen.
- Autonomous Auto-Balance: Keeps the ball centred.
- Finger-Follow Mode: Drag your finger across the screen to guide the ball.
- Predefined Paths: Execute geometric patterns (Square, Circle, Infinity, Triangle, Line).
- Record & Replay: Draw custom paths with your finger to record and loop them.
- Interactive PID Tuning: Adjust control loop parameters via the GUI in real time.
- Automatic HSV Calibration: Instantly adapts to different ball colours and ambient lighting.
- Sensorless Homing: Uses TMC2209 StallGuard, no physical limit switches required.
- Active Thermal Management: PWM controlled cooling fans with automated temperature monitoring.
- Detection: The camera looks at a mirror placed underneath the transparent platform, detects the ball via HSV thresholding, the ball position is retrieved. This flow works at more than 110 FPS.
- Calculation: The ball position is compared to the target, and via a PID controller the new platform angle is calculated.
- Communication: The Raspberry Pi 4 sends the information (speed and number of steps) to the three RP2040-Zero, via a custom I2C protocol.
- Actuation: The three RP2040-Zero decode the I2C command to speed, direction and number of steps, and load them into the PIO buffer. Finally, the steppers move the platform. The platform actuation works at 17~25Hz.
- Raspberry Pi 4: Vision processing, PID control, GUI, and I2C Master.
- 3x RP2040-Zero: Motion execution, I2C Slaves, and hardware-precise PIO step generation.
- 3x TMC2209: Silent stepper drivers configured for Sensorless homing.
- 3x NEMA17: Stepper motors executing the platform tilts.

| Component | Qty |
|---|---|
| Raspberry Pi 4 2GB (1Gb is sufficient) | 1 |
| RP2040-Zero | 3 |
| TMC2209 stepper driver | 3 |
| NEMA17 stepper motor | 3 |
| PiCamera 3 Wide | 1 |
| 7" DSI touchscreen (800x480) | 1 |
| MirrorballBot custom PCB | 1 |
| XL4015 step-down converter | 1 |
| 20V 5A power supply | 1 |
Looking for the full Bill of Materials? A comprehensive, itemized BOM with all the components and raw material specs is available in the full documentation.
The Quick Start Guide provides the essential information to build the robot, as a PDF file of approx. 50 pages.
The Reference Manual provides detailed information, yet the ~170 page PDF file could intimidate at first glance. It provides exhaustive coverage of:
- BOM
- Wooden base or fully 3D printable version.
- 3D printing and acrylic laser cutting.
- PCB assembly & soldering maps (250+ pads).
- Detailed step-by-step mechanical assembly (36 steps with photos).
- Software environment setup and configuration parameters.
- GUI operation, PID tuning, and troubleshooting/QA.
| Manual | Best for |
|---|---|
| Quick Start Guide | Most makers. It's concise, action-oriented, and will get you from zero to a working robot with minimal friction. |
| Reference Manual | When you want to understand why something works, encounter an issue not covered in the Quick Start Guide, or are curious about the design process, custom I2C protocol, or PID controller theory. |
Recommendation: Start with the Quick Start Guide. Follow the steps, and refer to the Reference Manual only when you need more detail.
Download the manuals from the /doc folder:
- Decide if wooden base or fully 3D-printed version. If wooden, CNC or route the base.
- 3D print all parts (0.2mm layer, 30% infill, no supports, suggested PETG).
- Laser cut acrylic (translucent plate + mirror).
- Assemble the MirrorBallBot PCB (250+ solder pads).
- Flash each RP2040-Zero with MicroPython v1.24 Pimoroni Tiny2040 uf2 firmware (https://micropython.org/download/PIMORONI_TINY2040/).
- Copy the MicroPython file to the RP2040-Zero boards (files at https://github.com/AndreaFavero71/mirrorballbot/tree/main/rp2040).
- Set up the Raspberry Pi:
- Flash a 32-bit Desktop OS (Trixie, or Bookworm) into a microSD.
git clone https://github.com/AndreaFavero71/mirrorballbot.git cd mirrorballbot/src bash mbb_install.sh - Set the XL4015 voltage (OUT+) to 5.1V.
- Set the drivers Vref according to the steppers' rated current.
- Run first tests before full assembly; This includes checking the motor direction (it can be reversed via a settings in mbb_settings.json).
- Full assembly following the step-by-step guide.
- Calibrations:
- Camera inclination (centre the camera view to the platform centre).
- Sensorless homing calibration.
- Ball colour calibration.
- PID tuning.
- Enjoy the robot!
- Provide feedback 😄
After assembly, place the ball on the middle of the platform, and start the GUI via a Graphical Remote Desktop Client, like VNCViewer:
cd ~/mirrorballbot/src
python3 mbb_gui.py
Differently, just tap the MirrorBallBot icon on the 7-inch Raspberry Pi Desktop (the icon got automatically installed on the desktop, thanks to the mbb_install.sh).
The GUI will open on the touchscreen.
Auto-Balance should already be active, and the robot will start balancing the ball.
If the ball is not wrapped by a green contour, set an indicative ball size and run the AUTO calibration for the colors.
- 3D printer (Minimum 210x210 mm bed capacity).
- Laser cutter or CNC (for acrylic parts; commercial laser-cutting services work great).
- Hand router or CNC (for carving wire channels in the wood base), unless you prefer the fully 3D printable version.
- Soldering iron and basic electronics assembly tools.
- Multimeter (essential for driver Vref tuning).
- Screwdrivers and ball-end Allen keys.
- Computer with SD card reader.
- Solid foundational skills in DIY mechatronics and Python scripting.
MirrorBallBot has been designed as an open-source project. This means I purchased most of the parts myself, just as anyone else would, and invested a considerable amount of time to make a fairly complex robot as easy as possible to reproduce.
I also greatly appreciate companies that support my hobby, by providing parts or services free of charge. The companies below generously sponsored components used in the MirrorBallBot project:
- Thanks to PCBWay for sponsoring the MirrorBallBot PCB [https://www.pcbway.com/]
- Thanks to ELECROW for sponsoring the 7" DSI touchscreen [https://www.elecrow.com/7-inch-800-480-dsi-display-touch-screen-with-bracket-compatible-with-raspberry-pi.html?idd=5]
I would also like to thank ELECROW and PCBWay for believing in this project. They both offered their support when MirrorBallBot was still just an idea, with no guarantee that it would ever reach the stage of becoming a published project.
The low-level I2C responder used on the RP2040 (rp2040/i2c_responder.py) is derived from two upstream sources:
- a Raspberry Pi forum post by danjperron (https://forums.raspberrypi.com/viewtopic.php?t=302978&start=50)
- the epmoyer/I2CResponder repository (https://github.com/epmoyer/I2CResponder), based on danjperron post.
Both are credited in the file header and in LICENSE.txt.
If you decide to build your own MirrorBallBot, I would love to hear about it! Please open an issue, share your build photos, or submit feedback to let me know how your robot turned out.
MirrorBallBot uses a combination of open licenses:
- Source code (Raspberry Pi Python, RP2040 MicroPython): GPL-3.0, with two exceptions:
TMC_2209_uart.pyandTMC_2209_driver.pyremain GPL-3.0, preserving the original authors' notices.rp2040/i2c_responder.pyderives from unlicensed upstream code (danjperron forum post and epmoyer/I2CResponder). It carries no license and is included with credit to both authors.
- CAD files, 3D models, manuals, and documentation: CC BY-NC-SA 4.0 (non-commercial, share-alike).
Full texts are in the LICENSES/ folder; LICENSE.txt summarises the mapping.