

English | 日本語
- This repository provides MuJoCo-based robot simulation assets for Hakoniwa.
- It supports ROS/URDF-derived robot models, including TurtleBot3 Burger.
- It connects C++ MuJoCo simulators and Python controllers / visualizers through Hakoniwa PDU.
- It includes a TurtleBot3 sample with gamepad control and 2D LiDAR
LaserScan-compatible PDU output. - It includes configurable LiDAR noise profiles such as
LDS-01-like andURG-04LX-UG01-equivalent settings. - It includes forklift samples with context save/restore and RD-light handoff as advanced examples.
- Compact JSON is the default for both C++ and Python (
hakoniwa-pdu >= 1.6.1).
Use these entry points first. The rest of this README includes advanced notes and experimental background.
| Goal | Read / Run |
|---|---|
| Build the repository | Prerequisites, then Setup |
| Diagnose the local environment | ./doctor.bash |
| Run TurtleBot3 with gamepad and LiDAR | Quick Start: TurtleBot3 + 2D LiDAR |
| Run the forklift sample | Quick Start: Forklift |
| Browse documentation by category | docs/README.md |
| Try small sensor examples | examples/sensors/README.md |
| Try color-camera PNG capture | examples/sensors/color_camera/README.md |
| Try MJCF position / velocity actuators | examples/actuators/joint/README.md |
| Try Unitree Go1 MJCF joint I/O | examples/actuators/unitree_go1/README.md |
| Learn the sensor/actuator workflow | docs/guide/sensor-actuator-user.md |
| Understand JSON config structure | docs/guide/json-config.md |
| Learn MJCF XML / JSON authoring and standalone checks | docs/guide/mjcf-json-authoring.md |
| Understand sensor/actuator PDU design | docs/spec/sensor-actuator-design.md |
| Understand sensor/actuator config schemas | docs/spec/sensor-actuator-config-schema.md |
| Read RD-light / context save-restore notes | docs/guide/forklift-context-rd.md |
Current standalone examples:
examples/sensors/ultrasonic/        ultrasonic range sensor + viewer ray
examples/sensors/color_camera/      RGB camera sensor + PNG capture
examples/actuators/joint/           MuJoCo position / velocity joint actuators
examples/actuators/unitree_go1/     Unitree Go1 MJCF joint I/O smoke
- TurtleBot3 + 2D LiDAR / sensor noise demo:
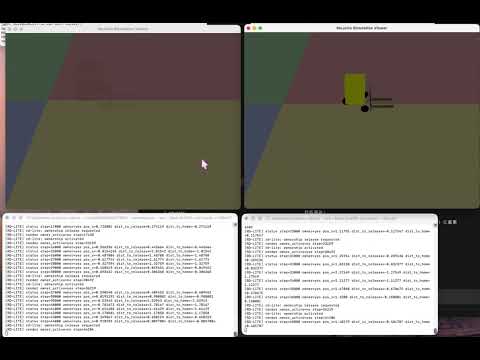
- Runtime handoff demo (RD-light, dual forklift assets):
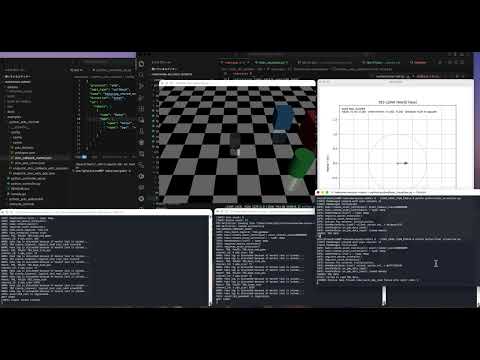
This demo shows a TurtleBot3 Burger running on MuJoCo with a 2D LiDAR simulation connected through Hakoniwa PDU.
The point is not only to visualize LiDAR point clouds, but also to reproduce differences in sensor noise characteristics.
- With TurtleBot3's standard
LDS-01, the point cloud is visibly noisier - With the
URG-04LX-UG01-like profile, obstacle contours appear much clearer
One important Sim2Real theme in Hakoniwa is to represent the practical difference users experience when changing sensors, not just robot motion alone.
Configuration:
- ROS-derived TurtleBot3 model executed on MuJoCo
- 2D LiDAR simulated by raycast using the selected sensor profile
- Scan frequency, angular range, angular resolution, and noise model are loaded from JSON
- Output published as
LaserScanPDU on Hakoniwa - Point cloud visualized by a Python visualizer
- Noise differences reproduced for
LDS-01andURG-04LX-UG01-equivalent settings
This is an advanced experimental demo.
It runs two MuJoCo forklift assets and performs single-node ownership handoff with context save/restore.
- RD-light is an advanced / experimental handoff demo
- It is not RD-full
- See docs/guide/forklift-context-rd.md and rd-design.md for details
Included:
- MuJoCo robot models
- Hakoniwa-integrated C++ simulators
- Python controllers
- Python visualizers
- PDU configs
- sensor configs
- reusable sensor components under
src/sensors/ - reusable actuator components under
src/actuator/ - standalone feature examples under
examples/ - forklift context save/restore
- RD-light as an advanced demo
Directory map:
models/: MuJoCo XML modelsconfig/: PDU JSON configsconfig/sensors/: LiDAR / sensor spec JSONconfig/actuator/: actuator binding JSONsrc/: C++ simulator implementationsrc/sensors/: sensor implementationssrc/actuator/: joint actuator implementationinclude/hakoniwa/pdu/: PDU converters and adapterspython/: Python controllers / visualizersexamples/: small standalone examples for individual featurestests/sensors/: focused sensor unit / smoke testsdocker/: Docker scriptslogs/: generated logstmp/: generated state files
Hakoniwa PDU is the hub, and MuJoCo (C++) communicates with Python controllers / visualizers over that contract.
- Hakoniwa: synchronization and PDU runtime
- MuJoCo C++ Asset: physics stepping + PDU read/write
- Python Controller / Visualizer: input and inspection tools
- PDU JSON: contract of channels/types/sizes
+-----------------------------+      PDU (shared contract)      +----------------------+
| Python Controller / Viewer  |  <----------------------------> | MuJoCo C++ Simulator |
| (gamepad / visualizer)      |                                  | (tb3_sim / forklift) |
+--------------+--------------+                                  +----------+-----------+
               |                                                            |
               |                        Hakoniwa runtime                     |
               +------------------------(sync / mmap / PDU)-----------------+
This is the shortest path to verify MuJoCo + Hakoniwa + TurtleBot3 + gamepad + LiDAR.
Demo choices:
- Interactive:
tb3-demo.bashor the manualtb3_sim+tb3_gamepad.pyflow. Use this when a gamepad is available. - Automated:
tb3-mbody-demo.bash. Use this for scripted route demos, CI-like checks, or AI-agent execution where no joystick is available. - Multi-process mirror:
tb3-dual-mirror-demo.bash. Use this to run two independently simulated TurtleBot3 processes where each process owns one real robot and mirrors the other robot through pose PDU. - MBody-generated models:
tb3-mbody-demo.bashwithHAKO_TB3_MODEL=burger,waffle, orwaffle_pi.
Prepare 4 terminals.
- simulator
./src/cmake-build/main_for_sample/tb3/tb3_sim- gamepad controller
python python/tb3_gamepad.pyFor a joystick-free scripted route demo, use:
python python/tb3_route_demo.py --pattern squareTo run the same TB3 runtime against the minimal world generated by
hakoniwa-mbody-registry, use the launcher-based MBody demo:
bash tb3-mbody-demo.bashThis uses hakoniwa-pdu's launcher to start the simulator, issue
hako-cmd start, and run a joystick-free scripted route demo. It defaults to
Burger with the MuJoCo viewer, LiDAR plot, trajectory trail, and a figure8
route.
Useful variants:
HAKO_TB3_MODEL=waffle HAKO_TB3_ROUTE_PATTERN=figure8 bash tb3-mbody-demo.bash
HAKO_TB3_MODEL=waffle_pi HAKO_TB3_ROUTE_PATTERN=figure8 bash tb3-mbody-demo.bash
HAKO_TB3_ENABLE_VIEWER=0 HAKO_TB3_ROUTE_PATTERN=showcase bash tb3-mbody-demo.bash
HAKO_TB3_ROUTE_PATTERN=dance HAKO_TB3_ENABLE_VIEWER=1 bash tb3-mbody-demo.bash
HAKO_TB3_HOLD_SEC=15 bash tb3-mbody-demo.bash
ACTIVATE_MODE=activate-only bash tb3-mbody-demo.bash
For a multi-process mirror demo, use:
bash tb3-dual-mirror-demo.bashThis launcher starts four processes:
- Process A: real Burger + mirrored Waffle, Conductor owner, Viewer enabled.
- Process B: real Waffle + mirrored Burger, Conductor disabled, Viewer disabled.
- Controller A: drives
TB3_BURGER/hako_cmd_game. - Controller B: drives
TB3_WAFFLE/hako_cmd_game. - LiDAR visualizers: show
TB3_BURGER/laser_scanandTB3_WAFFLE/laser_scan.
Process A's viewer is the intended observation point. It shows the local real
Burger and the remote Waffle mirrored from TB3_WAFFLE/base_link_pos. Process B
still runs real Waffle physics and publishes TB3_WAFFLE/base_link_pos, but it
does not open a viewer. Two LiDAR plot windows are opened side by side, one for
each real robot's laser_scan PDU. Only one simulator process should own
Conductor startup.
Use the manual commands below when debugging each process separately.
./src/cmake-build/main_for_sample/tb3/tb3_sim_burgertb3_sim_burger defaults to config/assets/tb3-mbody-burger-asset.json,
runs without the viewer, omits the camera component, and maps the generated
wheel <velocity> actuators through config/actuator/joint/tb3_mbody_*.json.
Set HAKO_TB3_ENABLE_VIEWER=1 to show the viewer.
For a visual Burger demo, run:
HAKO_TB3_ENABLE_VIEWER=1 ./src/cmake-build/main_for_sample/tb3/tb3_sim_burger
/usr/local/hakoniwa/bin/hako-cmd start
python3.12 python/tb3_lidar_visualizer.py
python3.12 python/tb3_route_demo.py --pattern figure8 --forward-sec 5.0 --linear-axis 0.6 --yaw-axis 0.85 --hold-sec 6
For the MBody-generated TurtleBot3 Waffle runtime demo, use:
./src/cmake-build/main_for_sample/tb3/tb3_sim_waffle
/usr/local/hakoniwa/bin/hako-cmd start
python3.12 python/tb3_route_demo.py --pattern figure8 --linear-axis 0.6 --yaw-axis 0.7
tb3_sim_waffle defaults to config/assets/tb3-mbody-waffle-asset.json,
runs without the viewer, and uses a Waffle wheel separation default of 0.288.
Set HAKO_TB3_ENABLE_VIEWER=1 to show the viewer.
For the MBody-generated TurtleBot3 Waffle Pi runtime demo, use:
./src/cmake-build/main_for_sample/tb3/tb3_sim_waffle_pi
/usr/local/hakoniwa/bin/hako-cmd start
python3.12 python/tb3_route_demo.py --pattern figure8 --linear-axis 0.6 --yaw-axis 0.7
tb3_sim_waffle_pi defaults to
config/assets/tb3-mbody-waffle-pi-asset.json, runs without the viewer, and
uses a Waffle-compatible wheel separation default of 0.288.
Set HAKO_TB3_ENABLE_VIEWER=1 to show the viewer.
- LiDAR visualizer
python python/lidar_visualizer.py- start trigger
hako-cmd startTo switch LiDAR spec:
./src/cmake-build/main_for_sample/tb3/tb3_sim config/sensors/lidar/lds-01.json
./src/cmake-build/main_for_sample/tb3/tb3_sim config/sensors/lidar/lds-02.json
./src/cmake-build/main_for_sample/tb3/tb3_sim config/sensors/lidar/urg-04lx-ug01.jsonThis is the shortest path for the forklift unit sample.
Prepare 3 terminals.
- simulator
./src/cmake-build/main_for_sample/forklift/forklift_unit_sim- Python controller
python -m python.forklift_simple_auto config/forklift-unit-compact.json \
--forward-distance 2.0 --backward-distance 2.0 --move-speed 0.7- start trigger
hako-cmd startFor compatibility, controll.bash is temporarily kept and internally calls control.bash.
The normal standalone build uses the Hakoniwa Core and PDU Endpoint submodules pinned by this repository.
git clone https://github.com/hakoniwalab/hakoniwa-mujoco-robots.git
cd hakoniwa-mujoco-robots
git submodule update --init --recursive
Choose one writable install prefix and use it consistently for Core and Endpoint:
export HAKONIWA_INSTALL_PREFIX="${HAKONIWA_INSTALL_PREFIX:-$HOME/.local/hakoniwa}"
export HAKONIWA_CORE_ROOT="$HAKONIWA_INSTALL_PREFIX"
export HAKONIWA_PDU_ENDPOINT_ROOT="$HAKONIWA_INSTALL_PREFIX"Build and install Hakoniwa Core first:
python thirdparty/hakoniwa-core-pro/tools/hako.py doctor \
  --config config/build/hakoniwa-core-runtime.yaml
python thirdparty/hakoniwa-core-pro/tools/hako.py build \
  --config config/build/hakoniwa-core-runtime.yaml \
  --install-dir "$HAKONIWA_INSTALL_PREFIX"
python thirdparty/hakoniwa-core-pro/tools/hako.py install \
  --config config/build/hakoniwa-core-runtime.yaml \
  --install-dir "$HAKONIWA_INSTALL_PREFIX"
The Core profile config/build/hakoniwa-core-runtime.yaml keeps the pinned runtime capacity while disabling Core component tests that are not required by this consumer build.
This repository's runtime configs use Hakoniwa shared memory. Therefore
hakoniwa-pdu-endpoint must be built with Hakoniwa Core support enabled.
Use the repository-owned build profile:
config/build/hakoniwa-pdu-endpoint-core.yaml
Then build and install Endpoint:
python thirdparty/hakoniwa-pdu-endpoint/tools/hako.py doctor \
  --config config/build/hakoniwa-pdu-endpoint-core.yaml

python thirdparty/hakoniwa-pdu-endpoint/tools/hako.py build \
  --config config/build/hakoniwa-pdu-endpoint-core.yaml

python thirdparty/hakoniwa-pdu-endpoint/tools/hako.py install \
  --config config/build/hakoniwa-pdu-endpoint-core.yaml \
  --install-dir "$HAKONIWA_INSTALL_PREFIX"
The Endpoint repository's default hakoniwa-build.yaml intentionally keeps
features.hakoniwa_core: false because TCP/UDP/WebSocket/Storage and similar
Core-free uses do not require Hakoniwa Core. Do not change that default for this
repository. The MuJoCo Robots profile explicitly requests
features.hakoniwa_core: true and disables Endpoint benchmarks that are not
part of this runtime dependency.
Python controllers and visualizers under python/ are intended to run with
Python 3.12. They use two Python-side Hakoniwa pieces:
hakopy: Hakoniwa core Python binding installed byhakoniwa-core-pro.hakoniwa-pdu: PDU message types, serializers, andPduManagerinstalled withpip.
Install hakoniwa-core-pro first, following its README. The core install step
installs the hakopy Python binding. Newer installer flows may also write a
Hakoniwa environment file; source it when it exists:
test -f ${HAKONIWA_INSTALL_PREFIX}/env.bash && source ${HAKONIWA_INSTALL_PREFIX}/env.bashIf that file does not exist, set the equivalent environment variables manually when needed:
export HAKONIWA_HOME="${HAKONIWA_INSTALL_PREFIX}"
export PATH="${HAKONIWA_HOME}/bin:${PATH}"
export CMAKE_PREFIX_PATH="${HAKONIWA_HOME}:${CMAKE_PREFIX_PATH:-}"
export PKG_CONFIG_PATH="${HAKONIWA_HOME}/lib/pkgconfig:${PKG_CONFIG_PATH:-}"
Then use the same Python 3.12 executable for checks, installs, and scripts:
python3.12 -c "import hakopy; print(hakopy)"
python3.12 -m pip install --upgrade "hakoniwa-pdu>=1.6.1"
If Python 3.12 is managed by a version manager such as pyenv, use the same resolved executable consistently:
PYTHON_CMD="$(command -v python3.12)" ./doctor.bash
"$(command -v python3.12)" python/tb3_route_demo.py --pattern square
Check the installed version:
python3.12 -m pip show hakoniwa-pduThis is required for commands such as:
python3.12 python/tb3_gamepad.py
python3.12 python/tb3_route_demo.py --pattern square
python3.12 -m python.forklift_simple_auto config/forklift-unit-compact.json
python3.12 python/lidar_visualizer.py- macOS:
brew install glfw - Ubuntu:
sudo apt-get update
sudo apt-get install -y libgl1 libgl1-mesa-dri libglx-mesa0 mesa-utils libglfw3-devAfter the Core and Core-enabled Endpoint packages above are installed:
python tools/hako.py doctor
python tools/hako.py build- MuJoCo version is managed by
MUJOCO_VERSION.txt. tools/hako.pyis the normal user-facing build entry point. The legacybuild.bash/build-win.ps1drivers remain underneath for platform-specific compatibility.doctor.bashalso verifies that the installed Endpoint package exportshakoniwa_pdu_endpoint::core_callback; a Core-free Endpoint install is reported before runtime.
TurtleBot3 is a convenient end-to-end check because its Endpoint configuration
uses protocol: "shm".
./src/cmake-build/main_for_sample/tb3/tb3_simA Core-enabled Endpoint should allow the simulator to pass Endpoint creation. In particular, it must not fail with:
protocol 'shm' requested but Hakoniwa core support is disabled
The same Core-enabled Endpoint contract is used by the other Hakoniwa SHM examples in this repository.
Run this before ./build.bash when setting up a new machine:
./doctor.bashThe doctor command checks local prerequisites without building:
- CMake and Git
hakoniwa-core-propackage confighakoniwa-pdu-endpointpackage confighakoniwa-pdu >= 1.6.1for Python toolsglfw3MUJOCO_VERSION.txt
Fix reported failures first, then run ./build.bash.
The Windows build is intended to run after hakoniwa-core-pro and hakoniwa-pdu-endpoint have already been built and installed on Windows.
Prerequisites:
hakoniwa-core-prois installed under a prefix such asC:\project\hakoniwa-core-pro\installhakoniwa-pdu-endpointis installed under a prefix such asC:\project\hakoniwa-pdu-endpoint\installvcpkgpackages for Windows are available underC:\project\vcpkg\installed\x64-windows- Run the build from Windows PowerShell when possible
PowerShell:
.\build-win.ps1 -Clean `
  -HakoniwaCoreRoot C:\project\hakoniwa-core-pro\install `
  -HakoniwaPduEndpointRoot C:\project\hakoniwa-pdu-endpoint\install `
  -ExtraPrefixPaths C:\project\vcpkg\installed\x64-windows
WSL / Git Bash wrapper:
./build-win.bashNotes:
build-win.ps1runs a preflight check before CMake and reports missing install roots, missing package config files, and missingglfw3/vcpkgprefix information.- The script configures with
-S src, matching the existing Unix build layout. HakoniwaCoreRootis forwarded toHAKONIWA_INSTALL_PREFIX.HakoniwaPduEndpointRootis forwarded toHAKONIWA_PDU_ENDPOINT_PREFIX.ExtraPrefixPathsis used to resolve Windows packages such asglfw3and transitive dependencies required byhakoniwa_pdu_endpoint.HakoniwaPduEndpointRootmust point to an installed prefix created bycmake --install, not a build directory such asbuild-winorbuild-shared. Thehakoniwa_pdu_endpointConfig.cmakegenerated in the build tree is not directly consumable by this project.- If you build
hakoniwa-pdu-endpointyourself, install it first:
cmake --install C:\project\hakoniwa-pdu-endpoint\build-win --config Release --prefix C:\project\hakoniwa-pdu-endpoint\install- Successful outputs are generated under
build-win/Release/mujoco-common.lib. - Successful outputs are generated under
build-win/sensors/Release/msensors.lib. - Successful outputs are generated under
build-win/main_for_sample/forklift/Release/forklift_sim.exe. - Successful outputs are generated under
build-win/main_for_sample/forklift/Release/forklift_unit_sim.exe. - Successful outputs are generated under
build-win/main_for_sample/tb3/Release/tb3_sim.exe. - On Windows, runtime DLLs such as
hakoniwa_pdu_endpoint.dllare copied next to each.exeafter build. - If Windows reports
forklift_simulation_loop.obj: Permission denied, that is a file lock issue, not a source code issue. CloseMSBuild.exe,cl.exe, ordevenv.exeand rebuild. - The Python endpoint binding is built separately from the C++ samples. For
python/tb3_gamepad.py, build the vendoredthirdparty/hakoniwa-pdu-endpointPython runtime with Hakoniwa core support enabled:
cd .\thirdparty\hakoniwa-pdu-endpoint
.\build-python-win.ps1 `
  -Clean `
  -BuildNative `
  -BuildFfi `
  -EnableHakoniwaCore `
  -HakoniwaCoreRoot C:\project\hakoniwa-core-pro\install `
  -BuildDirName build-win `
  -Configuration Release `
  -PythonCommand python `
  -ToolchainFile C:\project\vcpkg\scripts\buildsystems\vcpkg.cmake `
  -VcpkgTriplet x64-windows `
-Platform x64python/tb3_gamepad.pyprefers the vendored Python package underthirdparty/hakoniwa-pdu-endpoint/python, so it will use the locally built runtime instead of a stale site-packages installation when both are present.
- Forklift:
./src/cmake-build/main_for_sample/forklift/forklift_sim- Forklift unit (no cargo, useful for auto-control tests):
./src/cmake-build/main_for_sample/forklift/forklift_unit_sim- TurtleBot3 (Hakoniwa asset + endpoint gamepad + 2D LiDAR):
./src/cmake-build/main_for_sample/tb3/tb3_sim- TurtleBot3 (switch LiDAR spec):
./src/cmake-build/main_for_sample/tb3/tb3_sim config/sensors/lidar/lds-01.json
./src/cmake-build/main_for_sample/tb3/tb3_sim config/sensors/lidar/lds-02.json
./src/cmake-build/main_for_sample/tb3/tb3_sim config/sensors/lidar/urg-04lx-ug01.json- Minimal auto control:
python -m python.forklift_simple_auto config/custom-compact.json- For unit model:
python -m python.forklift_simple_auto config/forklift-unit-compact.json --forward-distance 1.5 --backward-distance 1.5 --move-speed 0.7- API control sample:
python -m python.forklift_api_control config/safety-forklift-pdu-compact.json config/monitor_camera_config.json- Gamepad sample:
python -m python.forklift_gamepad config/custom-compact.json- TurtleBot3 gamepad control:
python python/tb3_gamepad.py- TurtleBot3 scripted route demo without a joystick:
python python/tb3_route_demo.py --pattern square- LiDAR visualizer:
python python/lidar_visualizer.py- Ultrasonic sensor example:
./src/cmake-build/examples/sensors/ultrasonic/ultrasonic-example- Color camera sensor example (
i/k/j/lmoves the camera,swrites a PNG from the viewer or terminal):
./src/cmake-build/examples/sensors/color_camera/color-camera-example- Joint actuator example (
a/dchanges position target,j/lchanges velocity target in the MuJoCo viewer):
./src/cmake-build/examples/actuators/joint/joint-actuator-exampleSee examples/README.md for the current example index.
The TurtleBot3 Burger sample includes a MuJoCo-based 2D LiDAR implementation.
Note:
-
models/tb3/turtlebot3_burger_world.xmlcurrently uses primitive geoms for the body, wheels, and LiDAR housing instead of external mesh files. -
This avoids runtime failures caused by machine-specific absolute mesh paths when running on Windows.
-
The wheel actuators are MuJoCo
<velocity>actuators. Gamepad input is converted to left / right wheel angular velocity targets before being written throughJointActuatorImpl. -
Linear velocity and yaw-rate targets are rate-limited before conversion to wheel angular velocities. Defaults include
HAKO_TB3_MAX_YAW_RATE=1.2,HAKO_TB3_MAX_LINEAR_ACCELERATION=0.1,HAKO_TB3_MAX_YAW_ACCELERATION=0.5, andHAKO_TB3_COMMAND_DEADZONE=0.1. -
The rear caster uses low friction so it does not dominate the drive-wheel behavior.
-
360-degree raycast
-
scan-frame generation based on the selected sensor profile
- e.g. 10 Hz / 100 ms for
urg-04lx-ug01.json - e.g. 5 Hz / 200 ms for
lds-01.jsonandlds-02.json
- e.g. 10 Hz / 100 ms for
-
LaserScan-compatible PDU published on Hakoniwa -
Point cloud inspection via Python visualizer
To avoid MuJoCo ray self / near-body interference around the LiDAR mount, the implementation detects self-geometry hits and retries raycasting just beyond the hit point. This avoids relying on a large fixed origin offset and keeps close obstacle perception more natural.
LiDAR behavior can be switched by sensor config JSON.
-
config/sensors/lidar/lds-01.json- noisy profile close to TurtleBot3 standard
LDS-01 - range: 0.12-3.5 m
- scan: 5 Hz, 1.0 deg resolution
- spec: https://emanual.robotis.com/docs/en/platform/turtlebot3/appendix_lds_01/
- noisy profile close to TurtleBot3 standard
-
config/sensors/lidar/lds-02.json- longer-range profile close to TurtleBot3
LDS-02 - range: 0.16-8.0 m
- scan: 5 Hz, 1.0 deg resolution
- spec: https://emanual.robotis.com/docs/en/platform/turtlebot3/appendix_lds_02/
- longer-range profile close to TurtleBot3
-
config/sensors/lidar/urg-04lx-ug01.json- cleaner profile based on Hokuyo
URG-04LX-UG01 - range: 0.02-5.56 m
- scan: 10 Hz, 0.3515625 deg resolution
- useful for comparing clearer obstacle contours against LDS-style profiles
- cleaner profile based on Hokuyo
Switch example:
./src/cmake-build/main_for_sample/tb3/tb3_sim config/sensors/lidar/lds-01.json
./src/cmake-build/main_for_sample/tb3/tb3_sim config/sensors/lidar/lds-02.json
./src/cmake-build/main_for_sample/tb3/tb3_sim config/sensors/lidar/urg-04lx-ug01.json
This is intended to capture a practical Sim2Real point: changing sensors changes perception quality.
Camera / depth / RGBD sensor components are available under include/sensors/camera/ and src/sensors/camera/.
- Depth conversion currently assumes the MuJoCo offscreen path where
mjr_readPixelsreturns an OpenGL-style depth buffer. - Camera rendering temporarily applies each sensor JSON
clip.near/farto MuJoCo's effective clip planes before reading RGB/depth pixels. - Camera / depth / RGBD / multicamera profiles under
config/sensors/camera/*.jsoncan be loaded into C++ configs. - The profile structure is documented in
config/sensors/schema/, and the JSON loader reuses the existingLoadConfig(config)validation path. - Camera unit tests live under
tests/sensors/camera/unit/and cover config loader, PDU converter, and local depth encoding. - These unit tests do not require an OpenGL render context and are intended to run in CI.
- This path has been smoke-tested with fixed-camera box scenes at
0.2,0.5,1.0,2.0,5.0, and9.0meters. - The smoke test also checks several image positions, multiple horizontal FOV settings, and clip-range NaN masking.
- Render smoke tests live under
tests/sensors/camera/smoke/and require MuJoCo + OpenGL, so they are intended for local/manual runs or dedicated CI. - It is still not claimed to be fully validated for arbitrary scenes such as oblique geometry, extreme camera setups, or alternative depth-map conventions.
Reusable sensor components live under src/sensors/, with JSON profiles under config/sensors/ and schemas under config/sensors/schema/.
PDU converters and adapters live under include/hakoniwa/pdu/.
Design and schema references:
- Sensor/Actuator User Guide
- JSON Config Guide
- MJCF / JSON Authoring Guide
- Sensor/Actuator PDU Design
- Sensor/Actuator Config Schemas
Current sensor areas:
- camera / depth / RGBD / multicamera
- color camera PNG example
- 2D LiDAR
- ultrasonic range
- IMU
- joint state
- odometry
- TF
- noise helpers
- debug ray visualization
The standalone examples are intentionally smaller than the TurtleBot3 and forklift demos. They are useful for checking one feature at a time:
- examples/README.md
- examples/sensors/README.md
- examples/sensors/ultrasonic/README.md
- examples/sensors/color_camera/README.md
- examples/actuators/README.md
- examples/actuators/joint/README.md
Sensor unit tests are optional build targets:
cmake -S src -B src/cmake-build -DHAKO_BUILD_SENSOR_TESTS=ON
cmake --build src/cmake-build --target run_sensor_unit_tests
Camera render smoke tests require a MuJoCo / OpenGL runtime:
cmake -S src -B src/cmake-build -DHAKO_BUILD_CAMERA_SMOKE_TESTS=ON
cmake --build src/cmake-build --target camera_smoke_testsCreate image:
bash docker/create-image.bashRun:
bash docker/run.bashBuild in container:
bash build.bashNotes:
- Ubuntu + Docker: GUI supported
- macOS + Docker: treat as headless recommended
HAKO_DOCKER_GUI=off bash docker/run.bashRun the environment doctor first:
./doctor.bashFix any FAIL lines, then run:
./build.bashhakoniwa-pdu does not provide hakopy. hakopy is the Python binding built
and installed by hakoniwa-core-pro, and this repository expects Python 3.12
for Python-side Hakoniwa tools.
The most common cause is a Python environment mismatch. These must all refer to the same Python 3.12 environment:
- the Python used when
hakoniwa-core-proinstalledhakopy - the Python used to run
python3.12 -m pip install hakoniwa-pdu - the Python used to run scripts such as
python/tb3_route_demo.py
First install hakoniwa-core-pro following its README, then check that
hakopy is visible to Python 3.12:
test -f ${HAKONIWA_INSTALL_PREFIX}/env.bash && source ${HAKONIWA_INSTALL_PREFIX}/env.bash
python3.12 -c "import hakopy; print(hakopy)"
Then install hakoniwa-pdu into that same Python:
python3.12 -m pip show hakoniwa-pdu
python3.12 -m pip install --upgrade "hakoniwa-pdu>=1.6.1"
If import hakopy fails, reinstall or rebuild hakoniwa-core-pro with Python
3.12 available, then re-run the install step. ./doctor.bash prints the Python
executable it checks.
If you want to check a specific Python environment, pass PYTHON_CMD:
PYTHON_CMD=/path/to/python3.12 ./doctor.bash
/path/to/python3.12 -m pip install --upgrade "hakoniwa-pdu>=1.6.1"Build/install both dependencies through the manifest-driven hako.py flow in
Prerequisites, then re-run python tools/hako.py doctor.
The Endpoint install must export hakoniwa_pdu_endpoint::core_callback; the
Core-free Endpoint default is not sufficient for this repository's SHM configs.
Use config/build/hakoniwa-pdu-endpoint-core.yaml.
If the packages are installed under a custom prefix, set:
export HAKONIWA_CORE_ROOT=/path/to/hakoniwa/install
export HAKONIWA_PDU_ENDPOINT_ROOT=/path/to/hakoniwa/installInstall GLFW:
brew install glfwUbuntu:
sudo apt-get install -y libglfw3-devBy default, it writes ./camera_color_sample.png relative to the directory where you run the command. You can pass an explicit output path as the third argument.
No. The main robot demos use the viewer by default, and the standalone sensor / actuator examples are designed for interactive viewer use. Some tests and config checks do not need a viewer.
For Docker on macOS, use headless mode:
HAKO_DOCKER_GUI=off bash docker/run.bashAdvanced forklift context save/restore and RD-light notes are split out of the top-level README.
- Forklift Context Save/Restore And RD-light
- RD design notes
- Sensor/Actuator PDU Design
- Sensor/Actuator Config Schemas
The top-level README keeps only the entry points, setup, and sample commands. Use the advanced documents when you need restore evidence, RD-light handoff details, or continuity evaluation workflow.
src/main_for_sample/forklift/main.cpp: forklift basic integrationsrc/main_for_sample/forklift/main_unit.cpp: unit model verificationsrc/main_for_sample/tb3/main.cpp: TurtleBot3 sample (Hakoniwa asset / endpoint / 2D LiDAR)python/tb3_gamepad.py: TurtleBot3 Python controller asset (PS4/DualSense)python/tb3_route_demo.py: TurtleBot3 scripted route controller for joystick-free demospython/lidar_visualizer.py: generic LiDAR visualizer (world view)examples/README.md: standalone example indexexamples/sensors/ultrasonic/README.md: ultrasonic sensor exampleexamples/sensors/color_camera/README.md: color camera PNG exampleexamples/actuators/joint/README.md: MJCF-native position / velocity joint actuator examplesrc/sensors/: reusable sensor componentsinclude/hakoniwa/pdu/: PDU conversion and endpoint adapter helpersdocs/spec/sensor-actuator-design.md: sensor/actuator PDU design notesdocs/spec/sensor-actuator-config-schema.md: sensor/actuator config schema guideconfig/sensors/lidar/lds-01.json: TurtleBot3 LDS-01-like noisy LiDAR profileconfig/sensors/lidar/lds-02.json: TurtleBot3 LDS-02-like longer-range LiDAR profileconfig/sensors/lidar/urg-04lx-ug01.json: Hokuyo URG-04LX-UG01-like cleaner LiDAR profileconfig/sensors/ultrasonic/lego-spike-distance-sensor.json: ultrasonic range sensor profile used by the standalone exampleconfig/sensors/color_camera/simple-color-camera.json: color camera profile used by the PNG example
- Read CONTRIBUTING.md before opening an issue or pull request.
- Coding agents should also read AGENTS.md.
- For setup failures, include
./doctor.bashoutput in the issue. - For viewer examples, mention whether the behavior was manually checked.
- Windows run flow (build/run/log)
- Keep compact-only runtime checks and diagnostics (
hakoniwa-pduversion / PDU resolution) - Operational hardening of Python controller asset mode (tick-synchronized path)
- Expand saved scope (cargo/shelf/etc.)
- Automated restore consistency checks (log verification scripts)
- Safe handoff diagnosability (optional logs: reason=
contact_active/near_collision/constraint_active) - RD integration for context handoff design
MIT License
python tools/hako.py build --build-dir /path/to/environment/mujoco-build
selects an external build directory on POSIX and Windows. The CLI option overrides
build.dir in the manifest. Relative CLI paths use the current directory; ~ and
symlinks are resolved. Without this option, the existing manifest/native defaults
remain in effect. POSIX builds use HAKONIWA_CORE_ROOT, then HAKONIWA_HOME, then
/usr/local/hakoniwa for the Core prefix.
Concrete Ackermann vehicle applications, Recipes, and PS5 frontends are owned
by hakoniwa-urban-mobility. This repository provides the shared MuJoCo
physics, Viewer, mirror-body, and contact/impulse backend used by those
applications.