Secop BD35F fridge compressor speed controller integration with Dometic RML10 series absorption refirgerator.
After retrofitting my Dometic RML10 absorption RV refrigerator with a Secop BD35F 12 V compressor unit, the need arose to implement a control unit to address the following issues:
-
The compressor utilizes the RML10's built-in thermostat and is activated by setting the fridge to 12 V mode. It operates using the output originally intended for the 12 V absorber fridge heating unit it replaced. However, since the thermostat was designed for an absorption unit, it has a very narrow hysteresis, causing the compressor to cycle on and off too frequently.
-
The BD35F compressor’s electronic control unit supports variable speed control, either by installing a coding resistor in series with the thermostat or by using a PWM signal to regulate the speed.
The controller in this project is positioned between the RML10 output that controls the 12 V heater relay and the BD35F thermostat input. It minimizes frequent compressor cycling by enforcing configurable minimum on and off durations.
Moreover, the controller dynamically adjusts the PWM signal that regulates the compressor's RPM. It continuously monitors the compressor on/off duty cycle. If the on duty cycle surpasses a specific threshold, the controller gradually increases the compressor speed. Conversely, if the duty cycle falls below certain threshold, the controller gradually reduces the compressor speed.
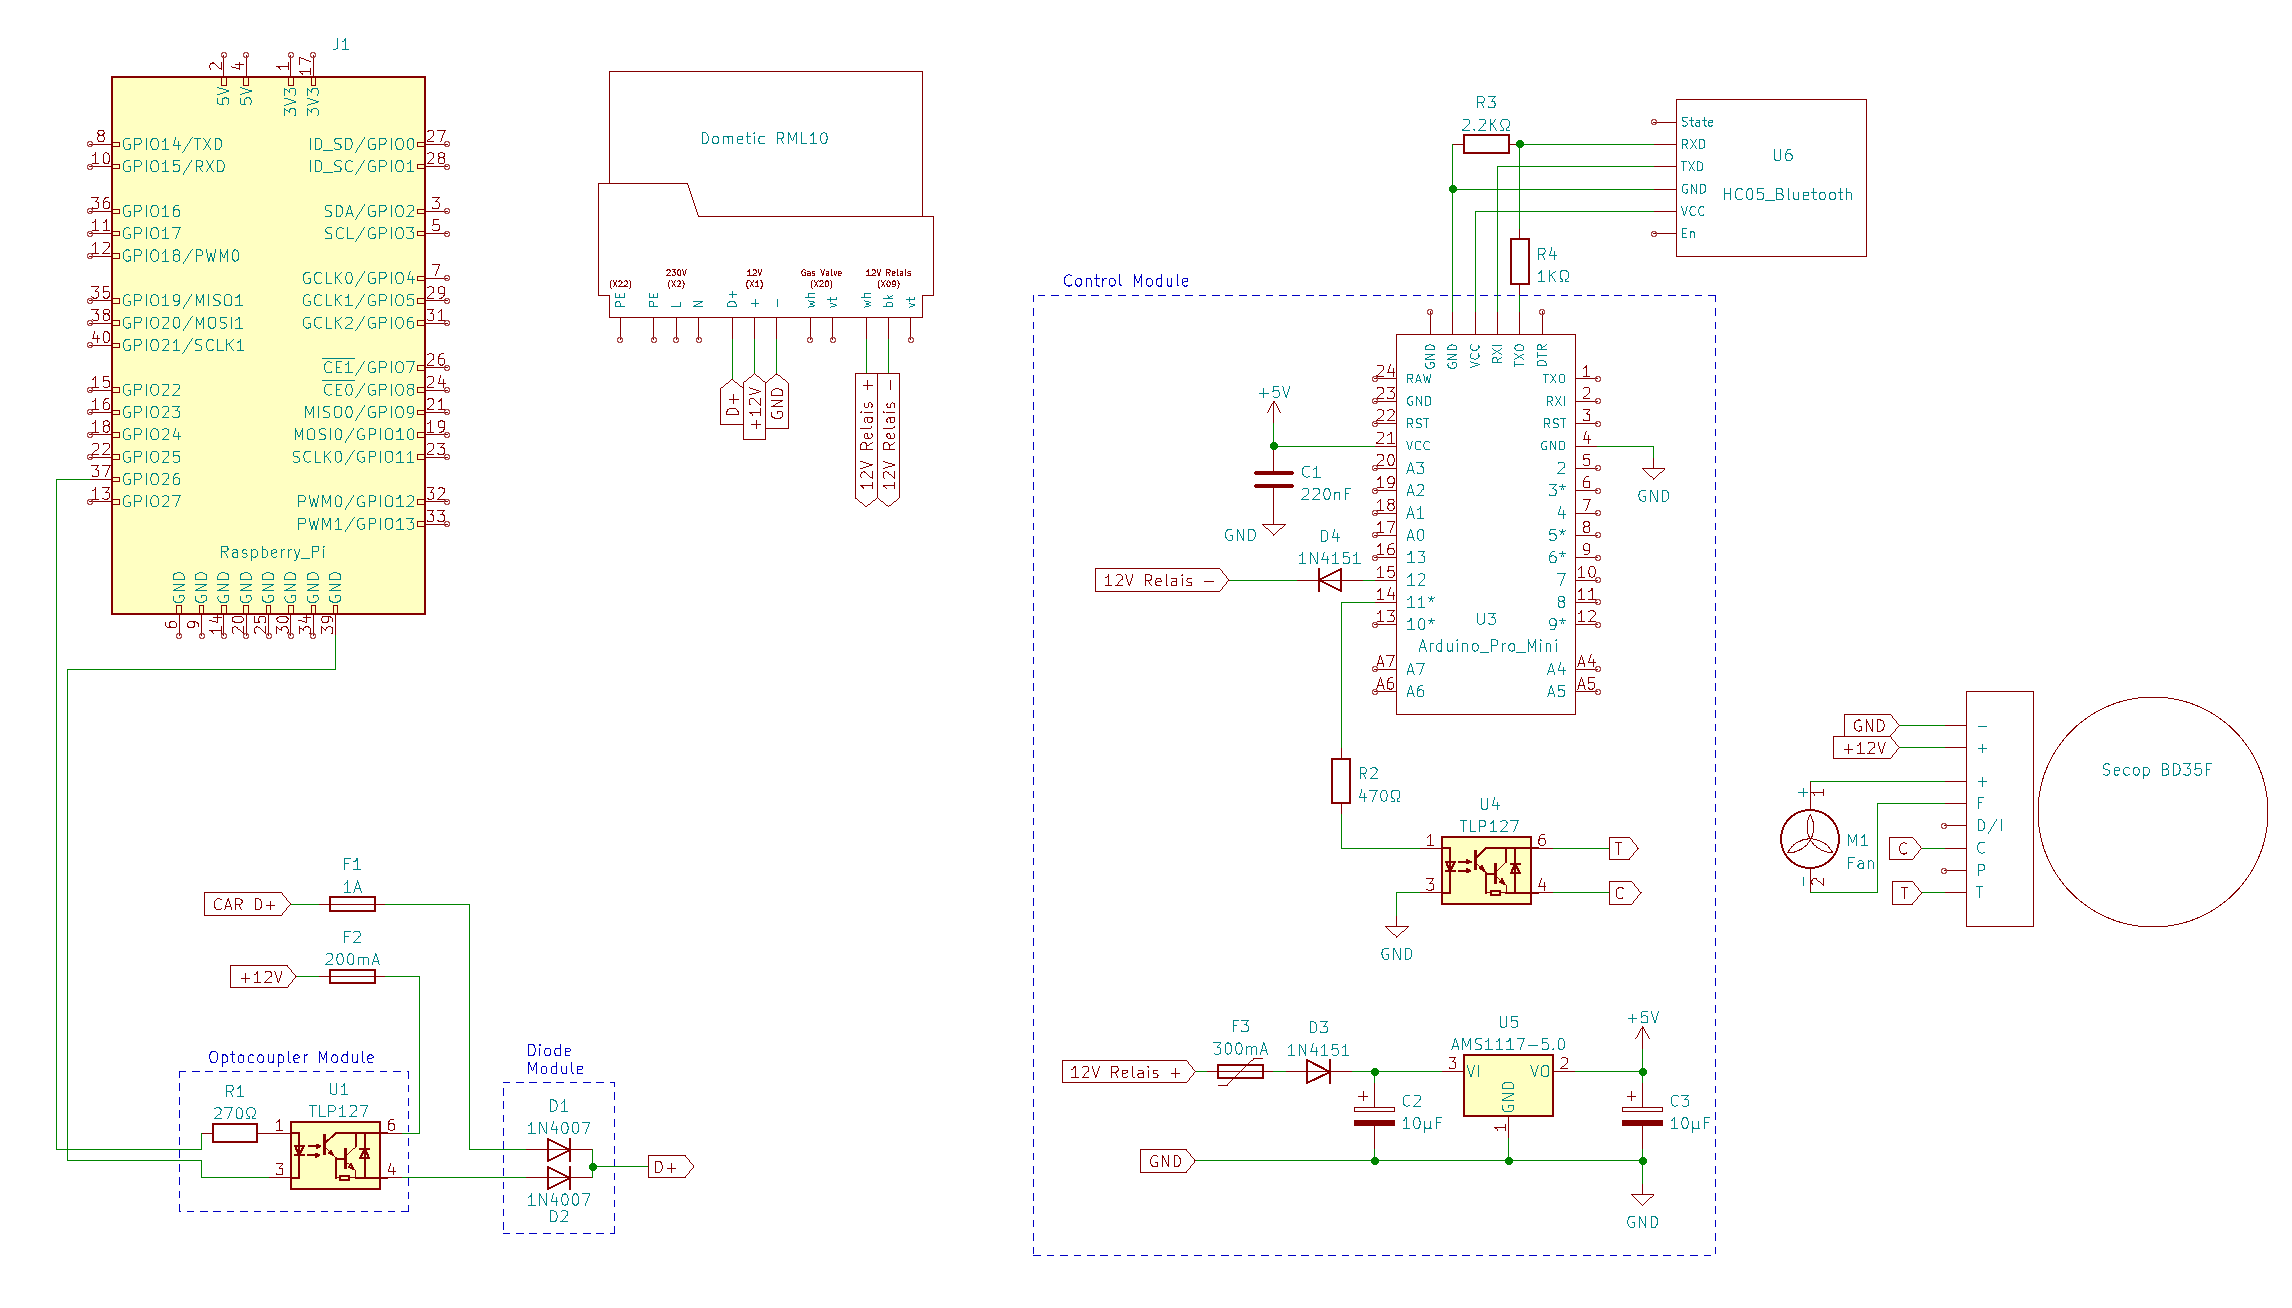
Download the full schematic (PDF)
The schematic includes the following modules:
- Control module: The custom fridge controller described in this project
- Dometic RML10: Built-in fridge control unit
- Secop BD35F: 12 V compressor unit
- Raspberry Pi: Runs a Node-RED flow that sends remote commands to the Arduino via Bluetooth
- Optocoupler module: Allows the Raspberry Pi to control the fridge’s D+ (ignition) signal through GPIO
- Diode module: Combines the D+ signal generated by the RPi with the D+ signal from the towing vehicle
- HC-05 Bluetooth module: Provides wireless UART communication with the Raspberry Pi
-
The Dometic RML10 controller provides a relay output to control the 12 V heating element used for absorber fridge operation. The relay coil is switched on the negative side via an open-collector output.
-
The AMS1117 linear voltage regulator (U5) is placed between the relay’s positive terminal and ground. It is protected with a 300 mA polyfuse and a diode for overcurrent and reverse-polarity protection.
-
Arduino digital pin 12 is connected to the relay’s negative terminal through a polarity protection diode. The RML10 controller enables 12 V cooling by pulling digital pin 12 low. When cooling is not required, the relay terminal floats, and pin 12 is pulled high by its internal pull‑up resistor.
-
The TLP127 (LTV‑252T) optocoupler (U4) electrically isolates the RML10 controller from the BD35F compressor. It is driven by a PWM signal generated with
analogWrite()on Arduino pin 11. The PWM characteristics are described in the next section. -
The common (C) terminal of the BD35F controller (negative side) is connected to the optocoupler emitter, while the temperature sensor (T) pin is connected to the collector.
-
Filtering capacitors C1 and C2 ensure stable operation of the AMS1117 regulator. An additional bypass capacitor (C3) helps suppress electrical noise generated by the RML10’s gas ignition system.
-
The TLP127 optocoupler (U1) isolates the Raspberry Pi GPIO from the 12 V power supply. This allows the Pi to control the RML10’s D+ input.
- D+ enabled: The RML10 uses ignition-controlled 12 V power (absorption cooling disabled if the tow car is disconnected).
- D+ disabled: The RML10 switches to propane refrigeration.
-
A voltage divider (R4/R3) shifts the Arduino’s 5 V logic level to the 3.3 V required by the HC‑05 Bluetooth module.
The BD35F speed control protocol is described in the Secop BD controllers manual (Secop_BD_Controllers_Operating_Instructions.pdf).
The compressor speed ranges between 2000 and 3500 RPM and can be either controlled by connecting a coding resistor between the compressor controller's C and T terminals, or by generating a PWM signal between these two pins. Regarding the PWM signal charateristics, the manual only mentions "open collerctor, 5kHz +-5%".
As shown in the circuit diagram, the open collector design has been implemented using a TLP127 (LTV-252T) optocoupler connected between the common (C) and temperature sensor (T) compressor controller terminals.
Since the exact 5 kHz frequency is not possible to configure out of the box, the PWM frequency of the analog output pin 11 has been configured to 1960.53 Hz. This has been achieved by configuring the clock select bits of Timer/Counter Control Register B (TCCR2B) to clkI/O / 8. Whereas this frequency is derived for an 8 MHz Arduino using the following formulas:
clk_io = 8000000 / 255 = 31372.55 Hz
pwm_frequency = clk_io / 8 = 1960.53 Hz
The TCCR2B clock select bits have been documented in the ATmega328P datasheet Section 22.11.2, Table 22-10 (ATmega328P_Datasheet_201611.pdf):
| CS22 | CS21 | CS20 | Description |
|---|---|---|---|
| 0 | 0 | 0 | No clock source (Timer/Counter stopped) |
| 0 | 0 | 1 | clkI/O / 1 (No prescaling) |
| 0 | 1 | 0 | clkI/O / 8 |
| 0 | 1 | 1 | clkI/O / 32 |
| 1 | 0 | 0 | clkI/O / 64 |
| 1 | 0 | 1 | clkI/O / 128 |
| 1 | 1 | 0 | clkI/O / 256 |
| 1 | 1 | 1 | clkI/O / 1024 |
The chosen PWM frequency has proven to work well with the Secop controller model 101N0212 in use. Whereas the following PWM duty cycle values have been derived via trial and error:
| RPM | Duty Cycle | AnalogWrite (0..255) |
|---|---|---|
| 2000 | 75 % | 190 |
| 3500 | 16 % | 40 |
| 0 | 0 % | 0 |
The compressor speed is continuously adjusted to maintain a configurable target duty cycle. This is achieved through a closed-loop control algorithm, which operates as follows:
- If the measured average compressor duty cycle exceeds the target, the speed is gradually reduced by a specified number of
analogWritesteps per minute. - If the measured duty cycle falls below the target minus a defined hysteresis, the compressor speed is gradually increased by the same step rate.
Speed adjustments are suspended if:
- There are insufficient duty cycle samples accumulated for reliable measurement.
- The feature has been manually disabled by the user.
The speed controller can be configured to periodically pause the cooling cycle for a predefined amount of time in order to allow for the evaporator ice buildup to melt. The defrost routine is initiated when the following condition are met:
- The compressor runtime has reached a preset number of hours.
- The compressor duty cycle does not exceed a preset percentage value.
Once the above conditions have been met, the compressor is turned of for a preset number of minutes in order to allow for any ice buildup to melt.
The the speed controller is configurable over the Arduino's serial interface (9600 Baud). It provides a command line interface and a self explanatory help screen. All configuration parameter's are stored within Arduino's EEPROM.
Following are some of the available commands:
h: Show the help screenon: Turn on the compressoroff: Turn off the compressorc <command>: Remote control commands: Show the system statusr: Show the system configuration stored in EEPROMt [0..2]: If argument is set, configure the tracing level. Otherwise print the trace.ond <0..60>: Set the minimum compressor on duration in minutesoffd <0..60>: Set the minimum compressor off duration in minutespwml <1..255>: Set the AnalogWrite() input value for minimum allowed RPMpwmh <1..255>: Set the AnalogWrite() input value for maximum allowed RPMspdc <41..99>: Set the speed adjustment target duty cycle in percentspdh <1..40>: Set the speed adjustment hysteresis value in percentspdr <1..255>: Set the speed adjustment rate in AnalogWrite() steps per minute (0 = disabled)defr <0..240>: Set the minimum compressor runtime in tenths of an hour (6 minutes) for starting a defrost cycledefc <0..100>: Set the maximum allowed compressor duty cycle in percent for starting a defrost cycledefd <0..60>: Set the defrost cycle duration in minutes (0 = disabled)duty <10..max>: Set the duty cycle measurement duration in minutes
The RV uses a Raspberry Pi (RPi) running Victron Venus OS to collect data from several onboard devices, including the battery shunt (for charge and current), the solar charge controller, the Truma Combi heater (for indoor temperature), and BLE temperature sensors in the fridge and outside. Using this information, the RPi runs an optimized fridge control algorithm to improve energy efficiency.
A Node-RED flow on the RPi processes the sensor data and sends commands to an Arduino that controls the fridge compressor. Communication between the RPi and Arduino is handled over UART wirelessly via an HC-05 Bluetooth module.
Remote control of the fridge is achieved through a set of commands:
| Command | Description |
|---|---|
c 0 |
Turn off the compressor |
c 1..c 10 |
Set compressor speed (1 = min, 10 = max) |
c 11 |
Turn on the compressor |
c 12 |
Disable remote operation |
c 20 |
Stop the defrost cycle |
c 21 |
Start a new defrost cycle |
c 22 |
Disable periodic defrost (stored in EEPROM) |
c 23 |
Enable periodic defrost (stored in EEPROM) |
c 30 |
Request system status information |
Sending any command between c 0 and c 11 automatically enables remote operation. While in this mode, the fridge controller ignores the RML10 relay signal and relies solely on remote commands to operate the compressor. If no command in this range is received within a predetermined timeout, remote operation is disabled and the controller reverts to local operation based on the RML10 relay signal.
The Node-RED flow provides several key functions, including:
- Controlling the compressor according to fridge temperature reported by BLE sensors
- Detecting sudden temperature increases (e.g., when the door is open) and temporarily setting the compressor to maximum speed
- Disabling the defrost cycle in high ambient temperatures
- Switching to propane refrigeration when the battery charge is low
- Activating propane refrigeration to assist cooling during high ambient temperatures
The Node-RED flow that implements this control algorithm is available on GitHub: microfarad-de/inetbox2mqtt
The Node-RED flow depends on several services and scripts provided in the microfarad-de/nastia-server (venus-os branch):
- bt-daemon – Connects the HC-05 Bluetooth module as an RFCOMM device and restarts the Bluetooth stack automatically if the connection is lost.
- gpio-daemon – Enables Node-RED to access and control Raspberry Pi GPIO pins.
- serial-command – Lets Node-RED send commands over UART to the fridge controller Arduino.
- serial-console – Provides an interactive UART console for direct communication with the Arduino.
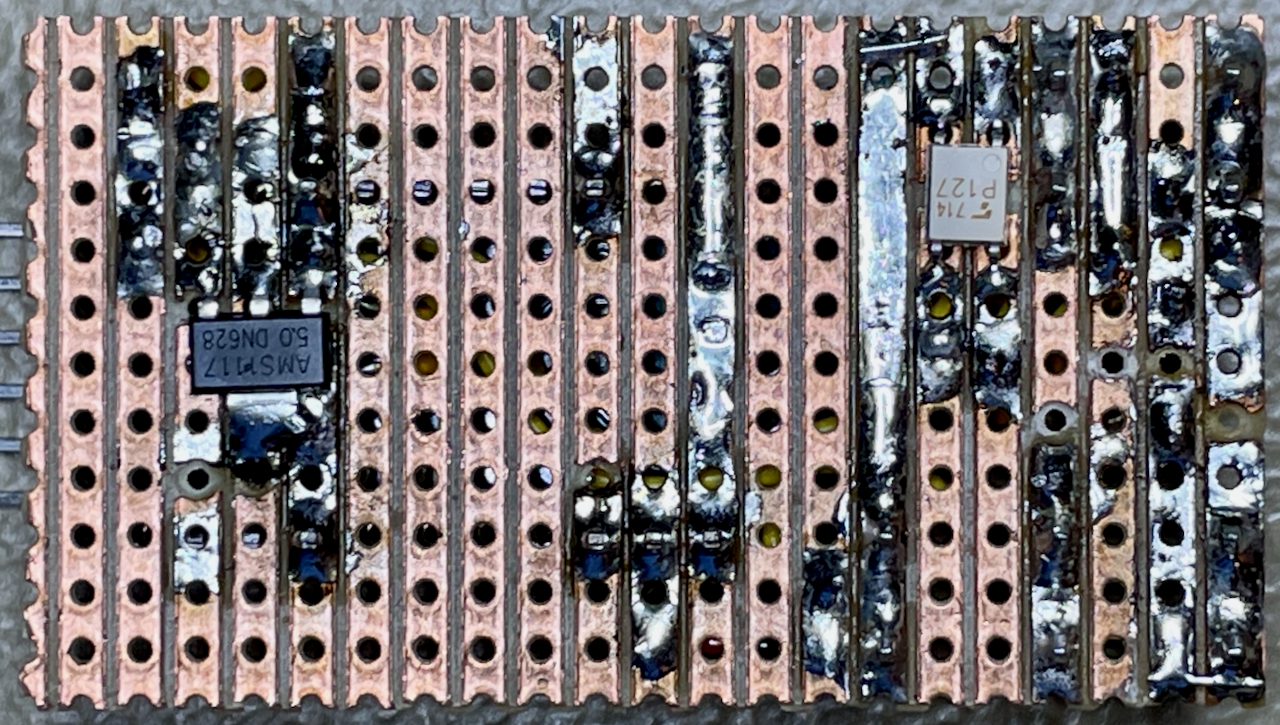
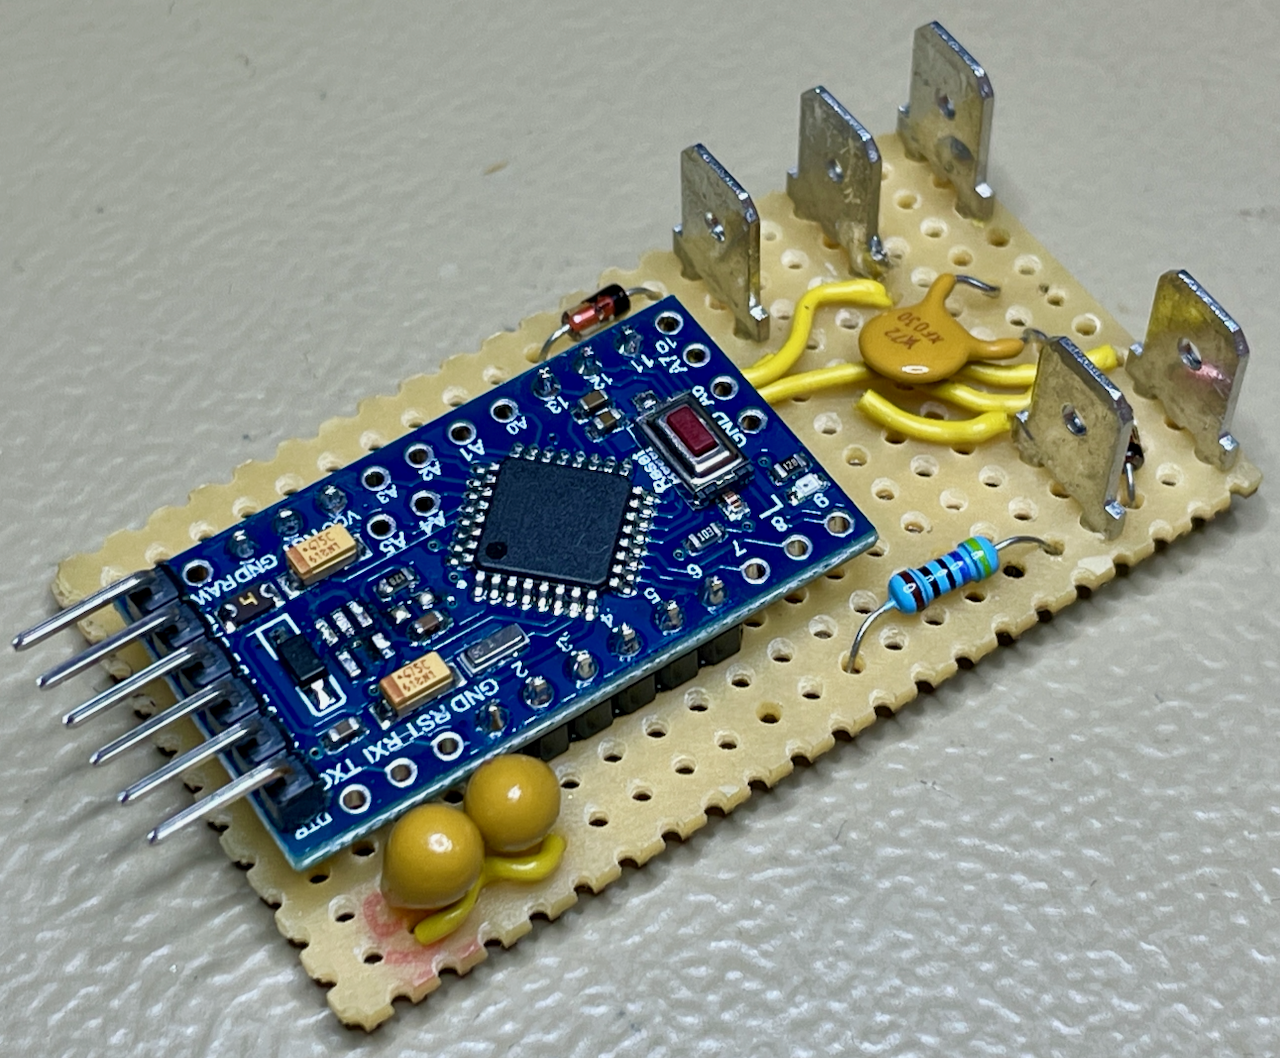
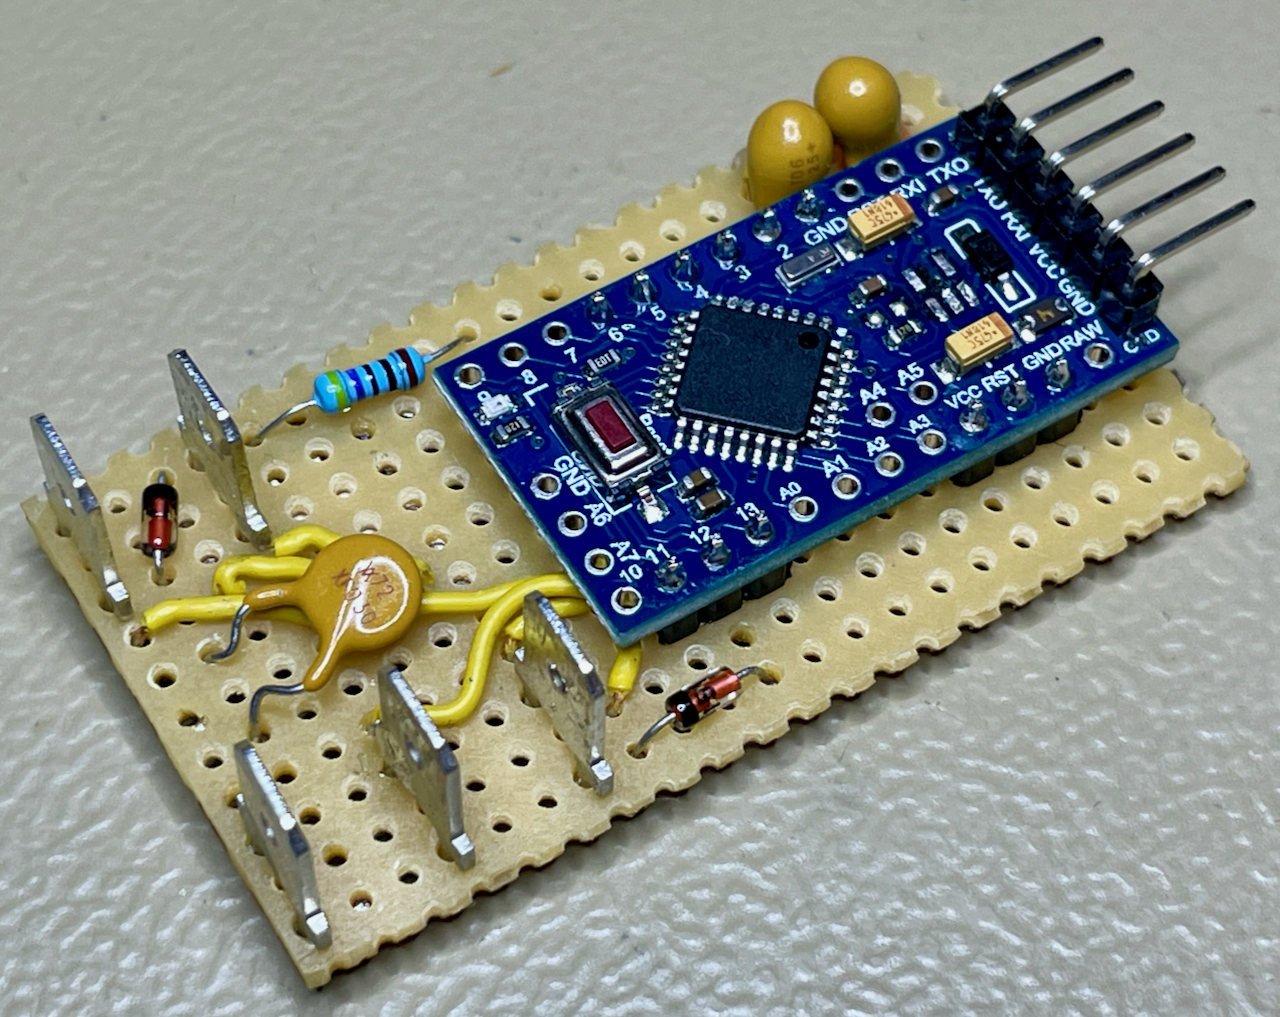
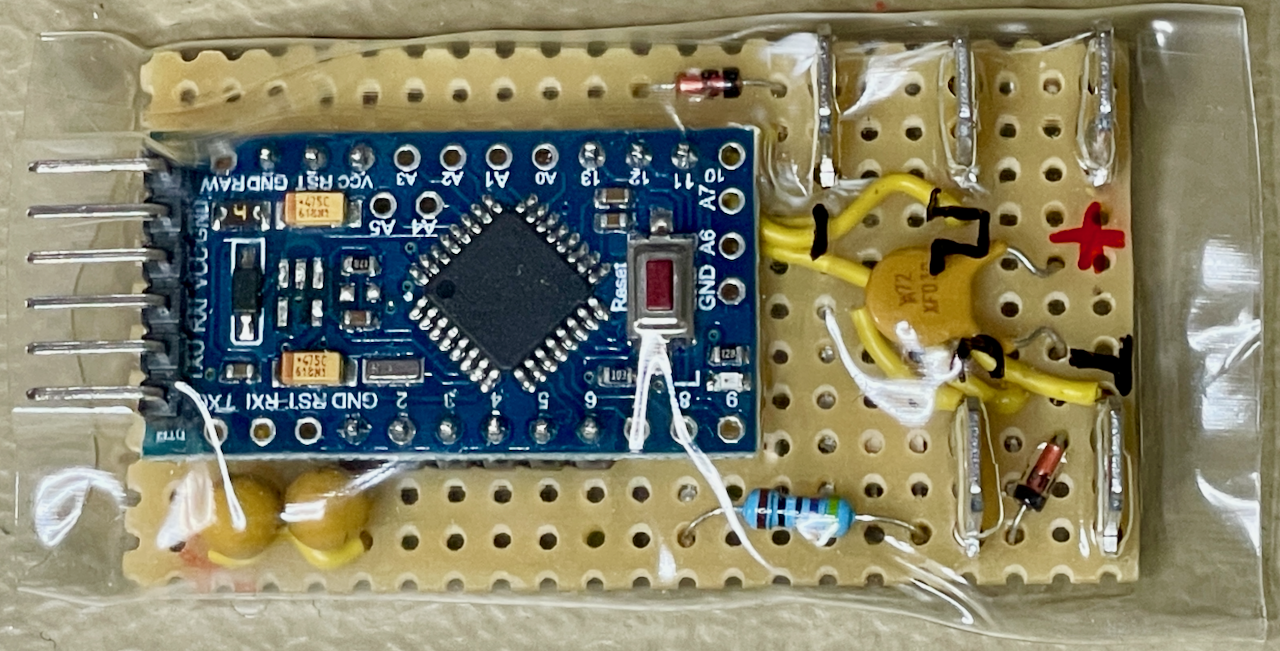
The code has been implemented and tested on an Arduino Pro Mini clone board based on the ATmega328P microcontroller.
The code uses the watchdog timer, therefore the custom bootloader with watchdog support must be installed from: https://github.com/microfarad-de/bootloader
This project uses Git submodules. In order to get its full source code, please clone this Git repository to your local workspace, then execute the follwoing command from within the repository's root directory: git submodule update --init.
The following dependencies should to be installed:
pip install pyserial
This project can be compiled from command line using a makefile. Following are the available make commands:
- Compile the project:
make - Remove compiled artefacts:
make clean - Upload to Arduino board:
make upload - Connect to the serial console:
make serial - To generate the release archive:
make release
Prior to uploading the firmware, please ensure that the following parameaters are configured correctly in Makefile:
BOARD_TAG: Device type as listed inboards.txtormake show_boards(e.g.: pro, uno).BOARD_SUB: Submenu as listed inboards.txtormake show_submenu(e.g.: 16MHzatmega328, atmega168)MONITOR_BAUDRATE: Serial port Baud rate (possible values: 4800, 9600, 14400, 19200, 28800, 38400, 57600, 115200)MONITOR_PORT: Serial port device (e.g.: /dev/tty.usbserial-00000000)
For more information, please refer to the Arduino-Makefile documentation.