

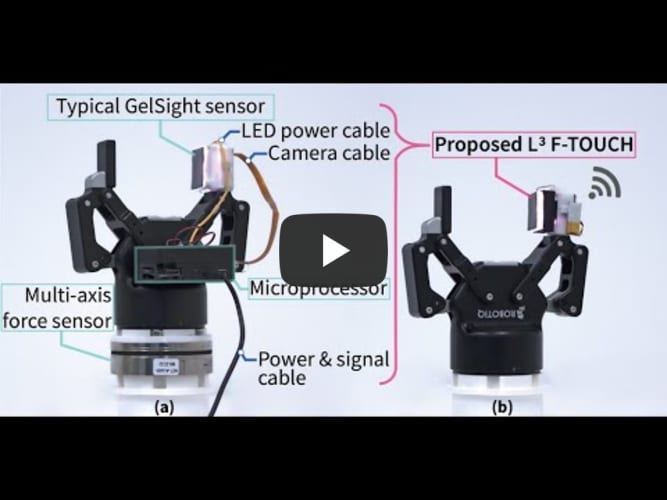
L3 F-TOUCH sensor is an enhanced version of the GelSight sensor, it acquires a much better three-axis force sensing capability while being Light-weight, Low-cost and wireLess for the ease of replication and deployment.
We decouple the three-axis force and tactile information using a suspension structure with mirrored visual tag. The L3 F-TOUCH demonstrates an improved force sensing capability immuned from contact geometry compared to other GelSight-like designs while being light and cost-effective compared to commercial three-axis force sensors. The wireless data transmission feature also enables broader applications of akin vision-based tactile sensors.
This repository contains the documentation and manufacturing files for L3 F-TOUCH tactile sensor.
- Compile and upload the firmware via PlatformIO (WiFi must be configured);
- Use VLC to check the RTSP video streaming. Adress can be found in Serial monitor when startup.
- Run L3-FTOUCH.py for demonstration;
- Modify the firmware to use picture mode for higher quality images (advanced).
If you use this project in your research, please cite:
@article{li20233,
  title={L$^3$ F-TOUCH: A Wireless GelSight with Decoupled Tactile and Three-axis Force Sensing},
  author={Li, Wanlin and Wang, Meng and Li, Jiarui and Su, Yao and Jha, Devesh K and Qian, Xinyuan and Althoefer, Kaspar and Liu, Hangxin},
  journal={IEEE Robotics and Automation Letters},
  volume={8},
  number={8},
  pages={5148--5155},
  year={2023},
  publisher={IEEE}
}