Repository navigation
6. VIRTUAL IMPLEMENTATION
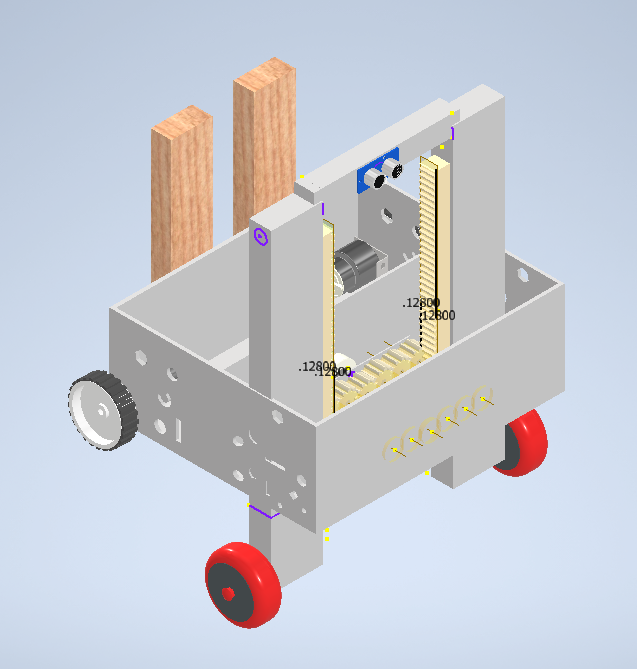
Step 1 -> Start
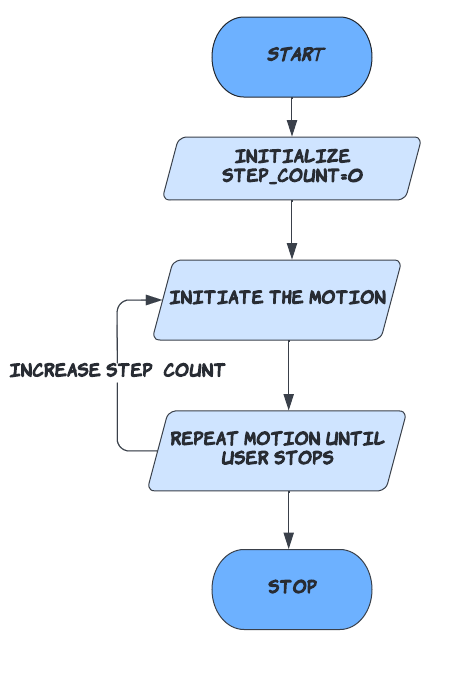
Step 2 -> Initialize step count = 0
Step 3 -> Initiate the motion
Step 4 -> repeat step 3 and increase the step_count after one step
Step 5 -> Stop the motion
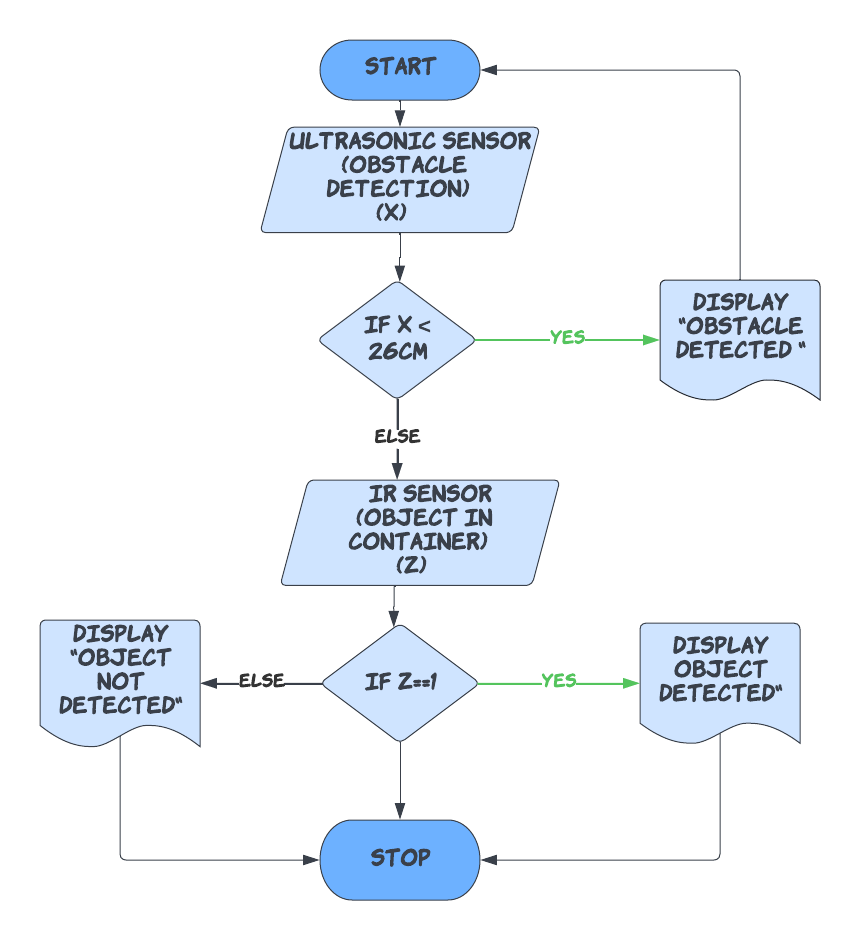
Step 1 -> Start
Step 2 -> Check ultrasonic sensor status (x) (obstalcle unit)
Step 3 -> if (x < 26 cm ) display "object found" else display "object not found"
Step 4 -> Check IR sensor status (y) (object in container)
Step 5 -> If (y==0) display "Objected in container detected" else display "No object found"
Step 5 -> Stop
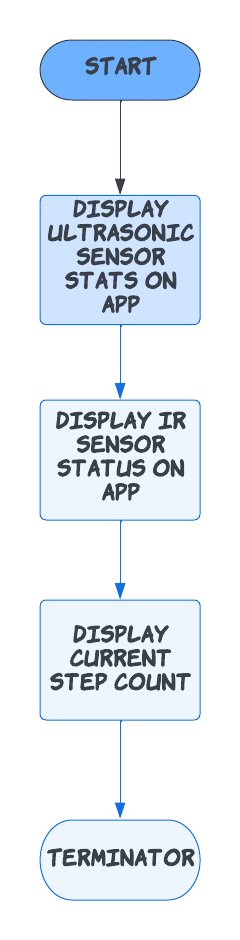
Step 1 -> Start
Step 2 -> check tilt sensor (x)
Step 3 -> if x==1 , display "bot is tilted cannot proceed"
Step 4 -> Display Ultrasonic sensor status (obstacle)
Step 5 -> Display IR sensor status (object in container)
Step 5 -> Stop
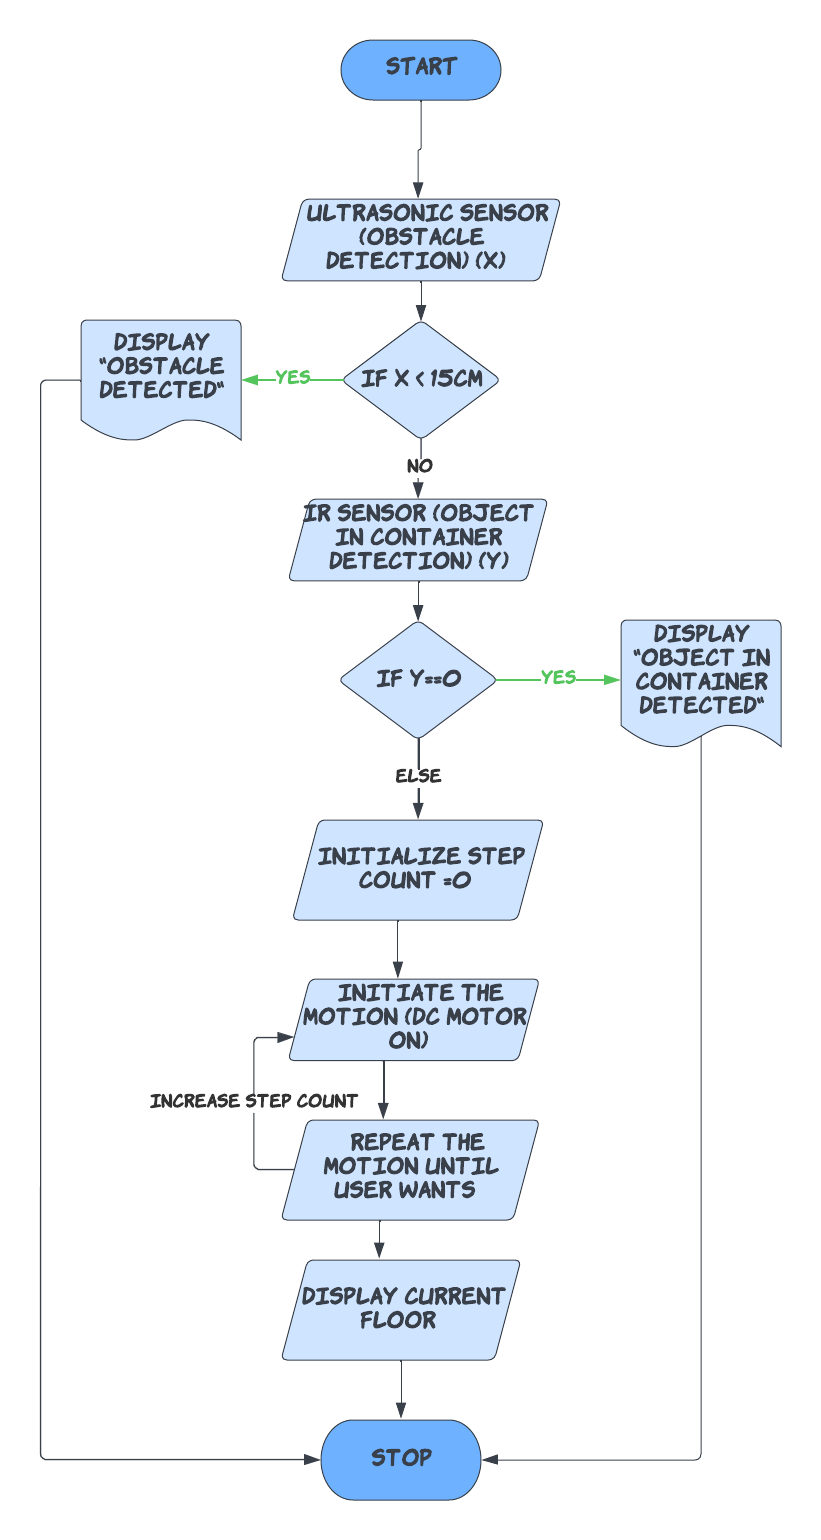
Step 1 -> Start the bot
Step 2 -> check Ultrasonic sensor (y) (obstacle)
Step 3 -> if y < 15 cm , display " Obstacle detected cannot proceed ", else go to step 4
Step 4 -> check IR sensor (z) (object in container)
Step 5 -> if z==0 , display " object found and go to step 6 ", else display "object not found"
Step 6 -> initialize step count = 0
Step 7 -> initialize the motion
Step 8-> repeat step 7 and increase step count after one step
Step 9 -> Display current floor
Step 10 -> stop
| SL.no | Component Name | Component details | Quantity |
|---|---|---|---|
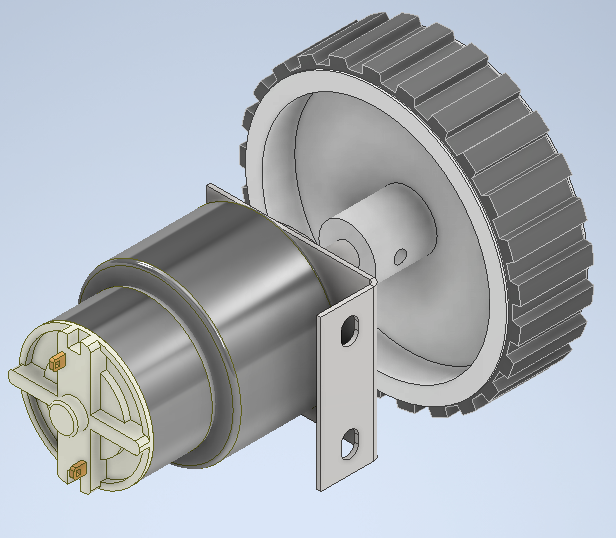
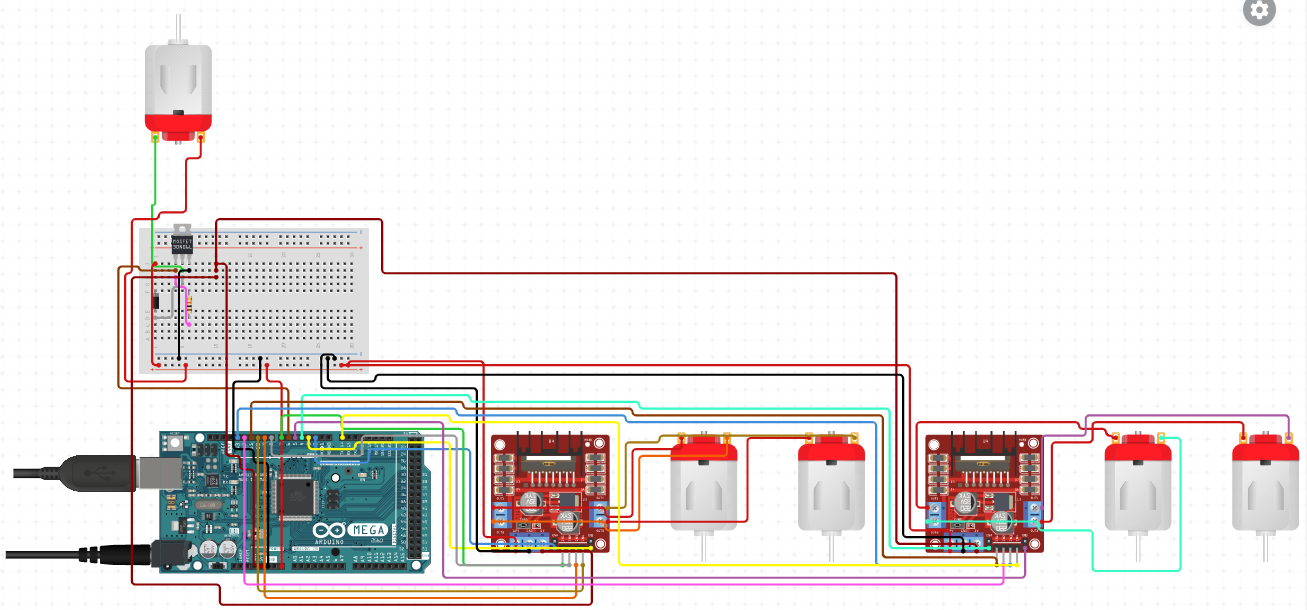
| 1 | DC Motor | 30 rpm | 3 |
| 2 | Motor Driver | L298D | 2 |
| 3 | Bread Board | 400 pins | 1 |
| 5 | Connecting wires | Male to male, Male to female | 10 each |
| 6 | Micro controller | Arduino MEGA 2560 | 1 |
| 7 | Dc johnson motor | 30 RPM | 2 |
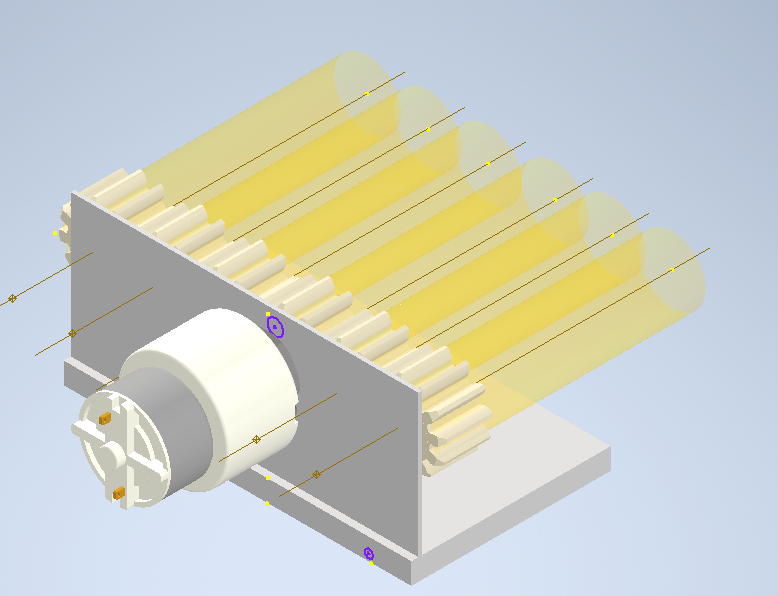
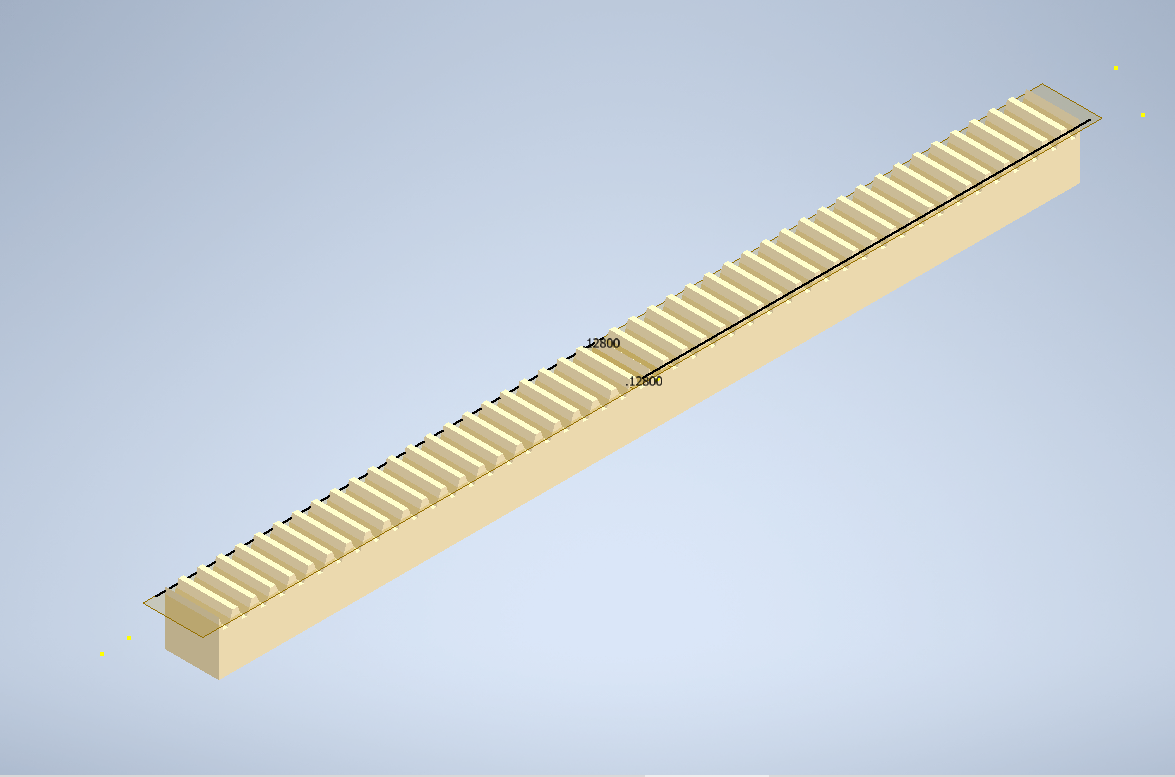
| 8 | Rack | 32 cm height | 3 |
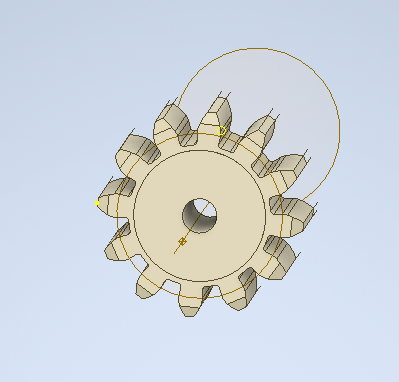
| 9 | Spur gear | 6 cm diameter | 3 |
| 10 | Spur gear | 4 cm diameter | 1 |
| 11 | Relay module | 1 input | 1 |
| 12 | Wheels | 6cm diamter | 6 |
| SL.no | Component Name | Component details | Quantity |
|---|---|---|---|
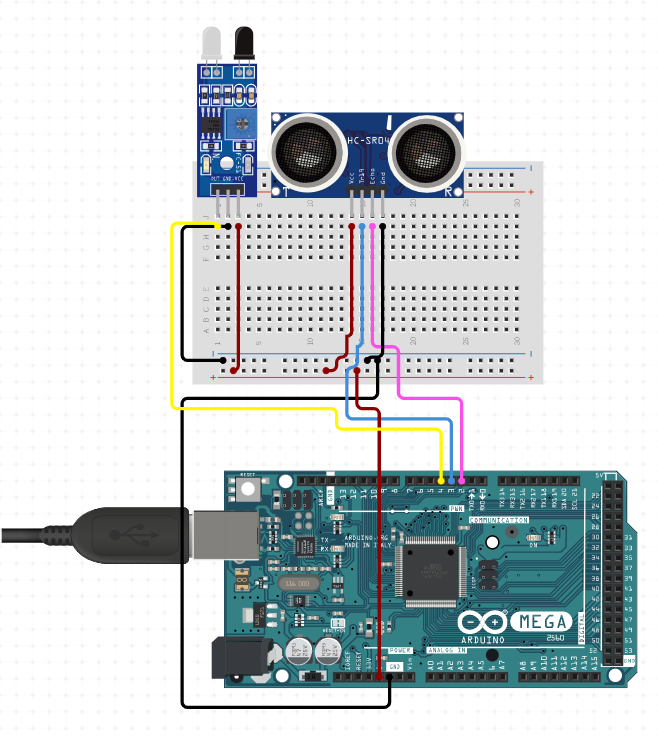
| 1 | Micro controller | Arduino MEGA 2560 | 1 |
| 2 | sensor | IR Sensor | 1 |
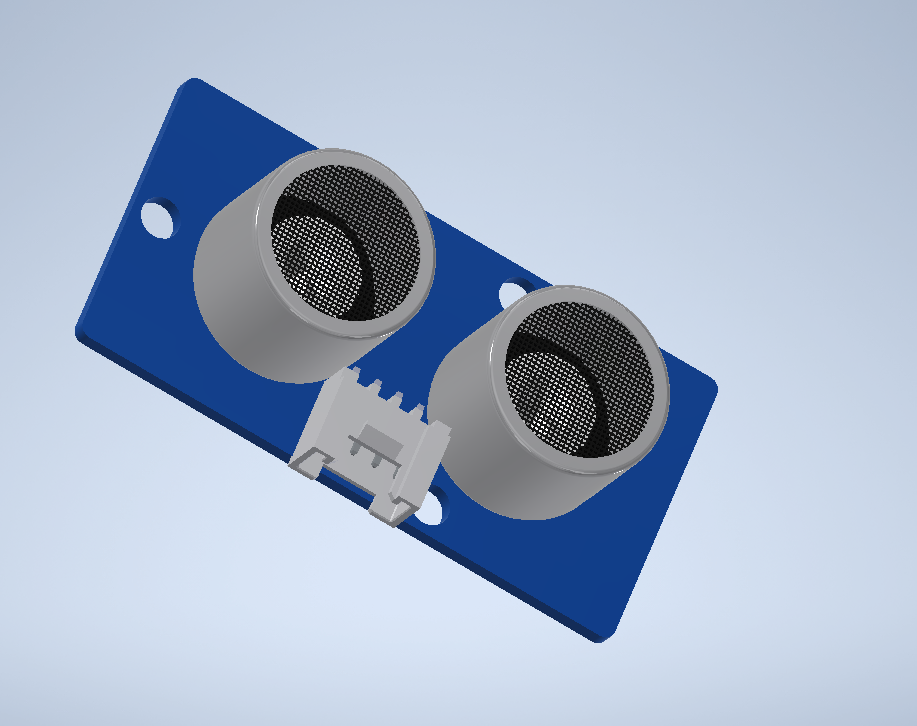
| 3 | Sensor | Ultrasonic (HC-SR04) | 1 |
| 4 | Bread Board | 400 pins | 1 |
| 5 | Connecting wires | Male to male, Male to female | 10 each |
| SL.no | Component Name | Component details | Quantity |
|---|---|---|---|
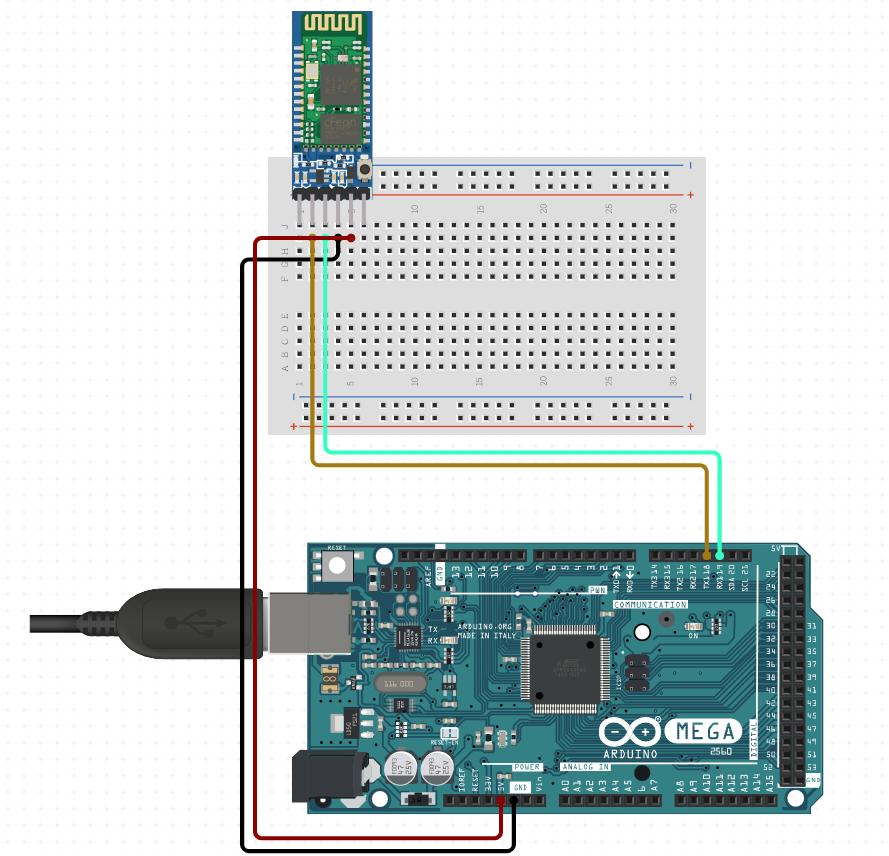
| 1 | Bluetooth module | HC-05 | 1 |
| 2 | Connecting wires | Male to male, Male to female | 10 each |
| 3 | Micro controller | Arduino MEGA 2560 | 1 |
| 4 | Bread Board | 400 pins | 1 |
| SL.no | Component Name | Component details | Quantity |
|---|---|---|---|
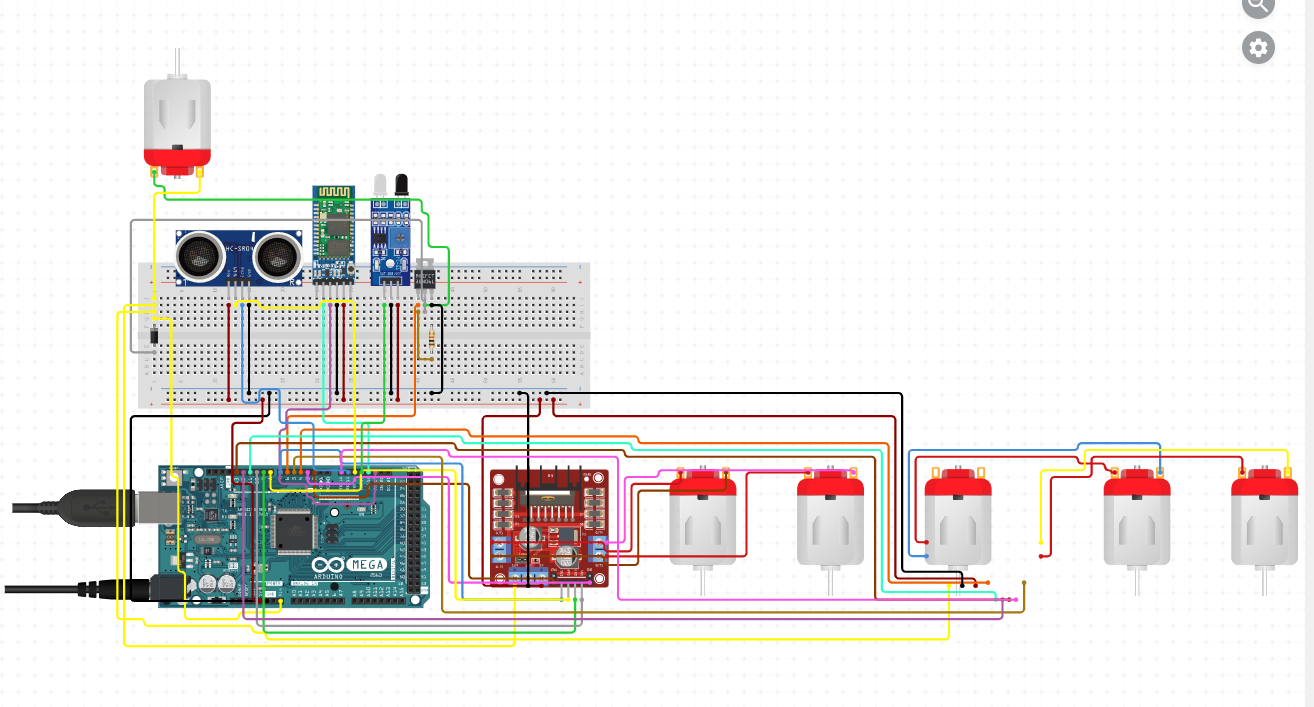
| 1 | DC Motor | 30 RPM | 3 |
| 2 | Motor driver | L298D | 2 |
| 3 | Micro controller | Arduino MEGA 2560 | 1 |
| 4 | Sensor | IR Sensor | 1 |
| 5 | Sensor | Ultrasonic (HC-SR04) | 1 |
| 6 | DC johnson motor | 30 RPM | 2 |
| 7 | Connecting wires | Male to male, Male to female | 10 each |
| 8 | Motor clamps | 6 | |
| 10 | Rack | 32 Cm | 3 |
| 11 | Spur gear | 6cm diameter | 3 |
| 12 | Spur gear | 4cm dimater | 1 |
| 13 | Wheels | 6cm diameter | 6 |
| 14 | Relay module | 1 input | 1 |