Repository navigation
5. PRODUCT ARCHITECTURE
| Design Objectives | Weights | Design 1 | Design 2 | Design 3 | Design 4 |
|---|---|---|---|---|---|
| Good grip to hold object | 8 | - | -- | 0 | DATUM |
| cost | 4 | + | -- | + | DATUM |
| Speed to pick and place | 6 | -- | + | - | DATUM |
| Aesthetic | 7 | - | 0 | 0 | DATUM |
| Strength to robotic arm | 8 | - | 0 | - | DATUM |
| Score(+) | 4 | 4 | 4 | 0 | |
| Score (-) | 35 | 24 | 14 | 0 | |
| Total | -31 | -20 | -10 | 0 |
| Design No. | Objective | Score Allocated | Justification for the Score |
|---|---|---|---|
| 1 | good grip to hold object | -8 | grip was not as strong as datum |
| cost | 4 | low budget model than datum | |
| speed to pick and place | -12 | had low speed to pick and place as compared to datum | |
| aesthetic | -7 | model is not easy to use for the user | |
| strength to robotic arm | -8 | robotic arm was not as strong as compared to datum | |
| 2 | good grip to hold object | -16 | vaccum grip not as strong as 2 jaw gripper in datum |
| cost | -8 | high budget then datum | |
| speed to pick and place | 4 | high efficiency and speed than datum | |
| aesthetic | 0 | equally asthetic as datum | |
| strength to robotic arm | 0 | equal strenght of arm | |
| 3 | good grip to hold object | 0 | grip was as strong as datum |
| cost | 4 | less budget model as compared to datum | |
| speed to pick and place | -6 | had slow speed to pick and place as compared to datum | |
| aesthetic | 0 | model is equally aesthetic as compared to datum | |
| strength to robotic arm | -8 | robotic arm was not as strong as compared to datum | |
| 4 | good grip to hold object | datum | as a reference |
| cost | datum | as a reference | |
| speed to pick and place | datum | as a reference | |
| aesthetic | datum | as a reference | |
| strength to robotic arm | datum | as a reference |
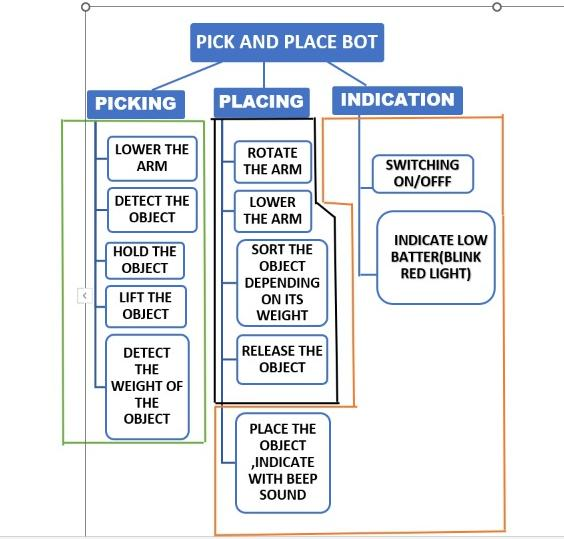
| SL. No. | Subsystem |
|---|
- | Picking
- | Placing
- | Indication
| Picking | Placing | Indication |
|---|---|---|
| Spatial | no | no |
| Data | yes | yes |
| Material | no | no |
| Placing | Picking | Indication |
| Spatial | no | no |
| Data | yes | yes |
| Material | no | no |
| Indication | Picking | Placing |
| Spatial | no | no |
| Data | yes | yes |
| Material | no | no |