Repository navigation
[Bug]: Autotracking silently stops until restart if the camera drops during a RelativeMove (exception kills _process_move_queue) #24834


Checklist
Describe the problem you are havingIf a camera goes offline while a From reading the source, the likely cause is this:
The same code is in I have not captured the exception itself, because nothing logs it. The cause above comes from the source plus the log pattern below. ObservedTimes are UTC, on one camera, with
The camera head did not move on any event after that, including a person who walked across the full frame for 72 s. The stall was still present at the last event I checked, 6 hours later. Steps to reproduce
I hit this once, from a real camera crash. I have not reproduced it on purpose yet. Version0.18.2-cfa08c5 In which browser(s) are you experiencing the issue with?No response Frigate config file# yaml-language-server: $schema=http://192.168.1.162:5000/api/config/schema.json
go2rtc:
streams:
front_room_nest:
nest:?client_id={FRIGATE_NEST_OAUTH_CLIENT_ID}&client_secret={FRIGATE_NEST_OAUTH_CLIENT_SECRET}&refresh_token={FRIGATE_NEST_DEVICE_REFRESH_TOKEN}&project_id={FRIGATE_NEST_DEVICE_ACCESS_PROJECT_ID}&device_id={FRIGATE_NEST_CAMERA_ID_FRONT_ROOM}&protocols=WEB_RTC&video=h264&audio=opus
mqtt:
enabled: true
host: localhost
birdseye:
enabled: false
# Optional: logger verbosity settings
logger:
# Optional: Default log verbosity (default: shown below)
default: info
# default: debug
logs: # debug on 2026-10-20 to catch stale-frame overshoot (kitchen 10:44 JST event); remove again after capturing one
frigate.ptz.autotrack: debug
frigate.ptz.onvif: debug
ffmpeg:
hwaccel_args: preset-vaapi
#hwaccel_args: preset-intel-qsv-h265
output_args:
# preset-record-generic-audio-copy doesn't work for some reason
#record: preset-record-generic-audio-aac
record: preset-record-generic-audio-copy
snapshots:
enabled: true
retain:
default: 180
detect:
enabled: true
fps: 5
face_recognition:
enabled: true
lpr:
enabled: true
min_plate_length: 4 # drop partial reads like "50"
recognition_threshold: 0.9 # default, explicit
# known_plates: # fill in to get sub_labels instead of just recognized_license_plate
# Kevin's car:
# - "12-34"
match_distance: 1
debug_save_plates: true
# Optional: Object configuration
# NOTE: Can be overridden at the camera level
objects:
# Optional: list of objects to track from labelmap.txt (default: shown below)
track:
- person
- bicycle
- car
- motorcycle
- airplane
- bus
- car
- bird
- cat
- dog
- horse
- sheep
- elephant
- bear
- zebra
- hat
- backpack
- shoe
- eye glasses
- handbag
- suitcase
- skis
- snowboard
- kite
- baseball bat
- baseball glove
- skateboard
- tennis racket
- bottle
- plate
- wine glass
- cup
- fork
- knife
- spoon
- bowl
- banana
- apple
- sandwich
- orange
- broccoli
- carrot
- hot dog
- pizza
- donut
- cake
- potted plant
- mirror
- dining table
- window
- desk
- door
- mouse
- remote
- keyboard
- cell phone
- microwave
- oven
- toaster
- sink
- book
- clock
- vase
- scissors
detectors:
ov:
type: openvino
device: GPU
#coral:
# type: edgetpu
# device: usb
model:
width: 300
height: 300
input_tensor: nhwc
input_pixel_format: bgr
path: /openvino-model/ssdlite_mobilenet_v2.xml
labelmap_path: /openvino-model/coco_91cl_bkgr.txt
record:
enabled: true
alerts:
retain:
days: 180
detections:
retain:
days: 180
continuous:
days: 15
motion:
days: 15
cameras:
nest_front_room:
enabled: true
detect:
enabled: true
width: 1280 # explicit: probing a cold Nest stream at startup times out
height: 720
fps: 5
ffmpeg:
inputs:
- path: rtsp://127.0.0.1:8554/front_room_nest
roles:
- record
- detect
- audio
garage:
onvif: # native ONVIF service on the cam (atomcam_tools fork)
host: 192.168.1.129
port: 80
user: ''
password: ''
autotracking:
enabled: true
calibrate_on_startup: false # off 2026-10-15: weights varied up to 2x between calibrations, so every restart changed tracking; recalibrate deliberately (remove movement_weights + set true + restart, then set back to false). Garage recalibrated 2026-10-16 08:26 UTC.
zooming: disabled
required_zones:
- autotrack_all
return_preset: home
timeout: 15
movement_weights: 0.0, 1.0, 1.0, 0.16595622841868557,
0.5584486744922691, 0
zones:
autotrack_all: # full frame; Frigate requires >=1 zone for autotracking
coordinates: 0,0,1,0,1,1,0,1
loitering_time: 0
ffmpeg:
# GPU decode again (global preset-vaapi) since 2026-10-12: the "ref loss storm" was the cam's 50 KB RTSP send buffer dropping keyframe packets, fixed in the cam firmware (v15)
# no audio track on the cam any more (RTSP_AUDIO2=off), so no audio role and no audio in the recordings
# QSV decode on this cam since 2026-10-13: VAAPI died (-EIO 'Failed to sync surface') on any corrupt/missing-ref frame, 226 crashes in 16.8 h vs 0 for QSV on kitchen.
# Revert to VAAPI: delete the next line (backup: config.yml.pre-garage-qsv).
hwaccel_args: preset-intel-qsv-h265
# low-latency input 2026-10-15 (autotrack lag): preset-rtsp-generic args + nobuffer/low_delay. Revert: delete input_args (backup: config.yml.pre-garage-lowlat)
input_args: -user_agent FFmpeg_Frigate -avoid_negative_ts make_zero
-fflags +genpts+discardcorrupt+nobuffer -flags low_delay -rtsp_transport
tcp -timeout 10000000 -use_wallclock_as_timestamps 1
output_args:
record: preset-record-generic
inputs:
# HEVC / h265
- path: rtsp://192.168.1.129:8554/video2_unicast
roles:
- record
- detect
# h264
# - path: rtsp://192.168.1.129:8554/video0_unicast
# roles:
# - record
# - detect
# - audio
# sub stream 640x360
# - path: rtsp://192.168.1.129:8554/video1_unicast
# roles:
# - detect
motion:
mask:
motion_mask_1:
friendly_name: Motion Mask 1
enabled: true
coordinates:
0,0.277,0.115,0.209,0.213,0.147,0.474,0.068,0.483,0.194,0.556,0.372,0.646,0.407,0.758,0.351,0.738,0.151,0.776,0.049,1,0.194,1,0,0.001,0.002,0,0.123
motion_mask_2:
friendly_name: Motion Mask 2
enabled: true
coordinates: 0.723,0.931,0.974,0.931,0.974,0.983,0.719,0.978
threshold: 30
contour_area: 10
improve_contrast: true
kitchen:
onvif: # native ONVIF service on the cam (atomcam_tools fork)
host: 192.168.1.50
port: 80
user: ''
password: ''
autotracking:
enabled: true
calibrate_on_startup: false # off 2026-10-15: weights varied up to 2x between calibrations, so every restart changed tracking; recalibrate deliberately (remove movement_weights + set true + restart, then set back to false)
zooming: disabled
required_zones:
- autotrack_all
return_preset: home
timeout: 15
movement_weights: 0.0, 1.0, 1.0, 0.20214029640279793,
0.32022326300221104, 0
zones:
autotrack_all: # full frame; Frigate requires >=1 zone for autotracking
coordinates: 0,0,1,0,1,1,0,1
loitering_time: 0
ffmpeg:
# GPU decode again (global preset-vaapi) since 2026-10-12: the "ref loss storm" was the cam's 50 KB RTSP send buffer dropping keyframe packets, fixed in the cam firmware (v15)
# no audio track on the cam any more (RTSP_AUDIO2=off), so no audio role and no audio in the recordings
# A/B 2026-10-12: QSV decode on this cam only (garage keeps global preset-vaapi). VAAPI dies (-EIO) on corrupt slice data; QSV survived the offline repro. Software decode (hwaccel_args: []) gave 0 crashes in 118 min.
# Revert to software: hwaccel_args: [] (backup: config.yml.pre-kitchen-qsv); to VAAPI: delete the line.
hwaccel_args: preset-intel-qsv-h265
# low-latency input 2026-10-16, same as garage (A/B probe: image onset ~0.25 s earlier). Revert: delete input_args
input_args: -user_agent FFmpeg_Frigate -avoid_negative_ts make_zero
-fflags +genpts+discardcorrupt+nobuffer -flags low_delay -rtsp_transport
tcp -timeout 10000000 -use_wallclock_as_timestamps 1
output_args:
record: preset-record-generic
inputs:
# HEVC / h265
- path: rtsp://192.168.1.50:8554/video2_unicast
roles:
- record
- detect
# h264
# - path: rtsp://192.168.1.50:8554/video0_unicast
# roles:
# - record
# - detect
# - audio
# sub stream 640x360
# - path: rtsp://192.168.1.50:8554/video1_unicast
# roles:
# - detect
motion:
mask:
motion_mask_1:
friendly_name: Motion Mask 1
enabled: true
coordinates: 0.722,0.932,0.72,0.98,0.976,0.983,0.974,0.934
motion_mask_2:
friendly_name: Motion Mask 2
enabled: true
coordinates: 0,0,1,0,1,0.34,0,0.347
threshold: 30
contour_area: 10
improve_contrast: true
version: 0.18-0docker-compose file or Docker CLI commandservices:
frigate:
container_name: frigate
privileged: true # this may not be necessary for all setups
restart: unless-stopped
image: ghcr.io/blakeblackshear/frigate:stable
shm_size: "512mb" # update for your cameras based on calculation above
devices:
- /dev/bus/usb:/dev/bus/usb # passes the USB Coral, needs to be modified for other versions
# - /dev/apex_0:/dev/apex_0 # passes a PCIe Coral, follow driver instructions here https://coral.ai/docs/m2/get-started/#2a-on-linux
- /dev/dri/renderD128 # for intel hwaccel, needs to be updated for your hardware
volumes:
- /etc/localtime:/etc/localtime:ro
# - /home/kevin/frigate/config.yml:/config/config.yml
- /home/kevin/frigate:/config
- /media/Tac/frigate:/media/frigate
# - type: tmpfs # Optional: 1GB of memory, reduces SSD/SD Card wear
# target: /tmp/cache
# tmpfs:
# size: 100000000
network_mode: host
# json-file log rotation: unbounded growth + NULs after hard resets broke `docker logs` (2026-10-11)
logging:
driver: json-file
options:
max-size: "50m"
max-file: "5"
environment:
****REDACTED****Relevant Frigate log output2026-10-31 06:13:32 frigate.ptz.autotrack DEBUG : garage: Enqueue movement for frame time: 1793427211.840375 pan: -0.0489...
2026-10-31 06:13:32 frigate.ptz.onvif DEBUG : garage called RelativeMove: pan: -0.0489...
2026-10-31 06:13:32 frigate.ptz.onvif DEBUG : garage: PTZ start time: 1793427212.251859
2026-10-31 06:13:52 watchdog.garage INFO : No frames received from garage in 20 seconds. Exiting ffmpeg...
2026-10-31 06:14:24 frigate.ptz.onvif WARNING : Camera garage does not support the ONVIF GetStatus method. ...
2026-10-31 06:18:27 frigate.ptz.onvif DEBUG : garage: Pan/tilt status: IDLE, Zoom status: IDLE
2026-10-31 06:18:27 frigate.ptz.onvif DEBUG : garage: PTZ stop time: 1793427212.920967
...
2026-10-31 07:01:50 frigate.ptz.autotrack DEBUG : garage: New object: 1793430109.247058-1ruxo3 (1740, 300, 1763, 382) 1793430109.844624
2026-10-31 07:01:50 frigate.ptz.autotrack DEBUG : garage: Enqueue movement for frame time: 1793430109.844624 pan: 0.825, tilt: 0.3722, zoom: 0
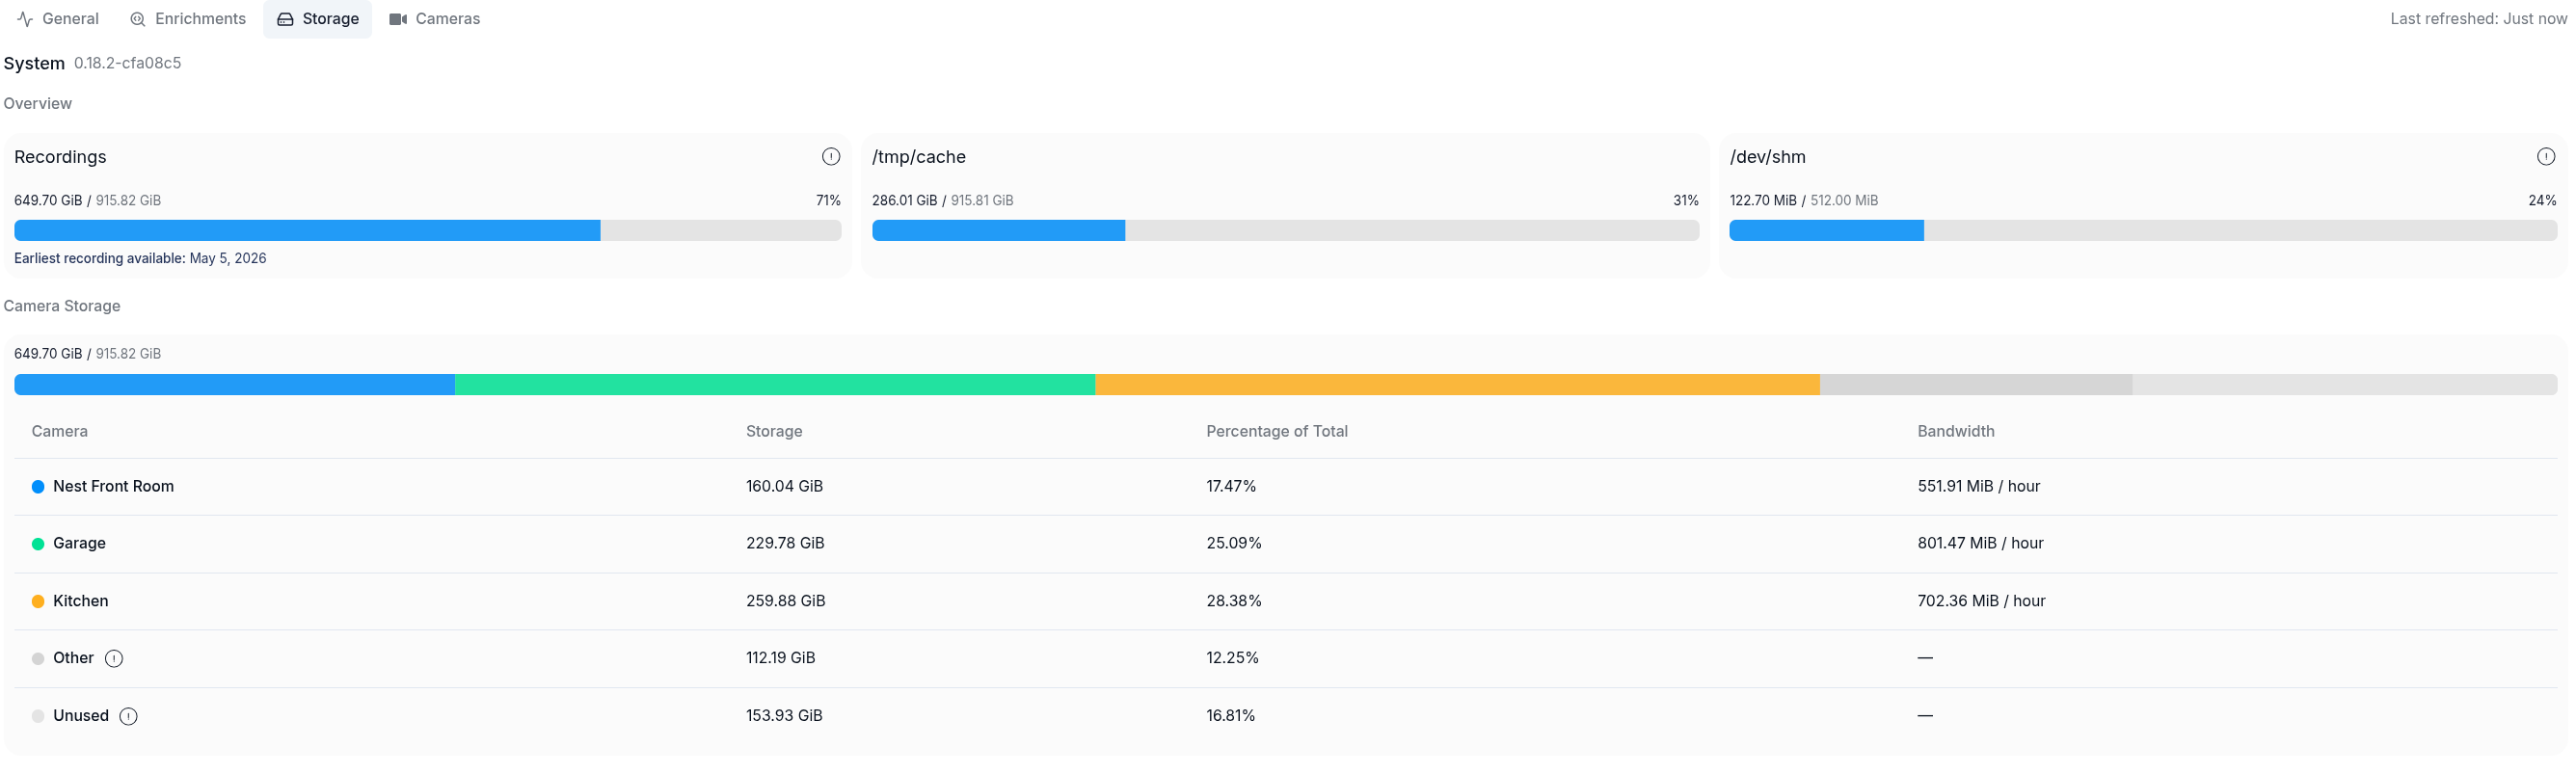
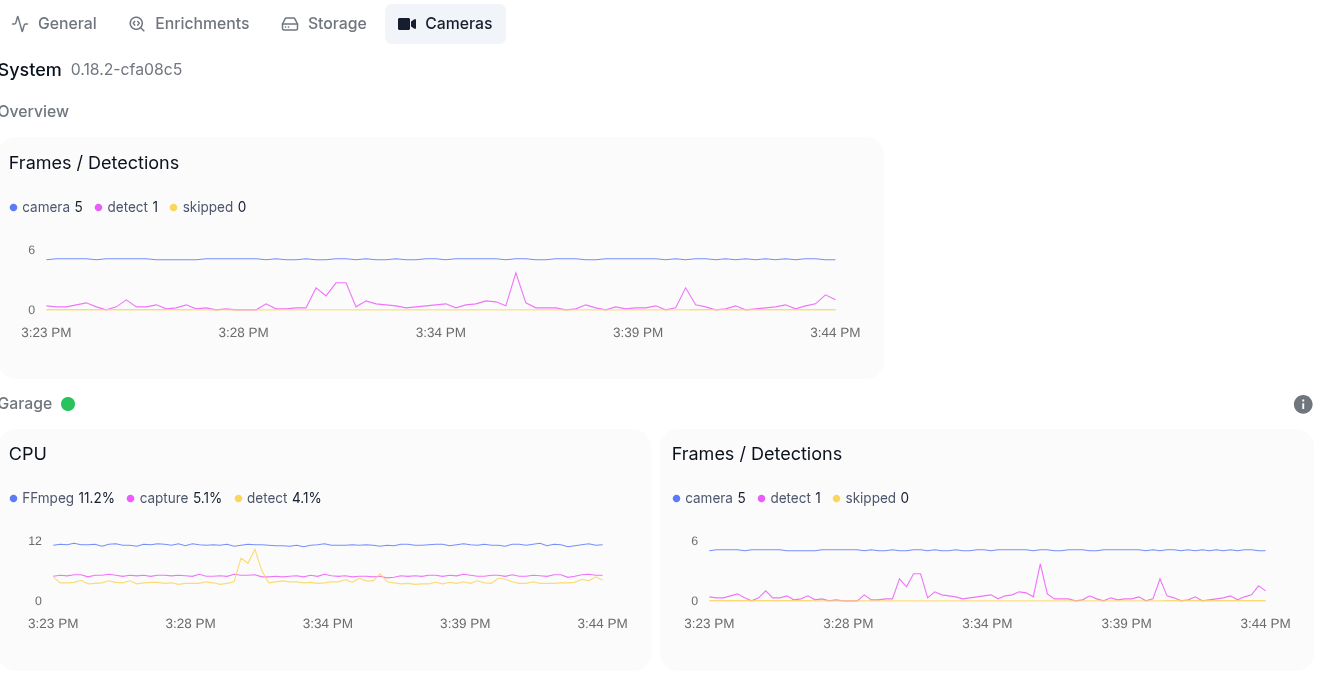
(no "called RelativeMove" follows)Relevant go2rtc log outputNot relevant, ffmpeg reads this camera's stream directly over RTSP.Operating systemOther Linux Install methodDocker Compose Network connectionWireless Camera make and modelATOM Cam Swing running atomcam_tools custom firmware (ONVIF via onvif_simple_server). The bug is in Frigate's error handling, so any ONVIF PTZ camera should show it. Screenshots of the Frigate UI's System metrics pages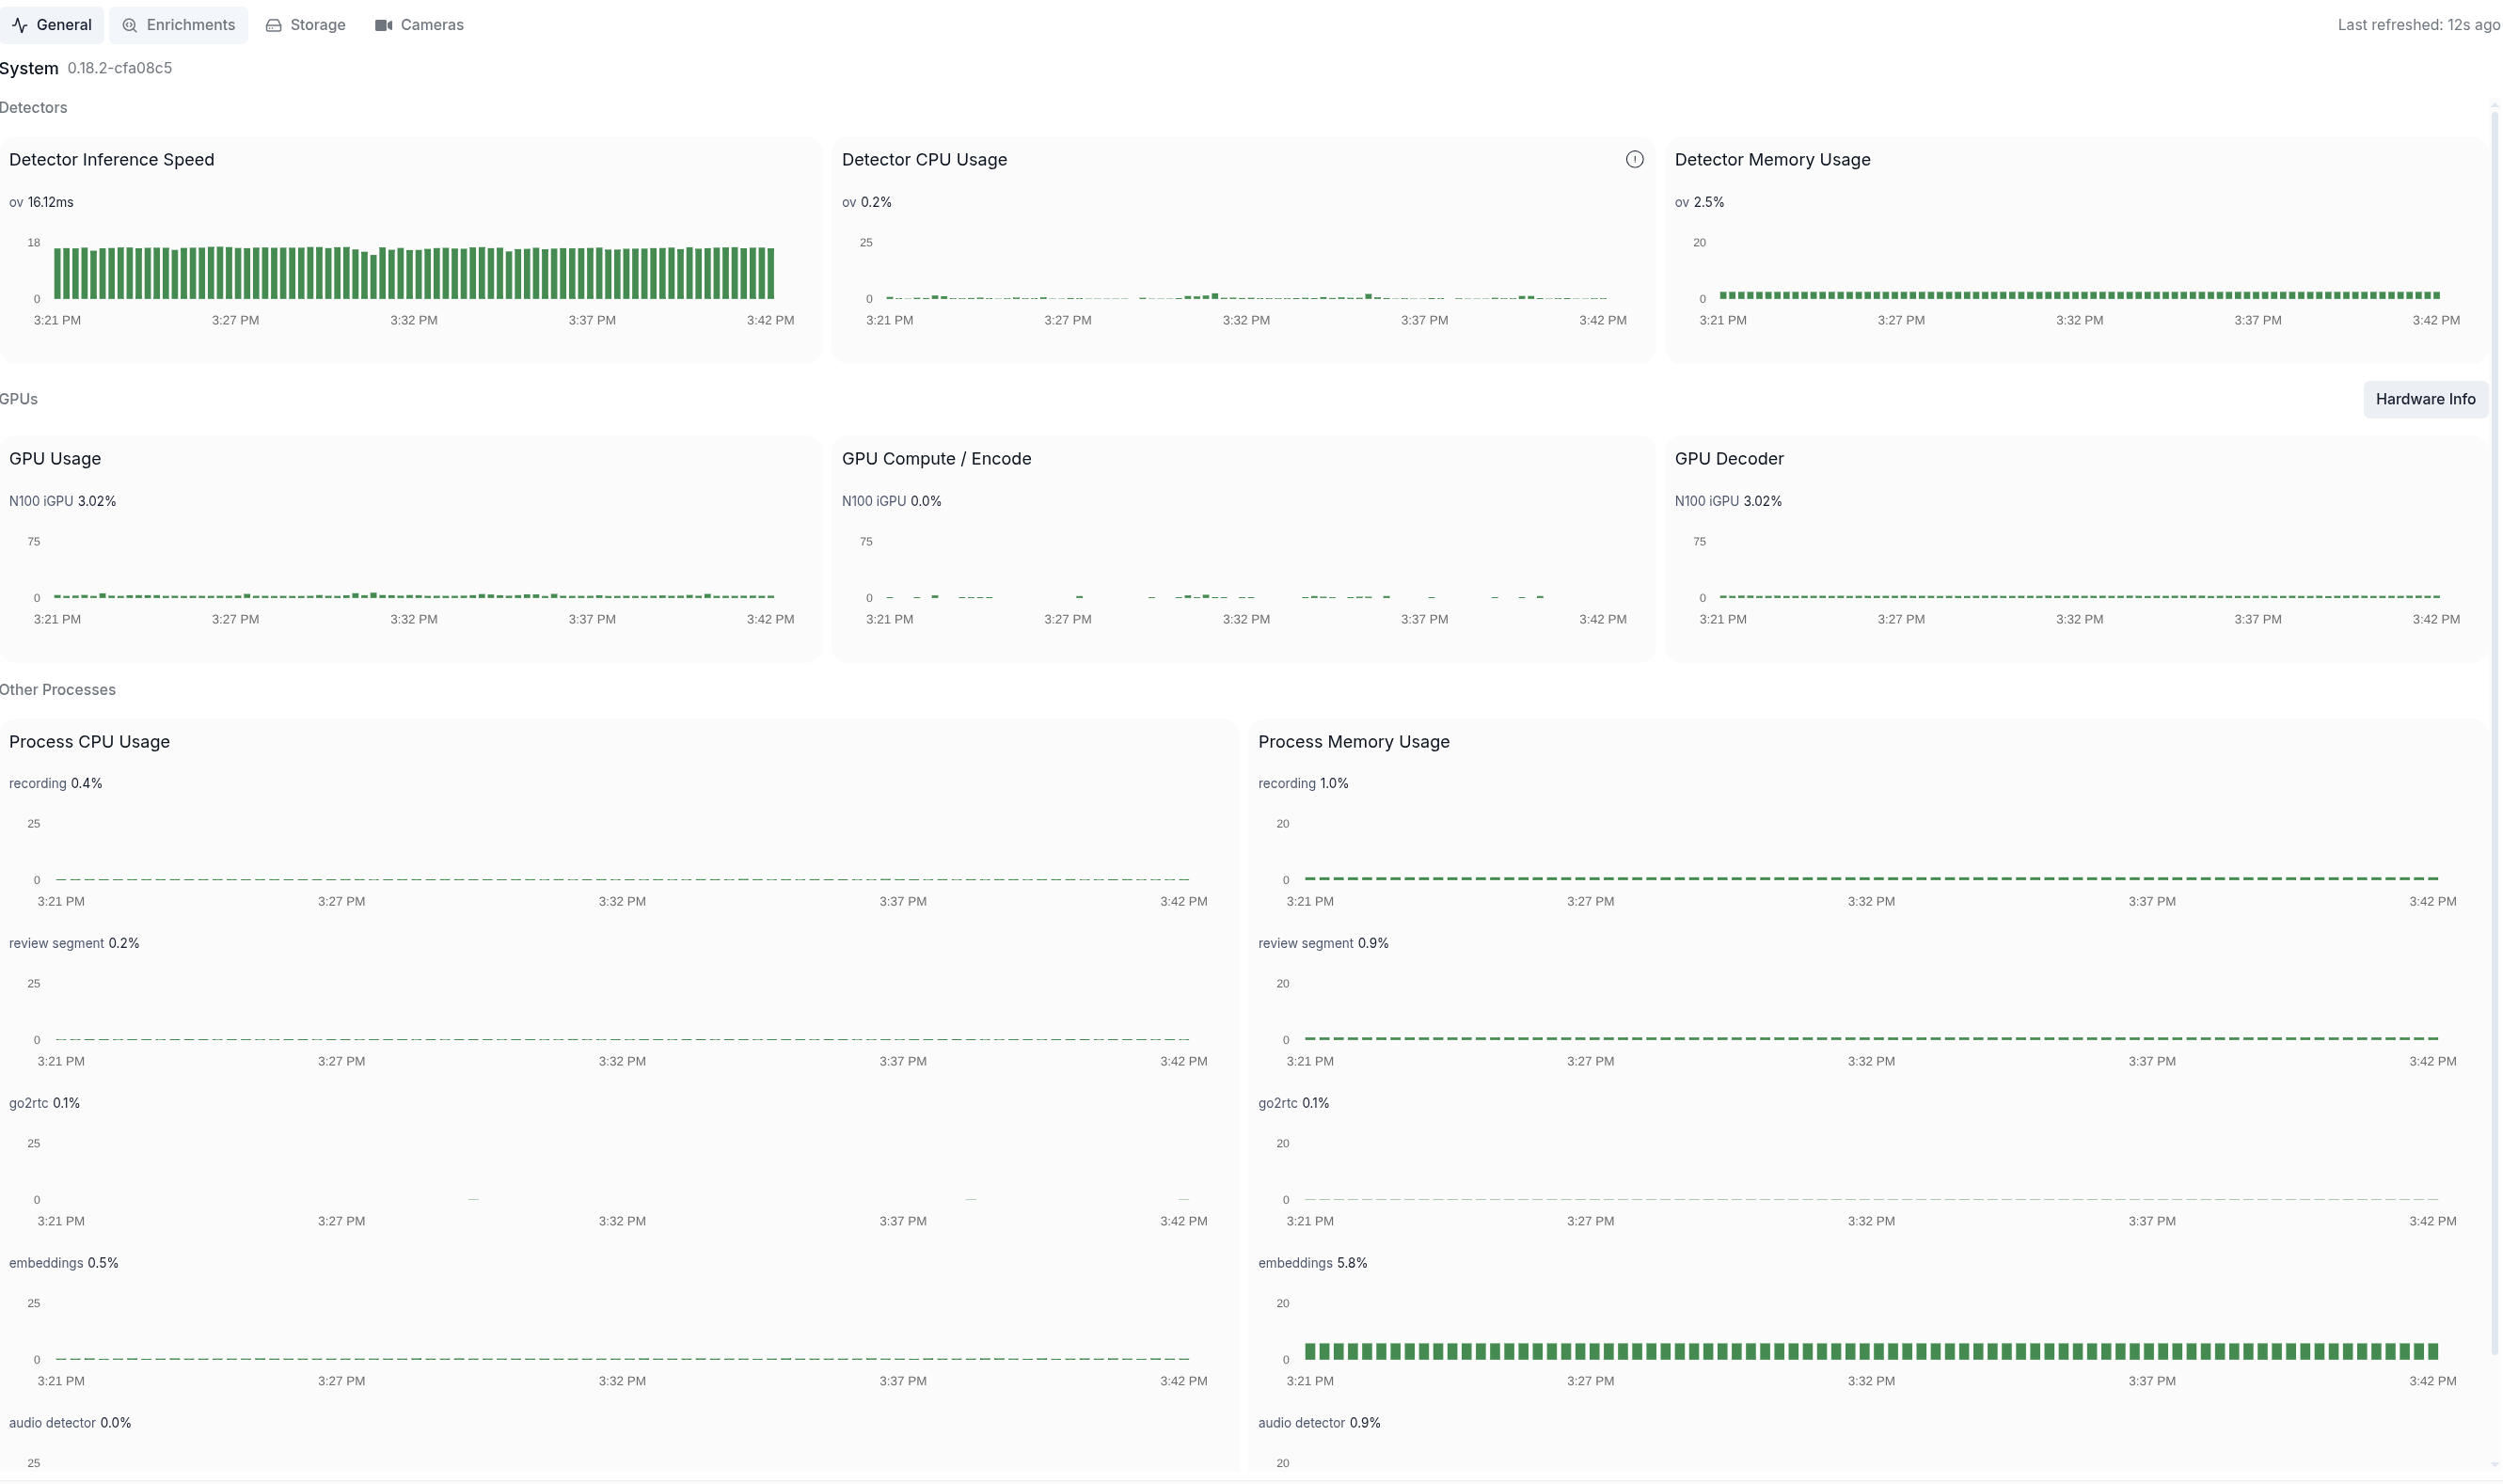
Any other information that may be helpfulNo response |
Replies: 4 comments 2 replies

|
I can't confirm the internal behavior you describe. The material I have covers autotracking configuration and usage, not the implementation of A few things I can speak to that relate to your setup:
For the code-level report itself, the right place is the Frigate repository: GitHub. Related community threads on ONVIF movement handling: Auto-Tracking using absolute movement, Universal ONVIF PTZ Tracking Question. If you'd like, I can give a general answer about how a stalled async consumer task typically presents, without tying it to specific Frigate internals. 📚 Sources: Have another question? Just tag @inkeep. |
|
Thanks, but I've checked Issues / PRs / Discussions and this problem isn't covered. Your 3 comments are not directly relevant to that problem; only the first one would apply had the timeling been right : the problem had already occurred when that log line was written (it's a consequence of the camera rebooting). |

|
We can add a simple try/except so a failed move doesn't stop a relative move call until a restart, but the camera crashing mid-move isn't something we can fix on our side. That's most likely a firmware issue or something else with the camera itself, so you'll want to look into why it's rebooting. |

|
Actually the camera isn't crashing, it's on WiFi and drops off the connection mid-move, causing this issue. |
|
This is improved in #24835 |
|
Thanks |


This is improved in #24835