Repository navigation
v2.3-beta2
Pre-release
Note
Version 2.x is only compatible with MSFS 2024.
Version 1.x is only compatible with MSFS 2020. Download the latest 1.x version from the releases page.
Drag the falcon71-kln90b folder into your community folder.
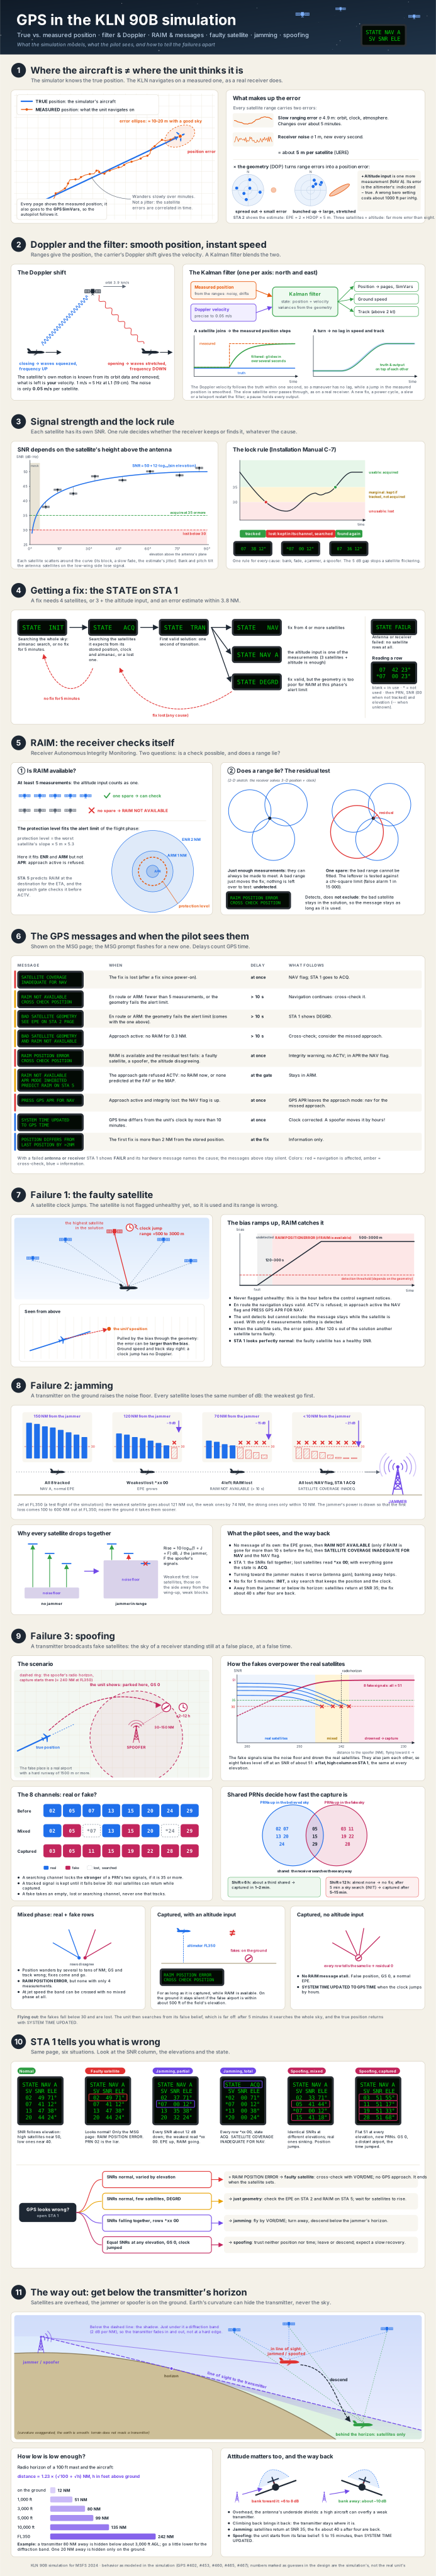
New GPS simulation
The GPS location previously was exact. This is no longer the case:
- The receiver now has a measured location. This location is not exact and is influenced by a ranging error and receiver noise.
- Receiver Autonomous Integrity Monitoring (RAIM) monitors the ranges and catches errors in the signals, but does not exclude them.
- A Kalman filter takes the measured location and the Doppler velocity in and calculates the GPS location. There is not much of a visible difference compared to previous versions in normal use, but the richness of this simulation matters for failure scenarios
- The unit now behaves correctly in all phases of flight when the signal is degraded, lost or RAIM detects an error
- RAIM prediction is now also performed right before switching to ACTV mode during approach
See this graphic for an overview how this version of the KLN-90B simulates the GPS system and how the failures are based on a physics system and not scripted:
https://raw.githubusercontent.com/falcon71/kln90b/refs/heads/main/docs/kln90b-gps-infographic.svg
Failures
The KLN now features a failure simulation. Pretty much everything that can fail in the real unit can fail in this simulation and every failure has a plausible effect on the operation of this unit.
- The failures are opt-in. Go to the SET 10 page and select
FAILURES?. Use MTBF on the FLR 1 page to enable random failures or use the FLR 3 page to manually trigger a failure - The unit can be serviced by a button on the FLR 1 page. This resets all failures, replaces the battery and corrects wrong GPS epochs. A single failure can be repaired on the FLR 2 page.
- The GPS failures are currently manual only until I have the data to trigger them in realistic locations:
- A faulty satellite will poison and degrade the GPS solution, RAIM will detect it
- Jamming causes a signal degradation until the navigation solution is lost
- Spoofing overpowers the real GPS signals with fake signals. The STA 1 page will eventually show fake satellites and the KLN will show a wrong location
- In addition several inputs, outputs or components can fail. Some will fails with a message, others without. A few failures must be enabled by aircraft authors. See panel.xml customization for details.
- The health of the internal battery is simulated. The health will degrade over 3 to 5 years. A battery at 0% health can fail, resulting in all user data being lost. Service the unit before that happens.
See https://github.com/falcon71/kln90b/wiki/Failures for more details on the failure simulation
Additional features and fixes
- The KLN will now recognize some fly-over waypoints and ask for the waypoint type (enroute or SID/STAR) during flight plan insertion
- Fixed error while typing and ident and then turning the unit off
- All outputs (SimVars and the Working Title flight plan) are now zeroed when the unit is turned off, just as they are when an interface has failed
- Hot switching from the KLN to other GPS units no longer affects their GPS solution
- The STA 1 page now switches back to the first page when the number of satellites drops below 4 while viewing the second STA 1 page
- The second STA 1 page now displays a header as seen on photos of the real unit
- A wrong GPS epoch now persists across sessions