Repository navigation
6.VIRTUAL IMPLEMENTATION
| Name of the Algorithm: CONTROL SYSTEM |
|---|
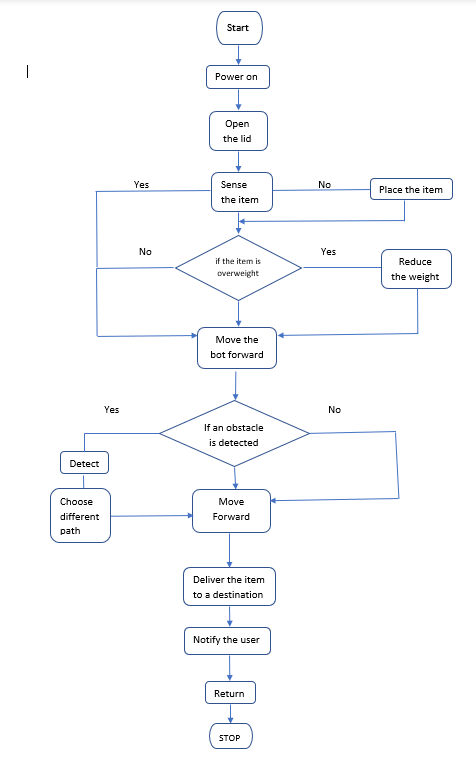
| Step 1: Start |
| Step 2: Read commands |
| Step 3: Accept commands |
| Step 4: Act according to the commands |
| Step 5: Open the lid |
| Step 6: Sense the item |
| if( item=1) |
| Display "item present " |
| else |
| Display "item Absent" |
| Step 7: Move the bot |
| Step 8: Deliver the item |
| Step 9: Close the item |
| Step 10: Stop |
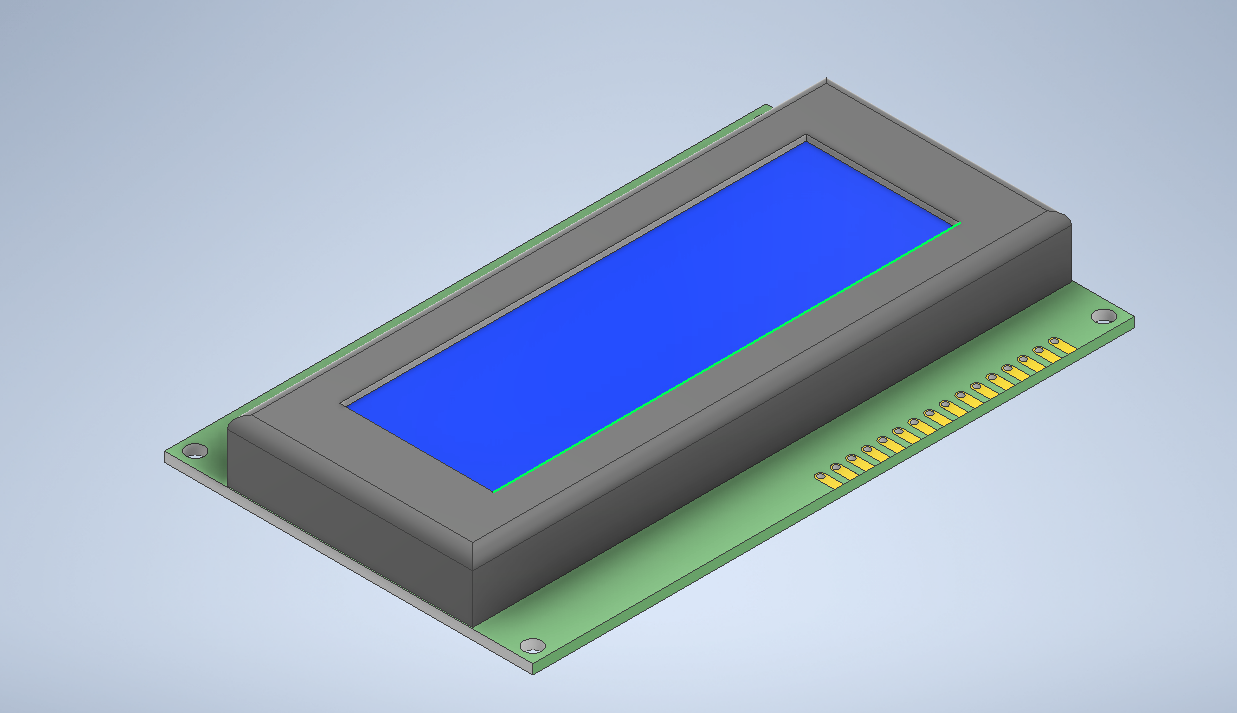
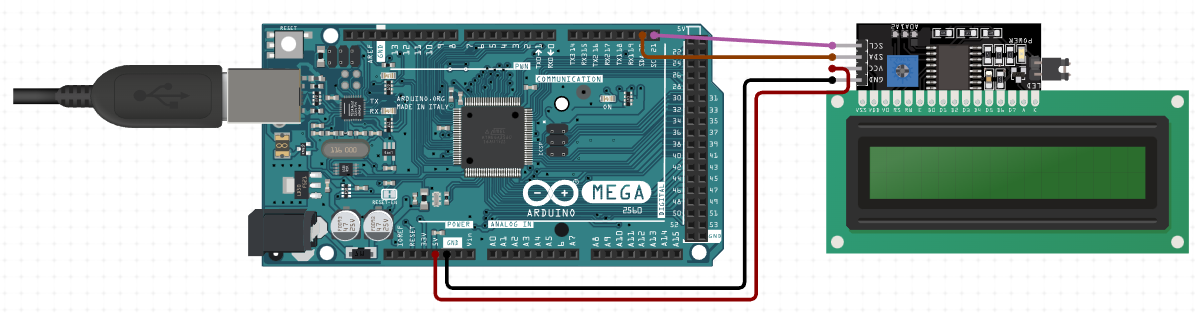
LCD for indications
| Name of the Algorithm: DETECTING |
|---|
| Step 1: Start |
| Step 2: Read the sense |
| Step 3: Read the command by the user |
| Step 4: Sense the obstacle |
| if(obstacle==1) |
| Display " obstacle Present" |
| else |
| Display "obstacle Absent" |
| Step 5: Stop |
| Name of the Algorithm: INDICATIONS |
|---|
| Step 1: Start |
| Step 2: Read the status |
| Step 3: Bot is ON/OFF |
| if(status==1) |
| Display "Bot is ON" |
| else |
| Display "Bot is OFF" |
| Step 4: Alerting the uncertain conditions |
| Step 5: Process status |
| Step 6: Presence or absence of the item |
| if(item==1) |
| Display " item is present" |
| else |
| Display " item is Absent" |
| Step 7: Delivery status |
| Step 8: Stop |
| Name of the Algorithm: STORAGE |
|---|
| Step 1: Start |
| Step 2: Read the item |
| Step 3: Open the lid |
| Step 4: Place the item |
| Step 5: Lock the storage item |
| Step 6: Close the lid |
| Step 7: Move the bot |
| Step 8: Unlock the storage unit |
| Step 9: Open the lid |
| Step 10: Deliver it |
| Step 11: Close the lid |
| Step 12: return |
| Step 13: Stop |
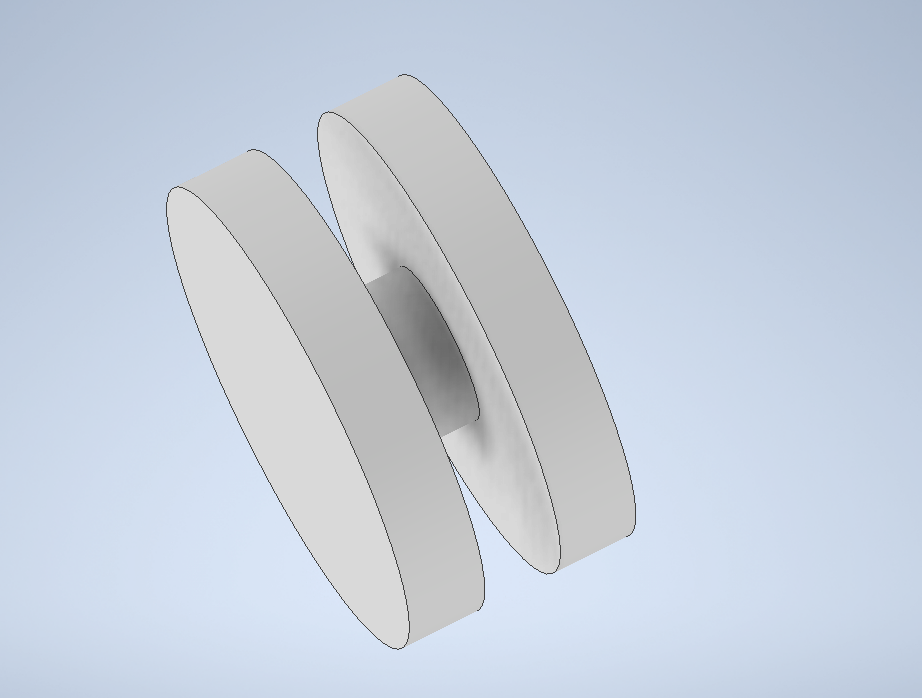
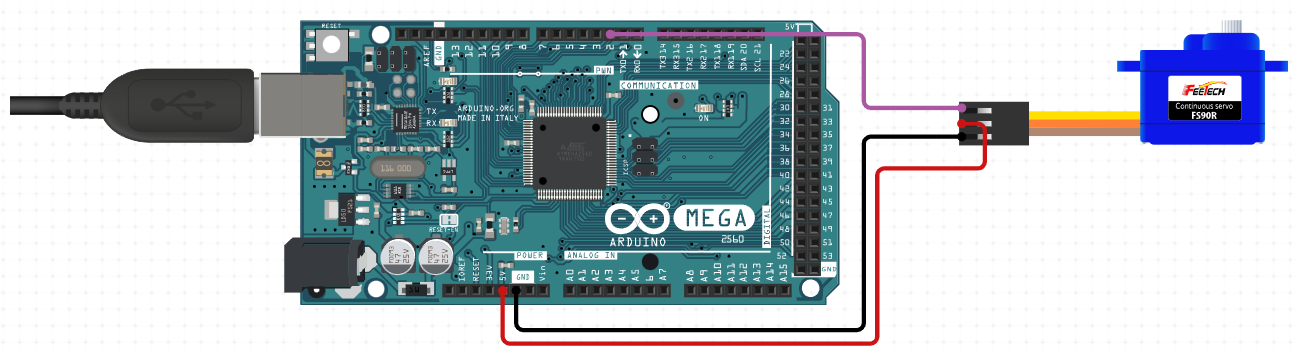
Pulley
| Name of the Algorithm: SECURITY |
|---|
| Step 1: Start |
| Step 2: Read the command |
| Step 3: Unlock the lid |
| Step 4: Sense the item |
| Step 5: Lock the lid |
| Step 6: Stop |
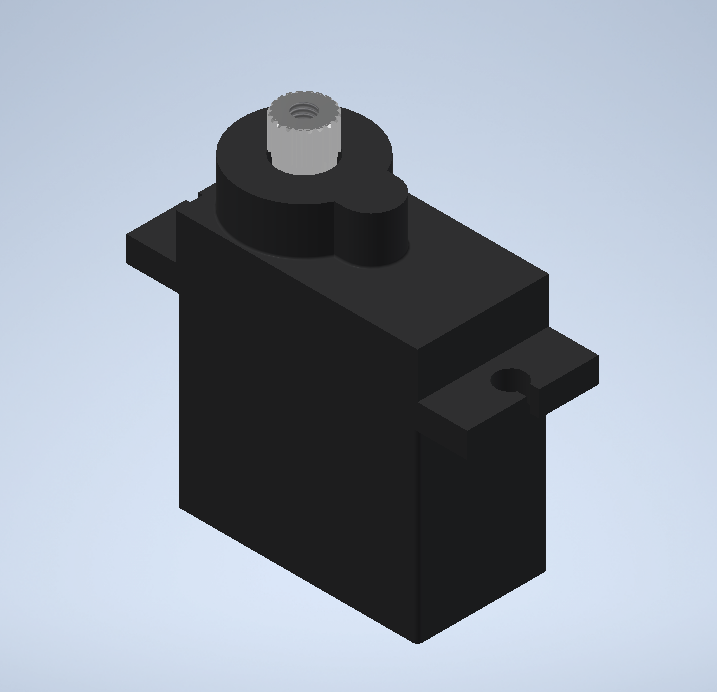
Servo motor
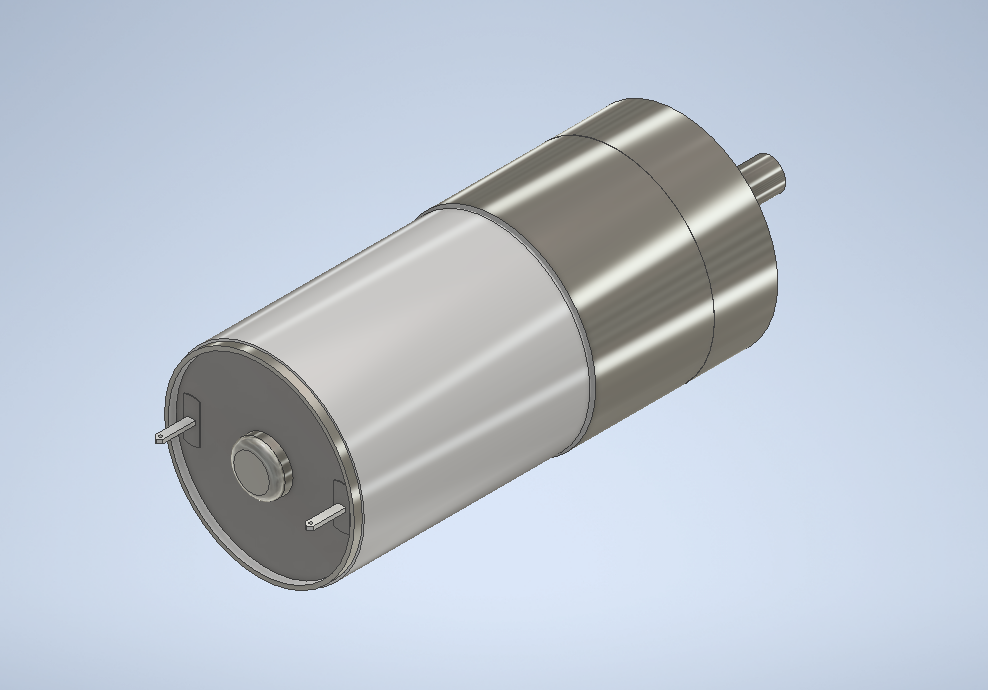
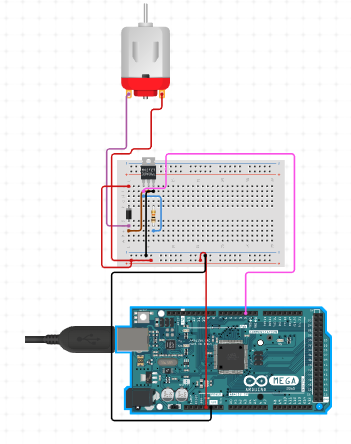
DC Motor
| Name of the Algorithm: DELIVERING/HANDLING THE ITEM |
|---|
| Step 1: Start |
| Step 2: Read Deliver |
| Step 3: Open the lid |
| Step 4: Store the item |
| Step 5: Sense the item |
| if(item==1) |
| Display ("item present") |
| else |
| Display ("item Absent") |
| Step 6: Close the lid |
| Step 7: Move the Bot |
| Step 8: obstacle status |
| if(obstacle==1) |
| Display ("obstacle Present") |
| else |
| Display ("obstacle Absent") |
| Step 9: Deliver the item to the destination |
| Step 10: Stop |
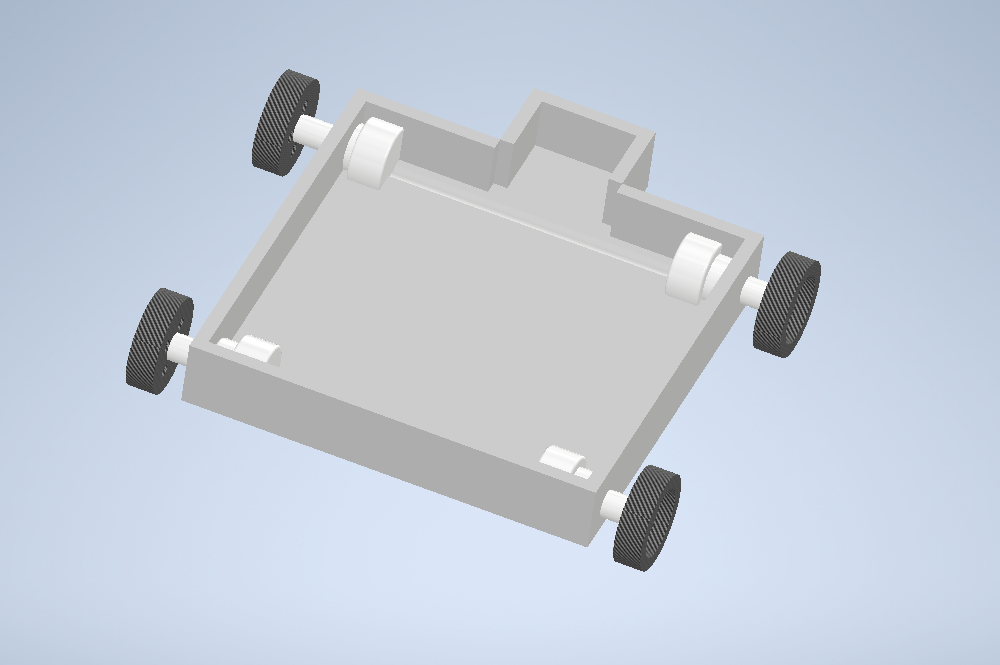
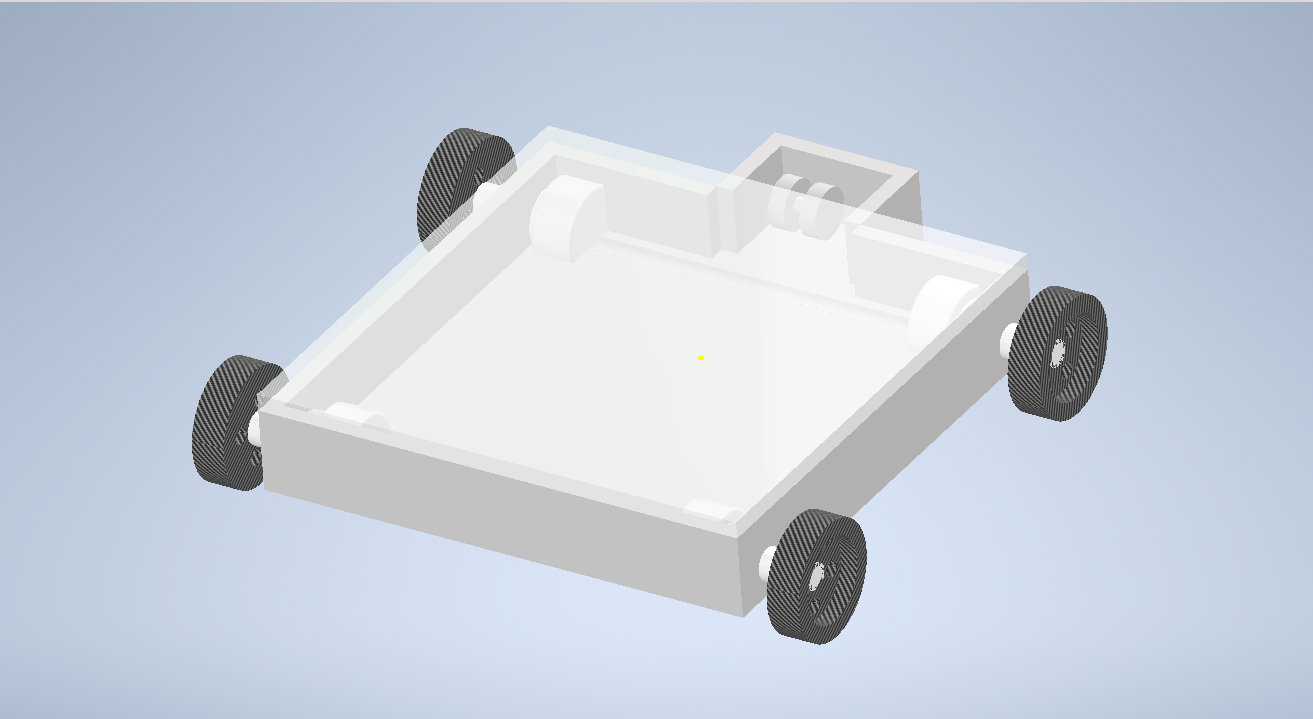
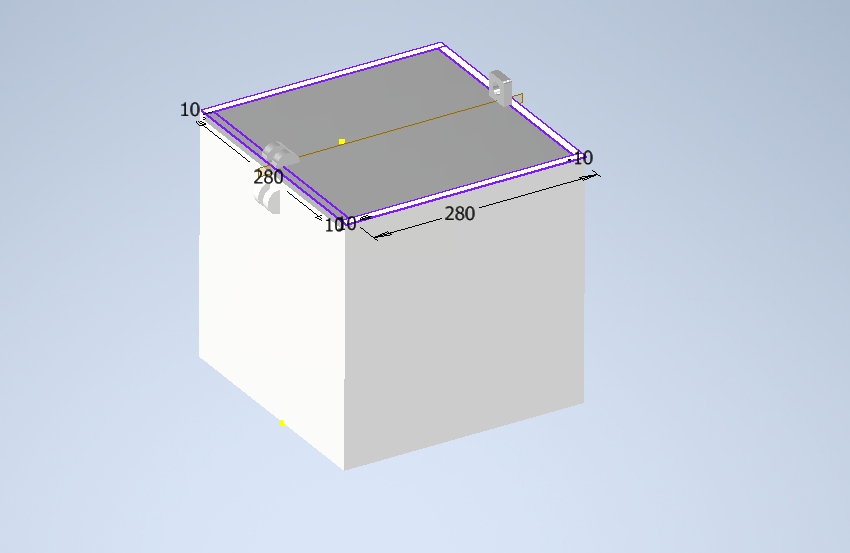
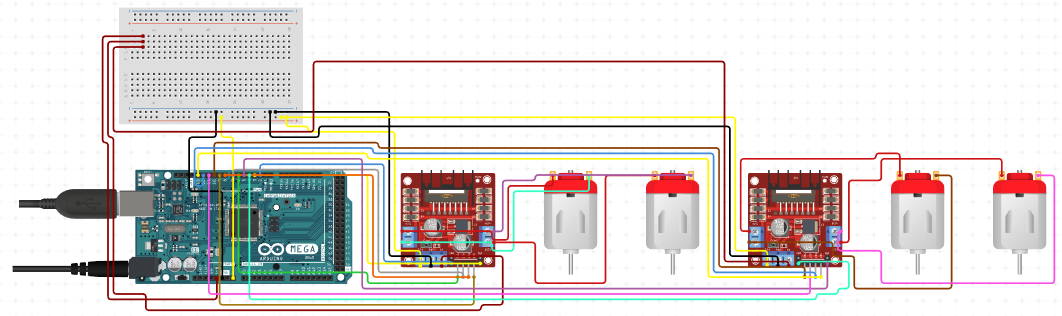
Containing all motors, sensors and circuits
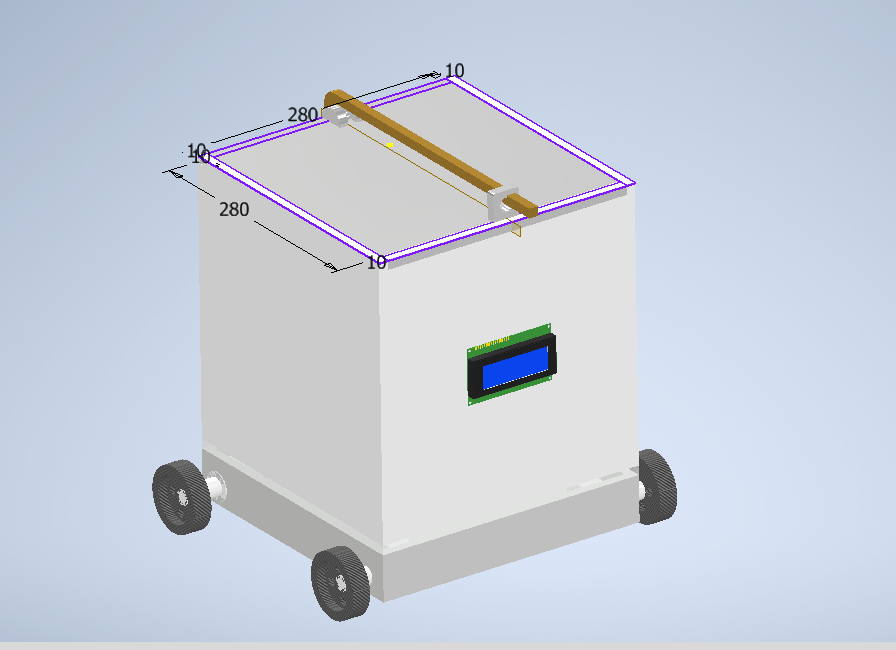
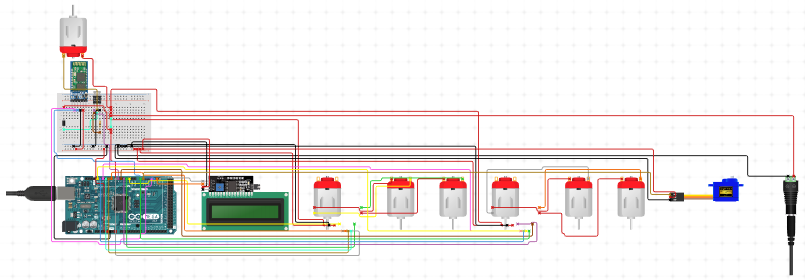
| Sl.No | Material name | Description of material | Quantity required | Fabrication process if needed |
|---|---|---|---|---|
| 1. | DC motor | 60 rpm and 12 v | 5 | ___ |
| 2. | Acrylic sheet | [(30 *30 *0.5),(30 *20 *0.5),(30 * 10 *0.5),(30 *5 *0.5)]cm | 2,4,1and4 Resp. | Cutting and Bending |
| 3. | Sensor | IR Sensor | 1 | ___ |
| 4. | Battery | 12v , 1.68*2 Ah capacity | 1 | ___ |
| 5. | Indication | LCD | 1 | __ |
| 6. | Micro Controller | ARDUINO mega 2560 | 1 | ___ |
| 7. | Single strand Wire | ___ | One packet (16 Wires) | ___ |
| 8. | Nuts and Bolts | Metal | 10,10 and 8 Resp. | ___ |
| 9. | L clamp | Metal | 24 | ___ |
| 10. | Aluminimum C-channel | Metal | 3 | ____ |
| 11. | Display | Mobile | 1 | ___ |
| 12. | Jumper Wires | M->M,M->F | 8 and 10 Resp. | ___ |
| 13. | Wheels | 4 cm radius | 4 | ___ |
| 14. | Servo motor | Tower pro SG 90 | 2 | __ |