Repository navigation
REAL Environment
The REAL environment is a standard gym environment.
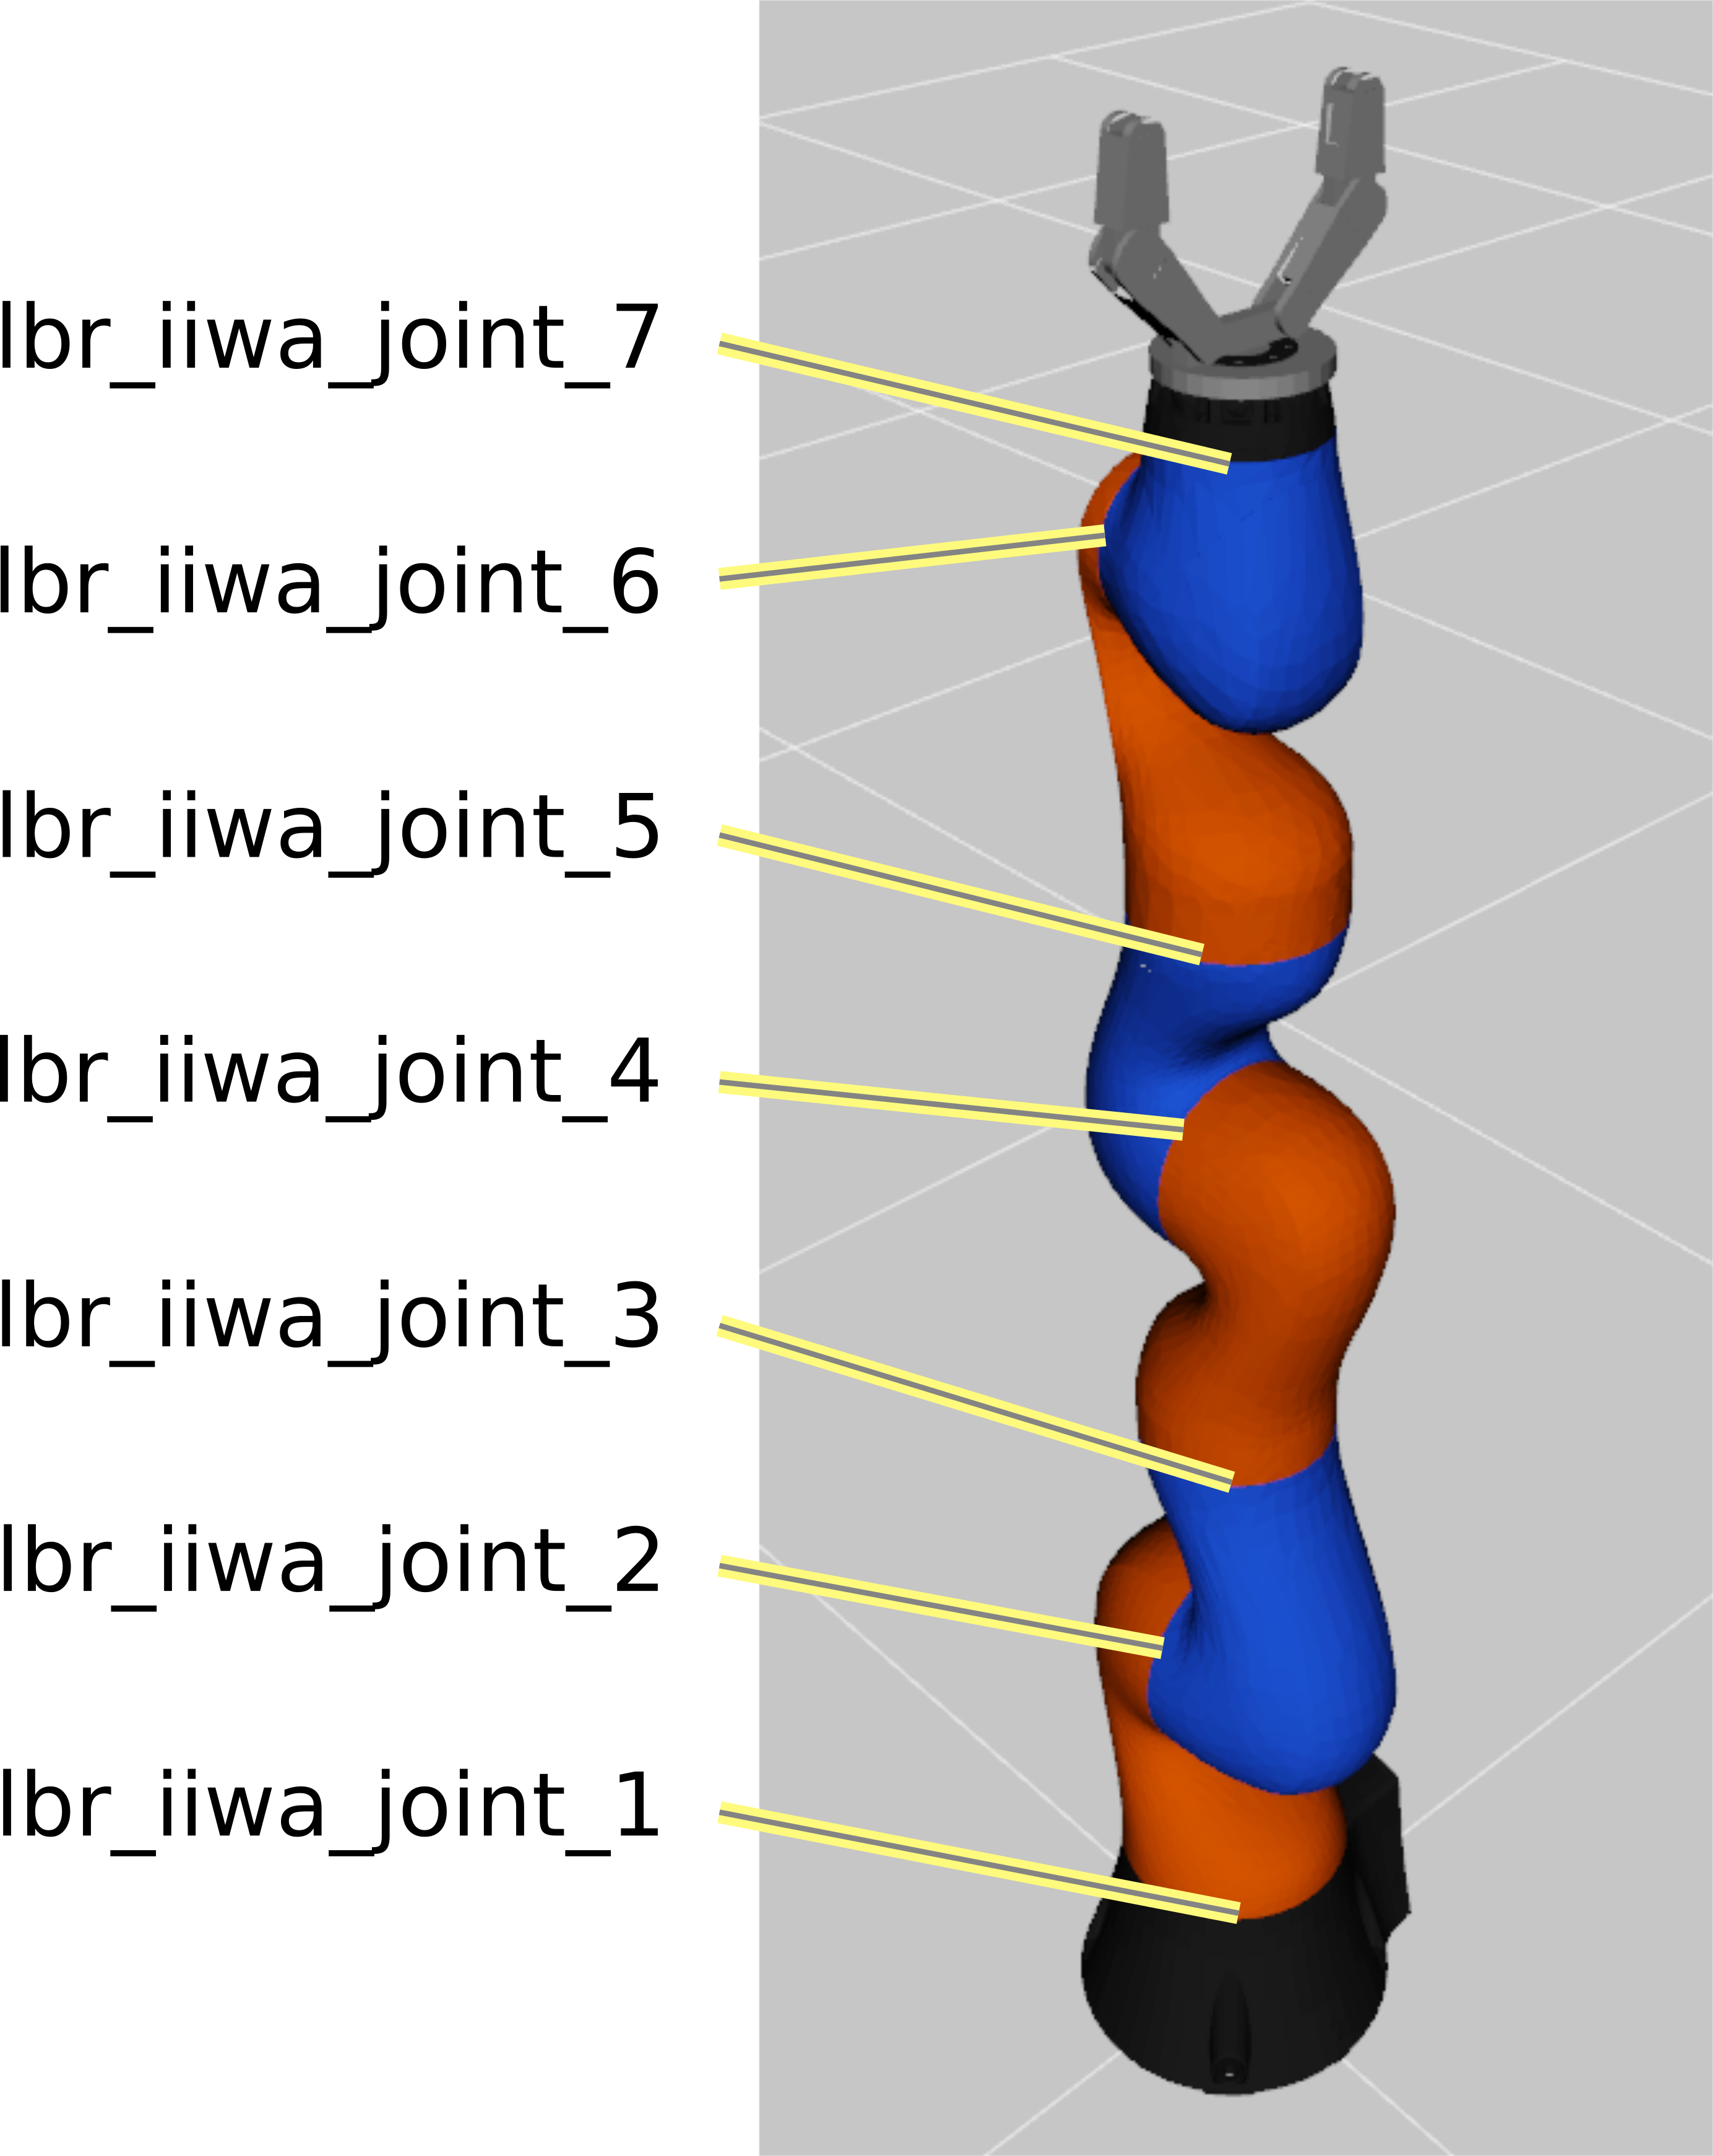
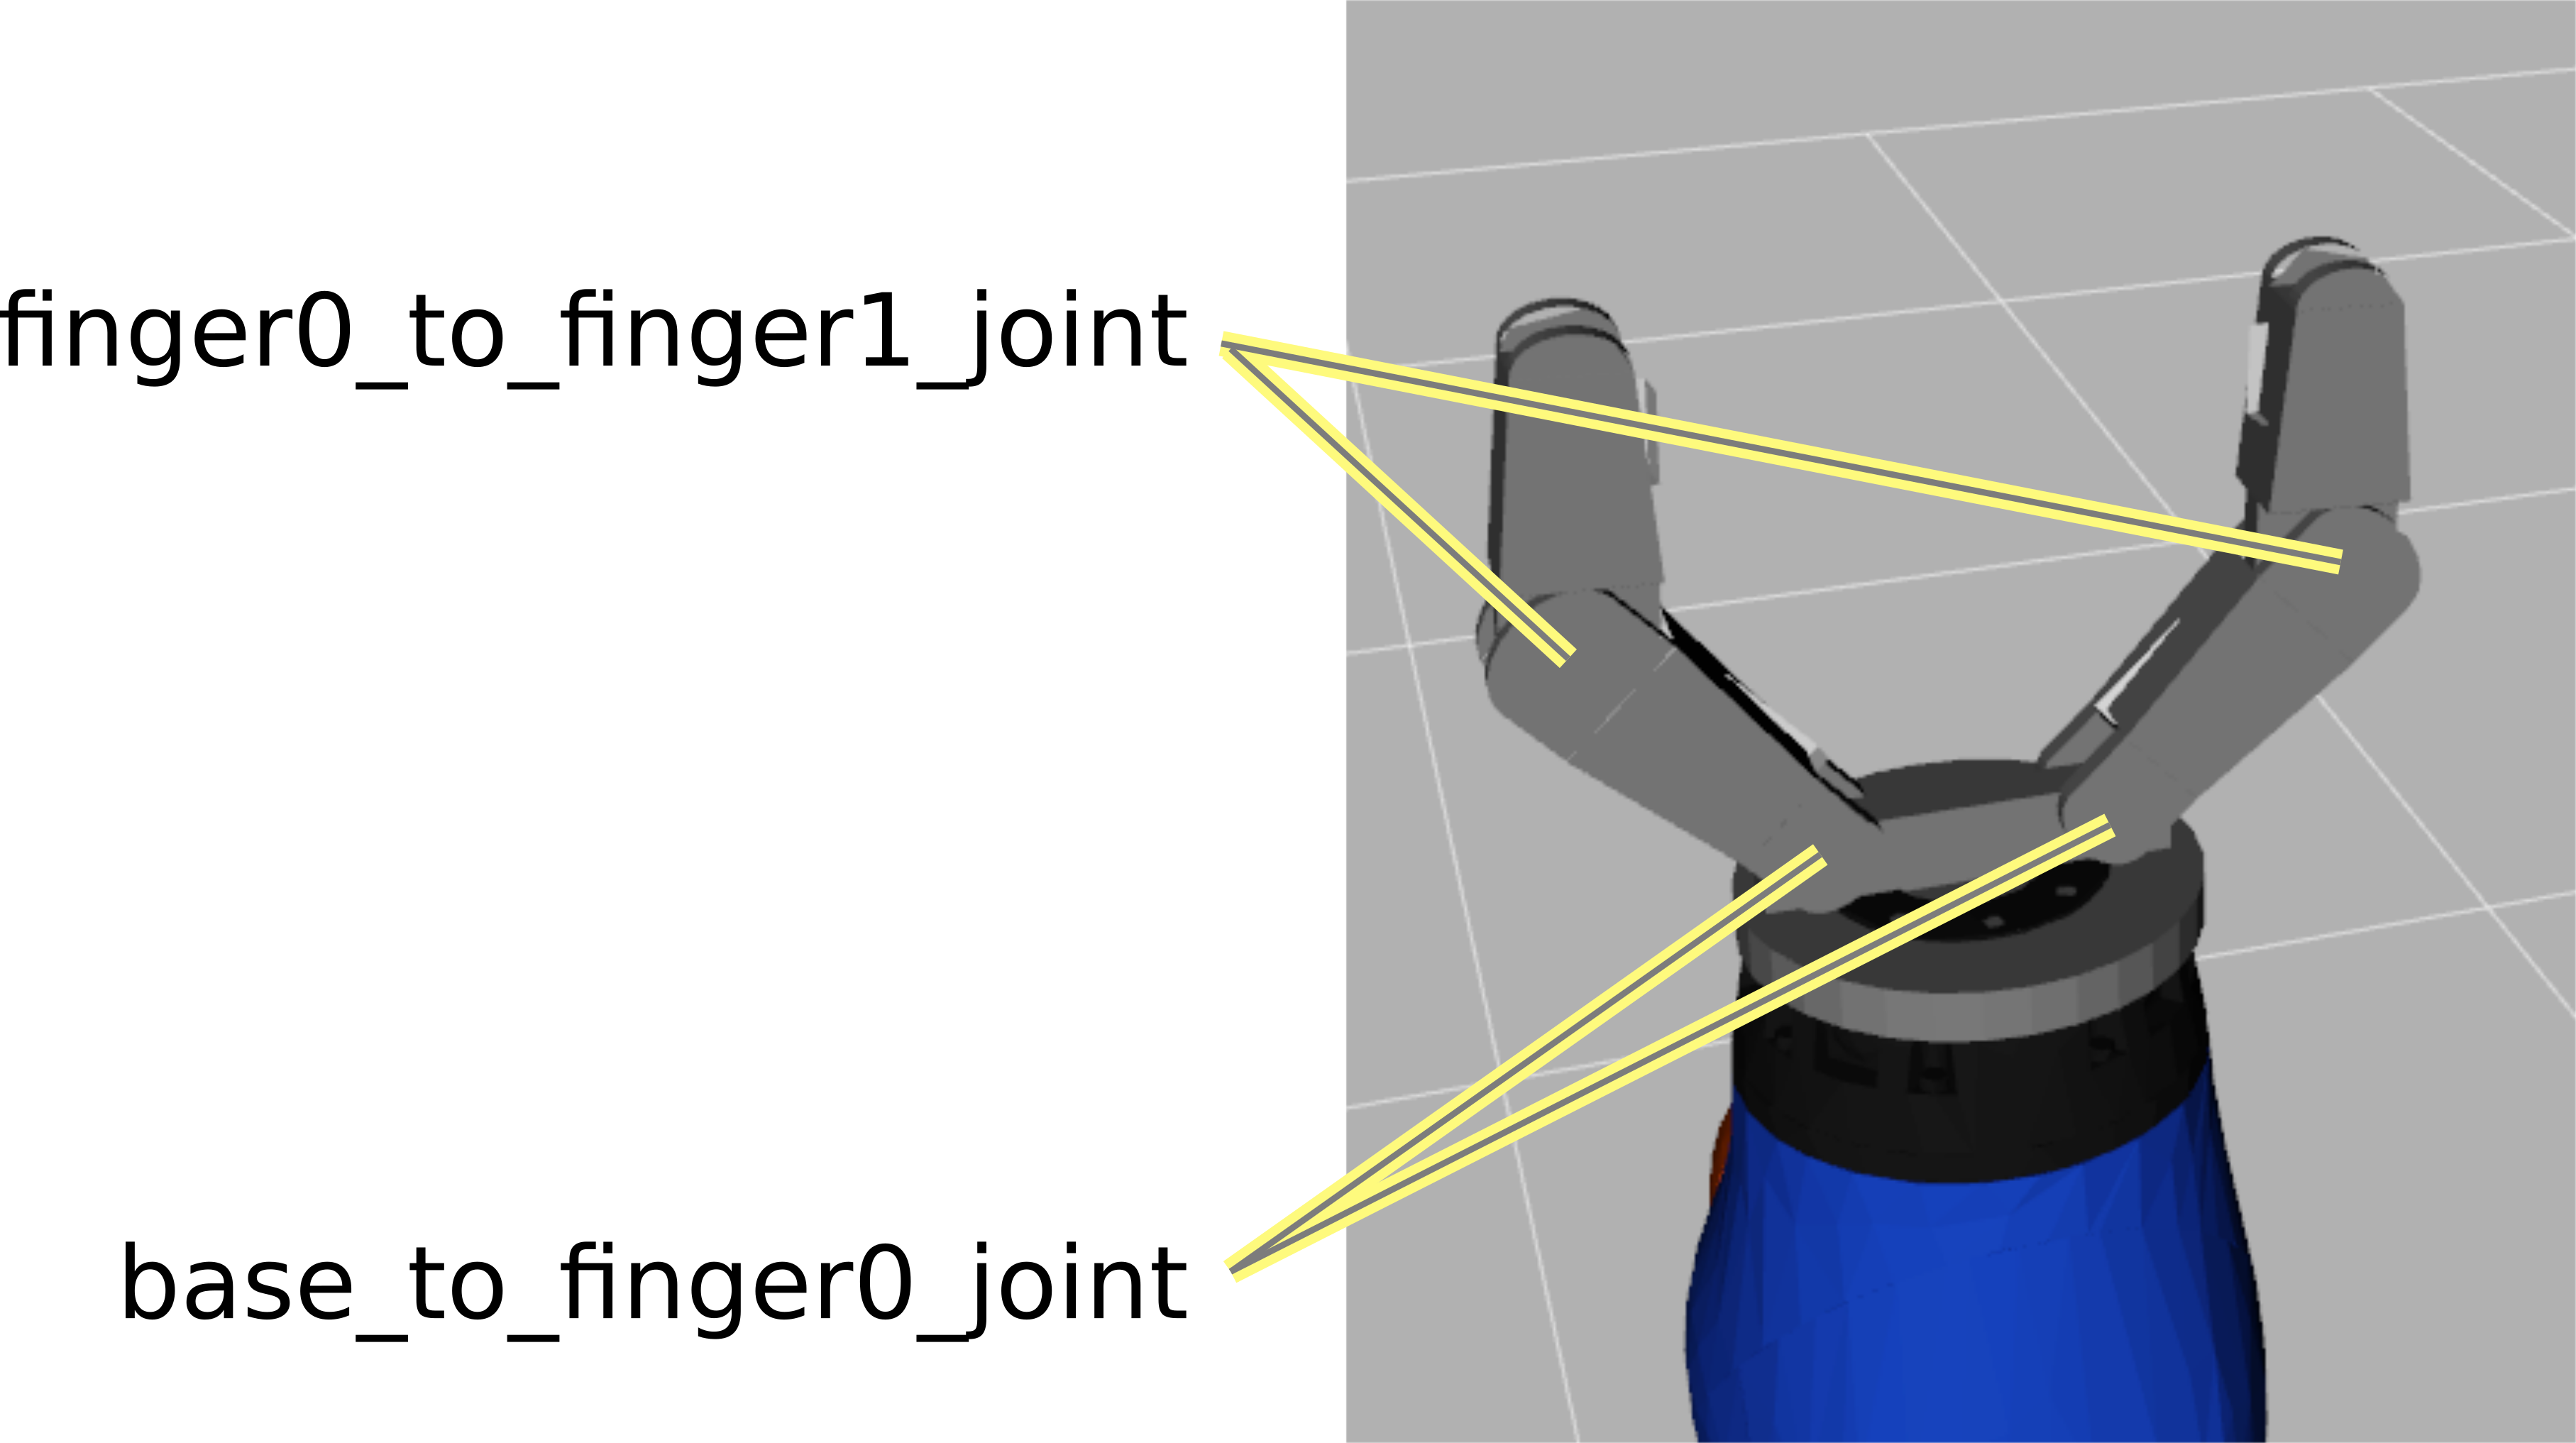
It includes a 7DoF kuka arm with a 2Dof gripper, a table with 3 objects on it and a camera looking at the table from the top.
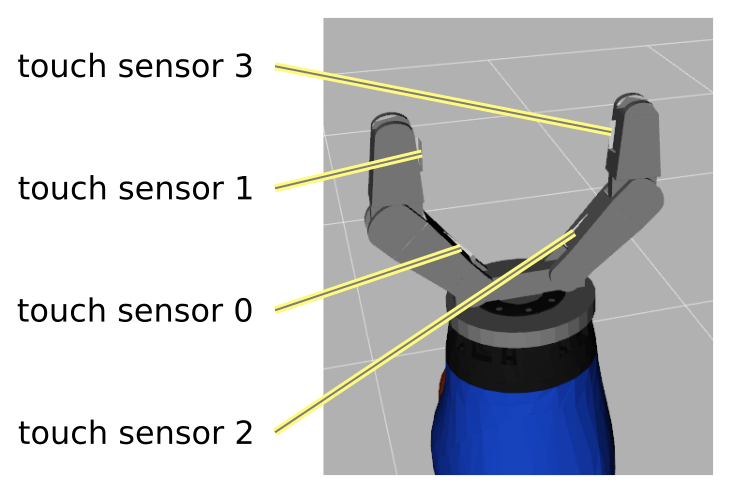
The gripper has four touch sensors on the inner part of its links.
The actionattribute of env.step must be a vector of 9 joint positions in radiants.
The first 7 joints have a range between -Pi/2 and +Pi/2.
The two gripper joints have a range between 0 and +Pi/2. They are also coupled so that the second joint will be at most twice the angle of the first one.
|
 |
 |
The observation object returned byenv.step is a dictionary:
- observation["joint_positions"] is a vector containing the current angles of the 9 joints
- observation["touch_sensors"] is a vector containing the current touch intensity at the four touch sensors (see figure below)
- observation["retina"] is a 240x320x3 array with the current top camera image
- observation["goal"] is a 240x320x3 array with the target top camera image (all zeros except for the extrinsic phase, see below)
Additional observations are available if the "Easy" environment is activated:
- observation["object_positions"] is a dictionary with object names as keys and the x, y, z position of the objects as values.
- observation["mask"] is a 240x320x3 array corresponding to the segmented image of the retina (each pixel has a value corresponding to an object id)
- observation["goal_object_positions"] same as object positions, but referred to the goal image.
- observation["goal_mask"] same as the mask, but referred to the goal image.
 |
The reward value returned byenv.step is always put to 0.
The done value returned byenv.step is set to True only when the intrinsic phase or an extrinsic trial is concluded.