Repository navigation
09. Using Plate Solving
Overview. Every control on this screen has detailed built-in help: hover it, press F1, or click the ? beside the title. See Built-in Help.
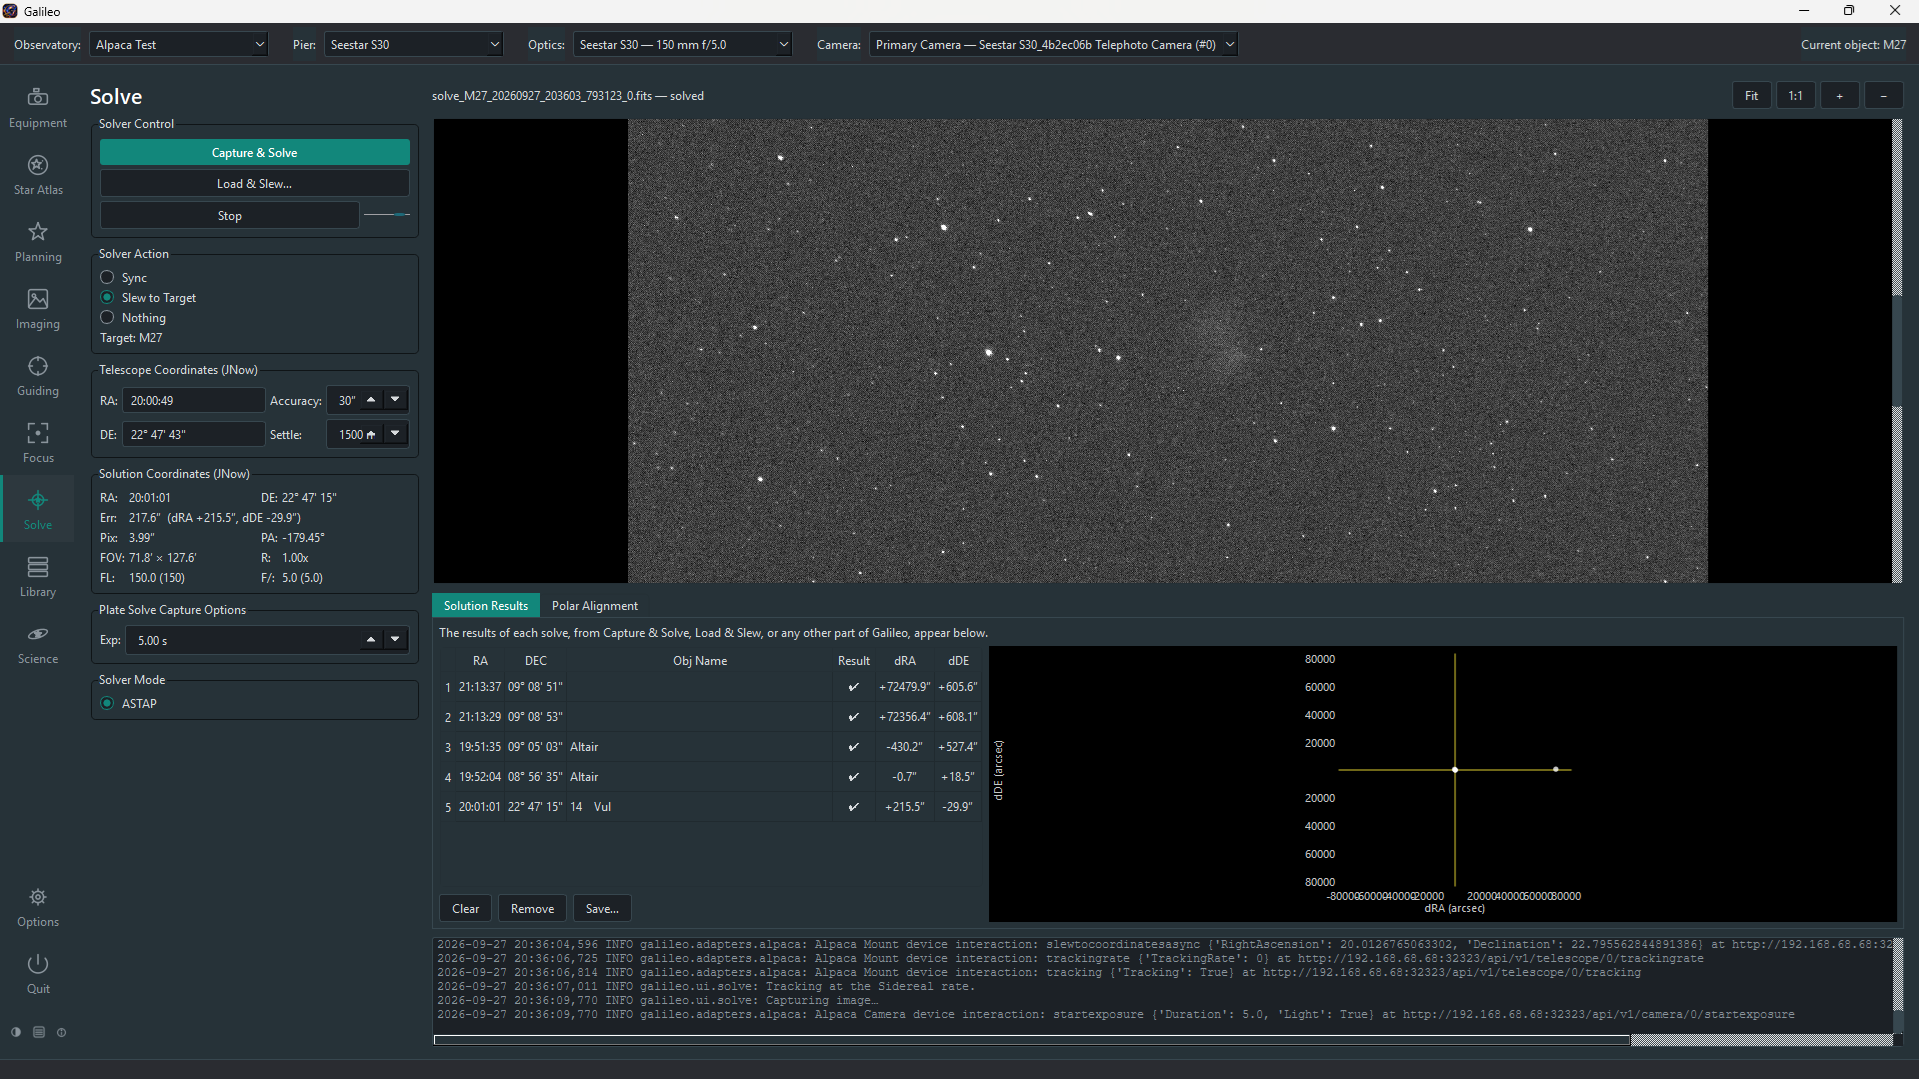
The Solve screen takes an exposure from the camera and determines exactly where the telescope is pointing by comparing stars in the frame to a catalog — a process called plate solving. Once solved, it can sync the mount's coordinate system or slew back to a target until pointing is within a chosen accuracy.
- Prerequisites
- Using tetra3
- Capture and Solve
- Load and Solve
- Solver actions
- Solve results
- Polar alignment
- Troubleshooting
-
ASTAP (download) installed on the same machine as Galileo, or on your
PATH. - An ASTAP star database (e.g. D50, H17, G17) downloaded and placed in ASTAP's database folder.
- A connected camera to take the exposure from.
No mount is needed to plate-solve, but the Sync and Slew to Target actions require one.
Besides ASTAP, Options > Solve can use a local astrometry.net (solve-field and its index files, mainly Linux and macOS; works offline), ESA's tetra3 (fast and offline, run inside Galileo; see Using tetra3) or the nova.astrometry.net web service (needs an internet connection and your API key; the frame is uploaded). The choice is saved per Pier and the Solve screen's Solver Mode can override it for one run. Plate Solve Capture Options also lets you set binning, gain/ISO, the filter for the solve exposure. The Subtract dark checkbox shows the frame on screen with the Library's dark master removed (when one matches your camera, optics and exposure); it changes only the picture, never what is solved. Every control has built-in help.
Galileo searches these locations in order:
| Platform | Locations checked |
|---|---|
| Windows |
C:\Program Files\astap\astap.exe, PATH
|
| macOS |
/Applications/ASTAP.app/Contents/MacOS/astap, PATH
|
| Linux |
~/.local/bin/astap, /usr/local/bin/astap, PATH
|
If ASTAP is installed elsewhere, add its folder to your PATH before starting Galileo.
Options > Solve sets how plate solving runs for the Pier: the ASTAP program's location, a field-of-view hint, the search radius and the downsample factor, and which solver to use. They are saved per Pier, so each telescope keeps its own settings — choose the Pier in the top bar first.
tetra3 is ESA's offline "lost in space" solver. It ships with Galileo (the prebuilt installers and the source-install scripts both include it), so there is nothing to download.
- In Options > Solve, choose tetra3 (ESA, local) as the solver and press Save (or pick Tetra3 under Solver Mode on the Solve screen for a single run).
-
Star database. Leave tetra3 database blank to use the one bundled with tetra3. That database is built for fields of 10–30°, which is far wider than most telescope-and-camera combinations, so with a typical imaging setup it will not solve. Instead, press Generate tetra3 databases in Options > Solve:
- Choose Generate for: the Current Pier, or All Piers in all Observatories.
- Galileo works out each Pier's field of view from its optical tubes (focal length) and cameras (pixel size and sensor width), so those need to be filled in on the Equipment pages first. A Pier whose optics are incomplete is skipped and listed. Piers with the same field share one database.
- It lists what it will build and asks you to confirm. The first build downloads a star catalogue (about 51 MB for fields of 3° and wider, about 354 MB for narrower ones) and keeps it for later.
- The build runs in the background, so you can carry on using Galileo, and Cancel build stops it. A narrow field can take hours. Each finished database is selected automatically as that Pier's tetra3 database.
You can also point tetra3 database at a
.npzfile you built yourself.
- tetra3 does not use the mount's position, so set the Field-of-view hint in Options > Solve (or leave it on Auto, derived from your optics). The first solve is slow while the database loads; later ones reuse it.
If you installed Galileo into your own Python environment and Galileo says "tetra3 not installed", run python -m pip install "tetra3 @ git+https://github.com/esa/tetra3.git" in that environment and restart.
- Open Solve in the sidebar. Make sure the correct optical tube is selected in the top bar.
- Set the exposure time (short, 2–5 s is usually enough for bright stars).
- Choose a Solver action (see below) — it defaults to Nothing so a click never moves your mount unasked.
- Click Capture & Solve. Galileo takes the frame, runs ASTAP, and shows the result. A progress bar under the buttons shows the exposure counting through, then "downloading…" until the frame arrives.
Click Load & Solve… to solve an existing FITS file from disk without taking a new exposure. This is useful for diagnosing a pointing problem from a saved frame or for solving a frame taken on the Imaging screen.
After a successful solve, the selected action runs automatically:
| Action | What it does |
|---|---|
| Nothing | Shows results only. Does not touch the mount. |
| Sync | Syncs the mount's internal coordinate model to the solved position. One-time improvement. |
| Slew to Target | Slews to the Pier's current object (set in Star Atlas), solves again, and repeats until the pointing error is within the Accuracy threshold. If no current object is set, slews to wherever the mount was pointing before the solve. |
Load & Slew… also makes its destination the Pier's current object (named from the file's OBJECT card, else its coordinates), so a following Slew to Target returns to that field rather than an earlier target.
The Accuracy field (arcseconds) sets the threshold for the "Slew to Target" convergence loop. 30″–60″ is typical for visual work; 10″–20″ for tight framing.
Tick Auto-Centre to have Galileo capture, solve and slew back onto the Pier's current object straight away and then repeat every Auto-Centre Cadence (2 minutes by default, 1–720), so slow drift is corrected without you pressing anything. Each pass uses Slew to Target whichever action is selected, so it needs a current object, a connected camera and mount, and a working solver. It shares the camera with everything else, so a pass is skipped while a session or the Imaging screen is capturing, and the option is disabled (and unticked) while guiding is running. Stop, or switching Pier, turns it off.
A successful solve shows:
| Result field | Meaning |
|---|---|
| RA / Dec (J2000) | The centre of the solved field in equatorial coordinates |
| Field of view | Solved angular size of the frame (width × height in arcminutes or degrees) |
| Pixel scale | Arcseconds per pixel as measured from the solve |
| Rotation | Position angle of the field (north through east, degrees) |
| Pointing error | Angular distance between the mount's reported position and the solved position (if a mount is connected) |
| Solve time | How long ASTAP took |
A failed solve shows the reason (too few stars detected, no match found, solver not found) in the log pane at the bottom.
Like the Imaging screen, this screen arranges itself to suit the frame: a portrait frame (taller than wide) gets a full-height column on the right, a third of the screen wide, with the other panels beside it; the error plot (the bullseye) then sits above the results table instead of beside it. Tick View > Choose layout manually to pick Portrait or Landscape yourself. A one-shot-colour camera's frames are shown in colour automatically.
The Polar Alignment tab helps you point the mount's polar axis at the celestial pole. It needs a camera, a mount and the Observatory's latitude and longitude. How it starts depends on the Slew from Zenith checkbox:
- Checked: you don't need to point the scope anywhere first. Press Start Polar Alignment and Galileo slews to the zenith and solves there. If the solution shows the mount was not really at the zenith (it has never been synced, say), it syncs the mount to the solution and slews to the zenith again. That solve at the zenith is also the first measuring position; it then turns in RA from there for the other two.
- Unchecked (default): Galileo solves where the mount already points right now, syncing the mount to the solution if it is off, and measures from there at that declination. Nothing moves the mount first, so point it at a clear field away from the pole and the meridian beforehand. The zenith start is there for a mount that has never been synced; it also moves the scope to a position where focus can differ from the one you set.
Either way it then solves three frames while turning the mount in RA (15° by default, east or west) to find where the axis really points. After every move it waits until the mount reports it has stopped, then pauses at least 5 seconds (more if the Settle value under Capture Options is larger) before exposing, so stars are not trailed.
Once the axis is measured the tab keeps solving and shows an aiming view: a circle where the axis points now and an X for the celestial pole. Turn the altitude and azimuth adjusters to bring the X into the circle; it turns green when you are within a minute of arc. The total error and the written correction for each adjuster are shown too. The mount must be level and clear of the meridian. Every control has built-in help.
The phone/tablet app's Solve screen carries the same controls as this one: the bullseye of how close each solution landed to its target, an exposure field, Capture & Solve, Load & Slew (which lists recent Library frames on the Galileo computer to choose from) and Stop, the Solver Action (Sync, Slew to Target by default, Nothing), and a Latest result panel with the Solution Coordinates (JNow).
The whole routine can also be run from the MobileConnect phone/tablet app (on the Solve screen) and the WebConnect browser interface (the Polar tab), which suits standing at the mount with the device in your hand. They show the same live total error, the written correction for each adjuster, a plot of the X against the circle and a trend of the error, updated on every solve. On the phone/tablet app the frame itself refreshes in a loop with the circle (where the mount's axis points), the cross (the celestial pole) and an arrow between them showing how far and which way to move, so you can correct the mount while watching the stars. The Pier needs a camera, a mount and a located Observatory, and no session or solve running.
| Symptom | Try this |
|---|---|
| "ASTAP not found" | Install ASTAP and ensure its folder is on your PATH, or that ASTAP is in one of the locations Galileo checks (see above). |
| "tetra3 not installed" | Only seen in a hand-built Python environment; see Using tetra3. |
| "No star database" | Download a database in the ASTAP interface (File > Download star catalog). The D50 or H17 databases cover all magnitudes Galileo needs. |
| Solve fails with "too few stars" | Use a longer exposure, choose a less crowded area of sky, or reduce the minimum magnitude in Options > Solve. |
| Solve succeeds but sync does not improve pointing | The mount may need a multi-point pointing model. Solve and sync from several positions across the sky. |
| Pixel scale in the result disagrees with your optics | Check the focal length and aperture entered under Equipment > Optics for this optical tube. |