Repository navigation
Releases: roboninecom/SO-ARM-102
Release list
SO-ARM 102 v0.2.0 — Hardware update and LeRobot setup

SO-ARM 102 now uses a Waveshare Bus Servo Adapter for both arms, with updated hardware files and setup documentation.
What's changed
- Replace the follower HAT with a Bus Servo Adapter; update controller mounts, STEP/STL files, 3MF projects, printing instructions and photos. Update the BOM for passive ST-3215-C066 leader servos. (#20)
- Replace placeholder URDF/Xacro effort and velocity limits with servo datasheet values. These represent stall torque and no-load speed, not continuous operating ratings. (#21)
- Add complete leader/follower STEP and STL assemblies. (#16, #17)
- Add the LeRobot plugin setup guide and README links. The plugin remains in its separate repository. (#19)
- Add documentation in ten languages and correct Japanese translations. (#13, #15)
For new builds, use the updated controller mounts and 3MF files together with the revised BOM.
Validation: URDF and Xacro parse as XML. No hardware fit test was performed for this release; the latest merged PRs have no CI check results.
Full changelog: v0.1.1...v0.2.0
SO-ARM 102 v0.1.1 — BOM, sourcing and printing documentation
This maintenance release improves sourcing, build planning and licensing documentation for one SO-ARM 102 leader + follower kit.
What's changed since v0.1.0
Component sourcing and kit budget
- Expanded the bill of materials with purchase links and reference prices from Amazon US/EU, AliExpress and Alibaba, plus category totals and a linked README summary.
- Documented an estimated $404.09 for components, or $443.68 including printing material. Buying the example full packs and filament spools is approximately $503.70, including unused spares.
- Clarified the servo selection: six 7.4 V STS3215 units for the leader, two 12 V STS3215 units for the follower wrist roll and gripper, two STS3235 units and two STS3250 units. The joint table now specifies model variants and gear ratios.
- Added power connector details, camera selection notes, included servo-kit fasteners and steel/carbon guide alternatives.
These are BOM reference estimates, not newly verified supplier quotes. Shipping, taxes, tools, a computer, a printer, electricity and assembly labour are excluded. Confirm variants, minimum order quantities and prices before ordering.
Printing guidance
The printing guide now lists material weights and print times for the saved projects:
| Project | Material weight | Print time |
|---|---|---|
| Leader | 457 g | 23 h |
| Follower arm | 583 g | 23 h |
| Follower gripper and board case | 131 g | 6.5 h |
| Total | 1,171 g | 52.5 h |
The documented material split is 583 g Fiberon PET-CF17 and 588 g Bambu PETG-CF. The BOM budgets 0.6 kg PET-CF17 + 0.6 kg PETG; re-slice the projects for your printer and filament to determine actual requirements.
Description and licensing
- Corrected the README description to five degrees of freedom plus a gripper.
- Explicitly documented CC BY 4.0 for all
simulation/assets, including URDF/Xacro, meshes and export metadata, and added a matching REUSE annotation. This makes the existing license coverage explicit.
This release changes documentation and license annotations only. CAD, STL, 3MF and robot description files are unchanged from v0.1.0.
Full changelog: v0.1.0...v0.1.1
SO-ARM 102 v0.1.0 — First public release
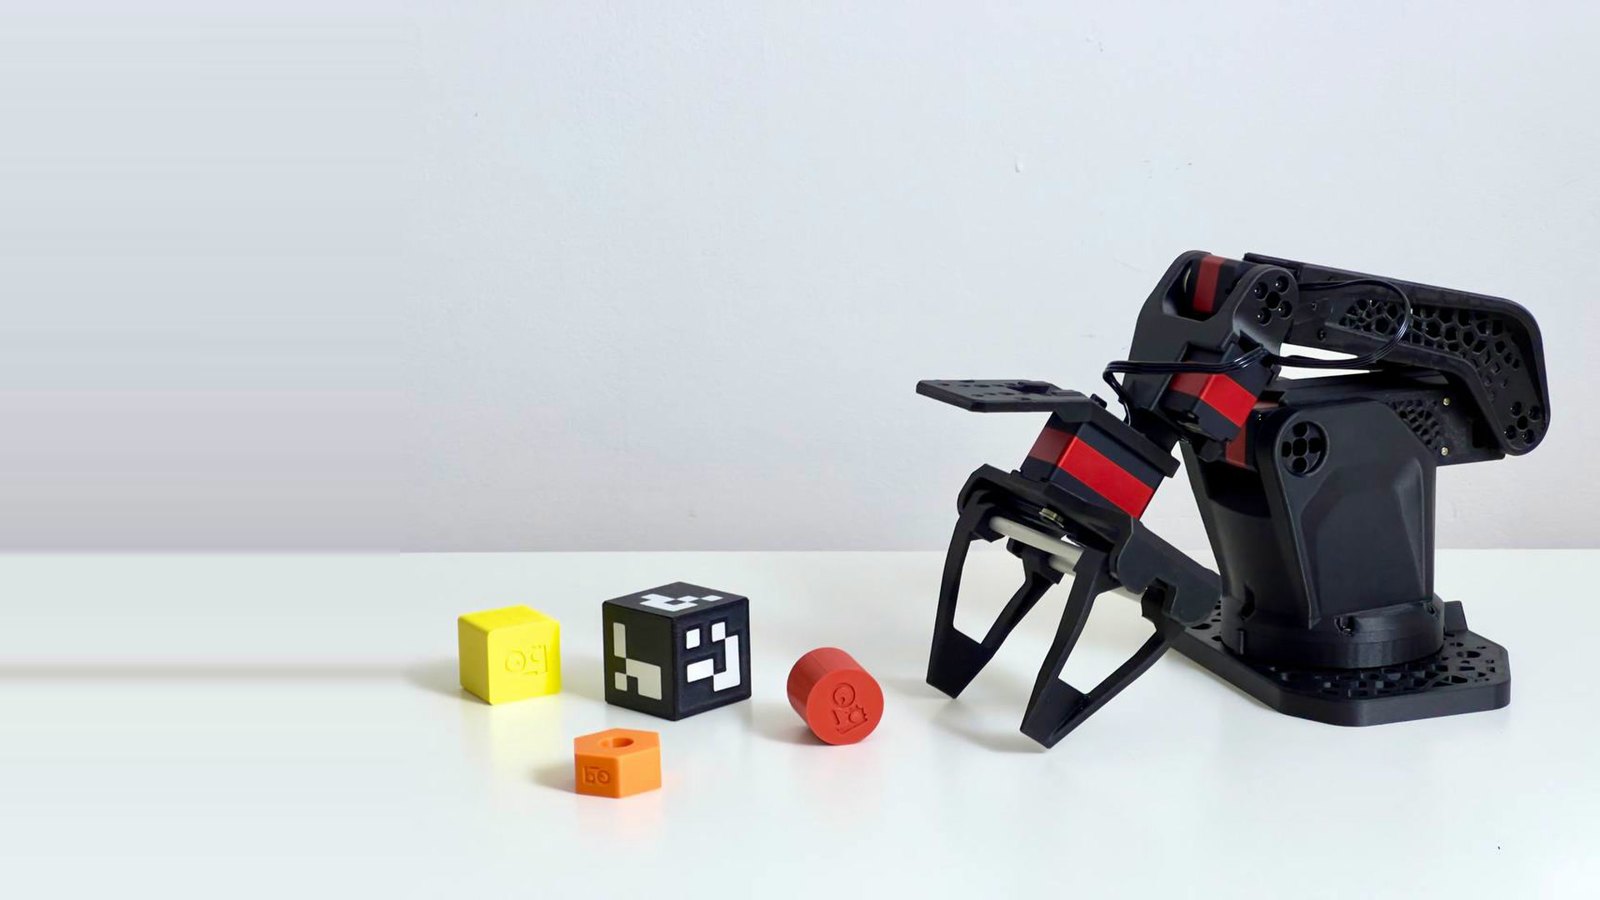
SO-ARM 102 is an open-source 6-DOF leader and follower robot arm kit by Robonine, designed for teleoperation and imitation learning. Move the leader by hand and the follower repeats the motion, allowing you to control the arm and record demonstrations. Two kits can be used together for bimanual tasks.
The design combines a parallel gripper with an 85 mm span, a PET-CF frame with topology-optimised links, 483 mm horizontal reach and 352° base rotation. It keeps the SO-ARM 101 joint layout for use with Hugging Face LeRobot datasets and policies.
This first public release provides the design files, print projects, robot descriptions and documentation for building and exploring the SO-ARM 102.
Watch the preview video · Read the build guide · Buy the kit
What changed compared with SO-ARM 101
SO-ARM 102 retains the leader/follower workflow and joint layout of SO-ARM 101, while adding a parallel gripper, a PET-CF frame with topology-optimised links, a larger working range and faster shoulder and elbow servos.
| Feature | SO-ARM 101 | SO-ARM 102 |
|---|---|---|
| Gripper | Angular jaw | Parallel jaws, 85 mm span |
| Frame material in the comparison | PLA | Fiberon PET-CF17 |
| Link structure | Solid links | Topology-optimised links |
| Horizontal reach | 441 mm | 483 mm (+9.5%) |
| Reach behind the base | 377 mm | 473 mm (+25.5%) |
| Base rotation range | 220° | 352° (+60%) |
| Elbow range | 194° | 243° (+25%) |
| Frame deflection at the gripper, 300 g load¹ | 7.5 mm | 3.4–3.9 mm (48–55% less) |
| Shoulder and elbow no-load speed² | 45 RPM (STS3215) | 75 RPM (STS3250), +67% |
| Base joint backlash | 8.75 counts | 5.00 counts (43% less) |
| Rated payload | 250 g | 300 g (+20%) |
| Noise at 1 m | 70 dB | 60 dB |
¹ Frame stiffness tests used printed servo dummies in joints 2, 3 and 4 with the arm fully extended. SO-ARM 101 was printed in PLA; SO-ARM 102 in Fiberon PET-CF17 at 25% infill. Two SO-ARM 102 runs gave 3.4 and 3.9 mm. These results compare the frames; they are not powered-arm positioning accuracy measurements.
² No-load speeds are calculated from servo datasheets. Reach values are calculated from the robot geometry and joint limits.
See specifications and test conditions for the full comparison.
Where to buy the components
DIY budget for one leader + follower kit: about $629 for components, or $684 including printing material. Buying the example full packs and filament spools from scratch is about $760. These USD estimates mix supplier prices, historical shared-part prices and clearly marked planning allowances; shipping, taxes, optional O-rings, tools, a host computer and a printer are excluded. See the linked BOM for item prices, category totals and quantity assumptions.
Build your own kit using the full BOM with purchase links, covering servos, controllers, power supplies, the wrist camera, bearings, rods, clamps, fasteners, printing materials and tools for one leader + follower setup. The guide links to supplier product pages and clearly labelled searches for standard hardware. Check the selected sizes, pack quantities and power connectors before ordering; the leader uses 5 V and the follower uses 12 V.
Prefer a complete set? Buy the SO-ARM 102 kit from Robonine.
This sourcing guide is a documentation update proposed in PR #6; it is linked separately from the original v0.1.0 source archive.
Included
- STEP sources and STL meshes for printing, including the updated base and camera holder.
- 3MF slicer projects for the leader, follower and follower gripper box.
- URDF and Xacro robot descriptions with simulation meshes and export metadata.
- Bill of materials, printing guidance, assembly documentation and the A5 assembly booklet.
- Updated servo cable information and team contacts.
Download the source ZIP or tarball below for the complete release contents.
Assembly notes
Documented build considerations include difficult access to some M2 screws, tight gripper clamp fit on carbon rods, servo cable routing and lengths, awkward assembly order in parts of the booklet, and loose-feeling leader joints. See the README and assembly documentation for details and the suggested O-ring adjustment.
The README's known-issues section still mentions a missing camera-holder STEP source; this release includes models/step/follower/RB9.01.062.075 Camera holder.STEP and its STL mesh.
Validation
GitHub CI passed for release commit e0e824b324d514363d702782020d6cd19d25b804. CI runs the repository's pre-commit checks, including REUSE licensing validation. This does not establish physical fit or validate simulation behavior.
Licenses
Hardware: CERN-OHL-P-2.0. Software/configuration: Apache-2.0. Documentation and images: CC BY 4.0. See LICENSING.md, NOTICE and REUSE.toml for details.