## Description
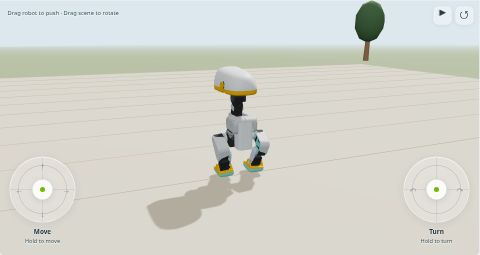
Add MicroDuck walking to the interactive gallery with native BAM servos
and the published Pollen Robotics policy from #8270. MicroDuck, G1, and
ANYmal share transparent viewport joysticks and compact pause/reset
controls. MicroDuck starts standing; drag its robot for a fixed 2 N push
and the background to orbit.
Pin the **v3 release archive and checksum**. This UI update reuses
unchanged v1/v2 physics, policies, and geometry. The docs workflow
downloads the bundle; it does not compile WASM. The PR changes four
files and adds no simulator binaries to Git.
[Play the
preview](https://maxkra15.github.io/isaaclab-browser-demos/v3/?demo=microduck)
· [Release
bundle](https://github.com/isaac-sim/IsaacLab/releases/tag/browser-demos-v3)
· [Exporter source
#7974](https://github.com/isaac-sim/IsaacLab/pull/7974)
## Release backport
- [x] <!-- backport-active-release --> Backport this pull request to the
active release branch after it merges into `develop`
## Validation
Clean documentation build with warnings as errors; full formatting;
released-archive checksum/staging; all 12 gallery links and thumbnails;
browser stepping, keyboard/mouse/touch controls, two simultaneous
joysticks, push/release/cancellation, pause/reset, mobile layout, and
simulation timing.