Releases: kevinzakka/mjbatch
Releases · kevinzakka/mjbatch
Release list
mjbatch 0.1.1

Track MuJoCo 3.13.0.
mjbatch 0.1.0
First release of mjbatch: a Python library for running thousands of MuJoCo simulations in parallel on CPU.
pip install mjbatch
- Steps N simulations on a C++ thread pool with the GIL released
- Live NumPy views of state and controls across the batch
- Per-simulation model parameters, with
set_constto recompute derived constants - Wheels for Linux (x86_64, aarch64) and macOS (arm64), Python 3.10–3.14 and free-threaded 3.14t; requires mujoco 3.11.0
See the examples for RL, MPC, iLQR, system identification and co-design:
 Go1 joystick, PPO |
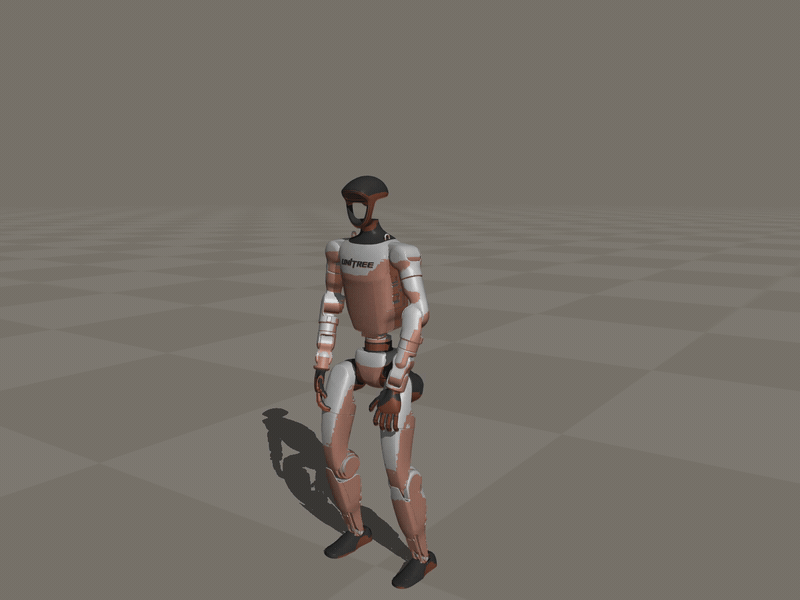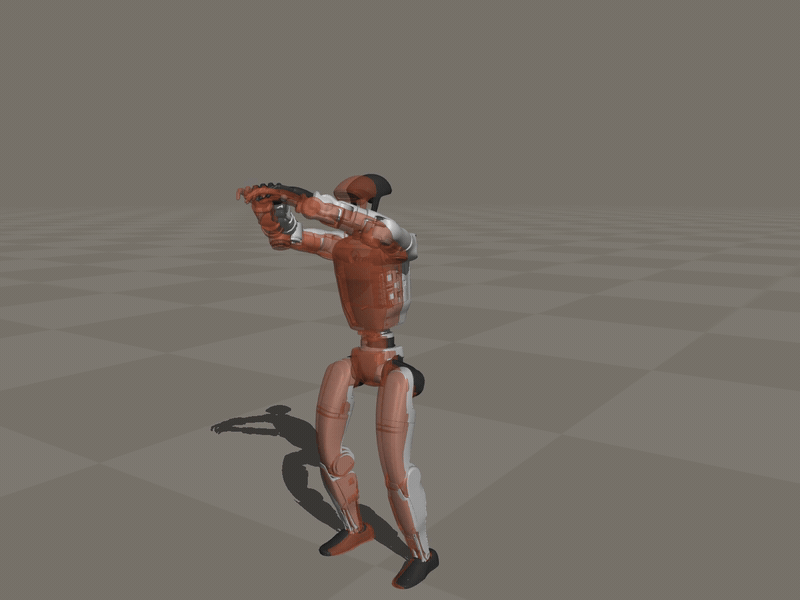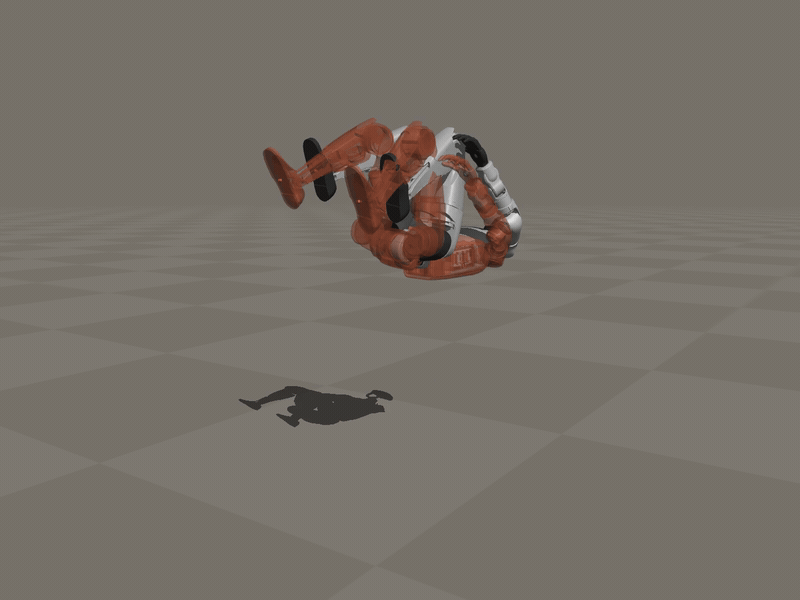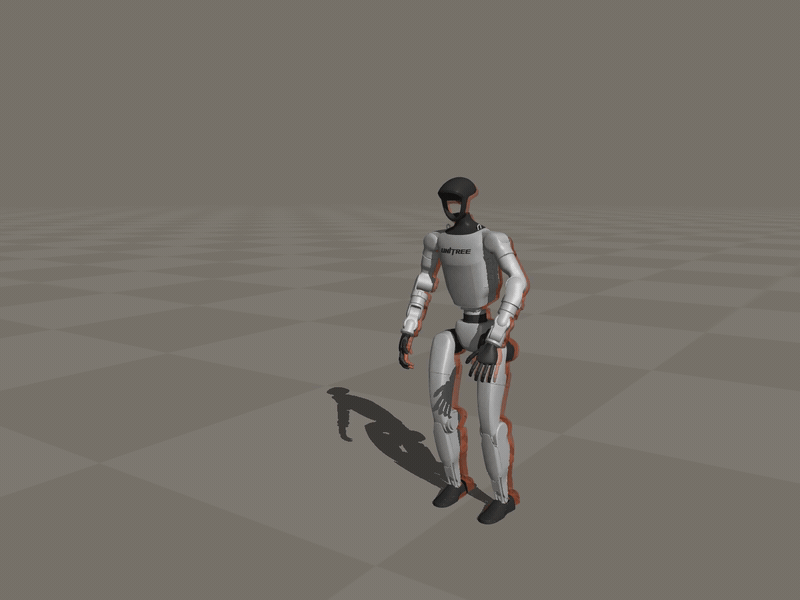 G1 backflip, iLQR |
 Two-pole swing-up, iLQR |
 Cart-pole, predictive sampling |
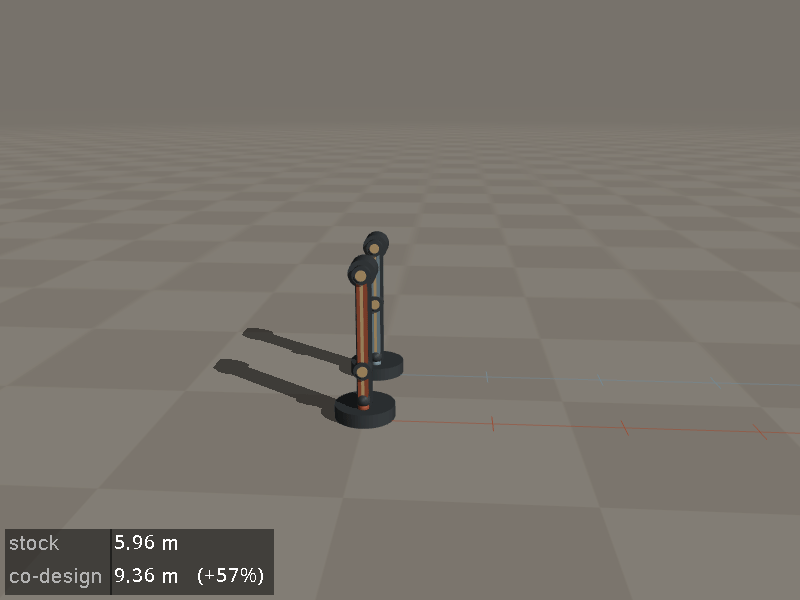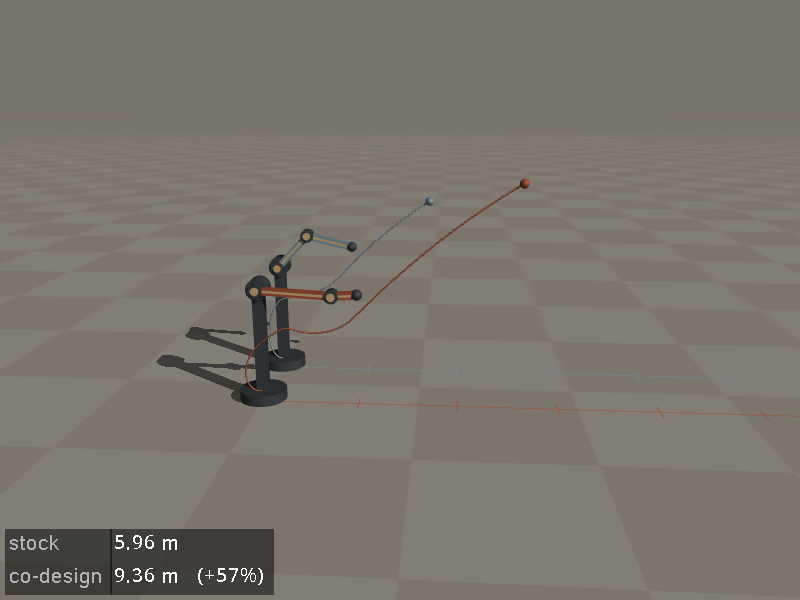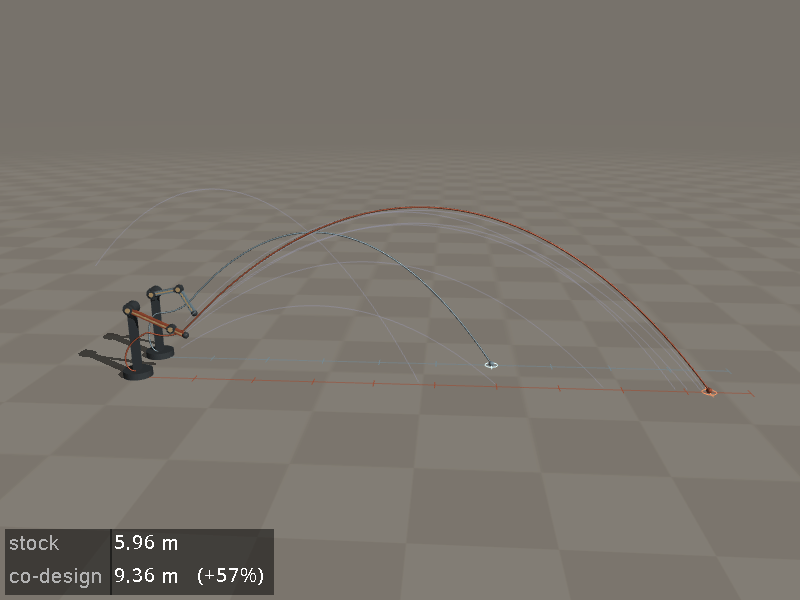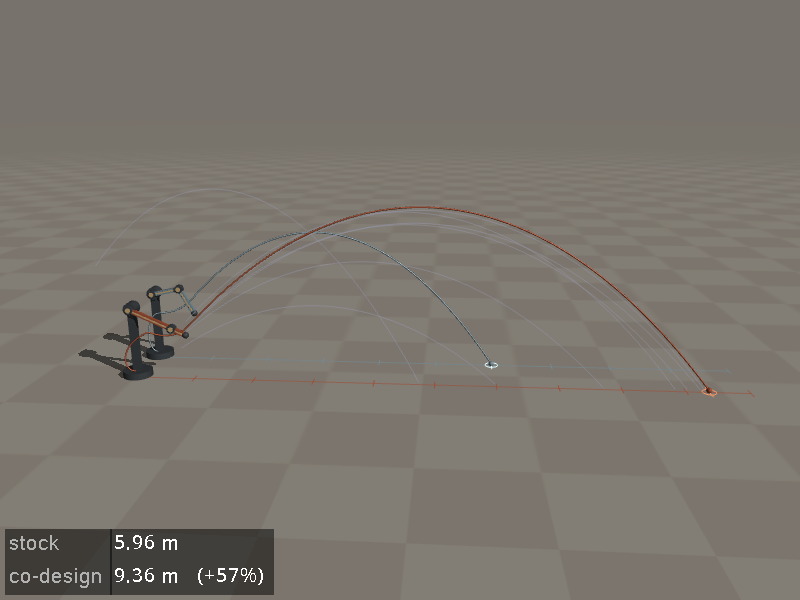 Throwing arm co-design, CEM |
 Rizon inertia sysid, Gauss–Newton |