Model Available
LOTUSim comes with a set of default platform models you can drop straight into a scenario. All models are in prototype stage; great for getting started and testing algorithms, but not yet fully validated for production use.
For full technical specs (hydrodynamics, ROS 2 topics, calibration data, etc.), see Model Specifications in the Developer Guide.
Type: Submarine · Modes: Visual + Dynamics
Underwater platform for algorithm testing. Driven via the waypoint follower or with its propeller via xdyn.

Type: Surface · Modes: Visual + Dynamics
Surface platform for algorithm testing. Driven via the waypoint follower or via xdyn.
Type: Surface · Modes: Visual + Dynamics
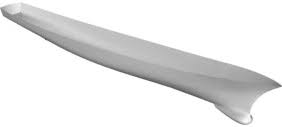
DTMB 5415 boat hull, driven by rudder + propeller commands. The most calibrated model available, based on published SIMMAN 2008 reference data.
Type: Surface · Modes: Visual + Dynamics
Demonstration-grade frigate model with propeller and rudder actuators, driven via the waypoint follower.

Type: Surface · Modes: Visual only
Demonstration model driven via the waypoint follower. No dynamics yet, visual representation only.

Type: Submarine · Modes: Visual + Dynamics
Long-Range AUV used in the Quick-start Example, the vehicle you'll see moving in your first scenario.

Type: Surface · Modes: Visual only
Demonstration model with propeller and rudder actuators, driven via the waypoint follower. No dynamics yet.
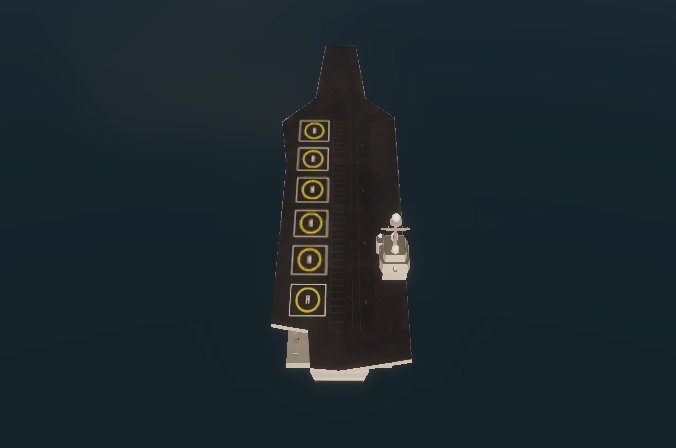
Type: Air · Modes: Visual only
