Repository navigation
Machine
This page is generated from the Unity twin. Published from
_docs/context/machine.md— edit it there, not here. Changes made in the wiki are overwritten on the next sync.
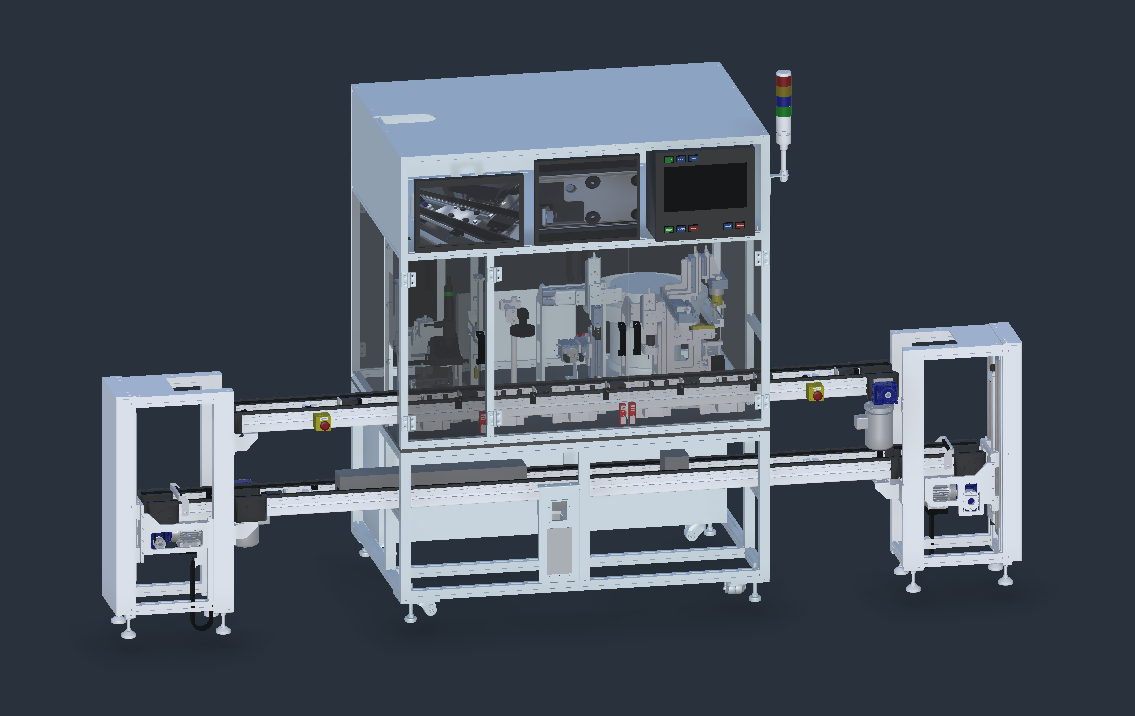
The line seen from the front - FG_System, FG_Transport and FG_01 to FG_05 assembled together.
Demo assembly line on a Bosch TS style two level pallet conveyor. Pallets carrying a two slot workpiece circulate through five processing groups on the upper level.
Lower level accumulates pallets and feeds them left to Lift 1, which raises each pallet to the upper level. Stoppers and sensors release one pallet at a time between FG_01 and FG_05. After FG_05 the pallet reaches Lift 2, which returns it to the lower conveyor where the part travels right and is destroyed.
Two conveyor levels. The lower accumulates and returns, the upper carries FG_01 to FG_05. Lift 1 raises pallets at one end, Lift 2 lowers them at the other. Each group has its own Index unit that stops and lifts the pallet.
| Group | Control PLC path | Symbols | Behaviour | Function |
|---|---|---|---|---|
| FG_System | MAIN.Machine.FG_System |
10 | contract | Cell infrastructure - safety enclosure, interlocked doors, operator panel, signal tower and monitors. |
| FG_Transport | MAIN.Machine.FG_Transport |
46 | contract | Two level pallet conveyor in the Bosch TS style. |
| FG_01 | MAIN.Machine.FG_01 |
9 | contract | Identifies the payload and applies a laser mark. |
| FG_02 | MAIN.Machine.FG_02 |
1 | contract | Optical inspection. |
| FG_03 | MAIN.Machine.FG_03 |
9 | contract | Transfers the part from slot 1 to slot 2 of the pallet, flipping it 180 degrees on the way. |
| FG_04 | MAIN.Machine.FG_04 |
2 | contract | Presses the part home into its slot and checks that it seated correctly. |
| FG_05 | MAIN.Machine.FG_05 |
10 | contract | Fits a cap from the bunker onto the part carried on the pallet. |
87 twin devices across 7 groups - see plc-symbols.md. Each group's page carries its own hierarchy, components and Unity detail, and links to the control implementation in each vendor module.
One machine, one prefab - Unity/Assets/Demo_1/Prefabs/Machine_1.prefab - instanced by every scene under Unity/Assets/Demo_1/Scenes/. Each scene adds its vendor's operator panel, and that is the only thing they disagree about.
| Scene | Vendor | Symbols | |
|---|---|---|---|
VC_Demo_1_Beckhoff_1 |
Beckhoff | 87 | reference for these pages |
VC_Demo_1_Siemens_1 |
Siemens | 87 |
15 node(s) differ and are marked † wherever they appear - all of them under an operator panel. Unmarked is the machine.
This repository is master for structure. Each vendor module is master for how that structure is realised in a control platform, and keeps its own knowledge base:
- Beckhoff (Beckhoff TwinCAT 3) — the machine in Beckhoff
- Siemens (Siemens TIA Portal) — DT_PSA_OPCV_Siemens, no knowledge base published yet
Every processing group is served by an Index unit in FG_Transport. The Index stops the pallet, lifts it to fix the payload, and only then asks the group to run; the pallet does not move until the group answers. The three invariants that coupling has to preserve, and the step chain that enforces them, are in transport-behaviour.md.
Scene wiring measured 2026-10-14T20:07:33Z from the live Editor, not inferred from naming.
Index01     -> Index02  -- serves FG_01
Index02     -> Index03  -- serves FG_02
Index03     -> Index04  -- serves FG_03
Index04     -> Index05  -- serves FG_04
Index05     -> Stopper04  -- serves FG_05
Stopper04   -> Lift02
Lift02      -> Stopper01  (lowers)
Stopper01   -> Stopper02
Stopper02   -> Lift01
Lift01      -> Stopper03  (raises)
Stopper03   -> Index01
11 stations in a closed ring - the last returns to the first.