Repository navigation
Machine FG_Transport
This page is generated from the Unity twin. Published from
_docs/context/fg-transport.md— edit it there, not here. Changes made in the wiki are overwritten on the next sync.
| Scene path | Project/FG_Transport |
| Twin PLC path | MAIN.FG_Transport |
| Served by | — |
| Symbols | 46 |
| Behaviour | transport-behaviour.md |
Two level pallet conveyor in the Bosch TS style. Circulates pallets past the five processing stations and returns them.
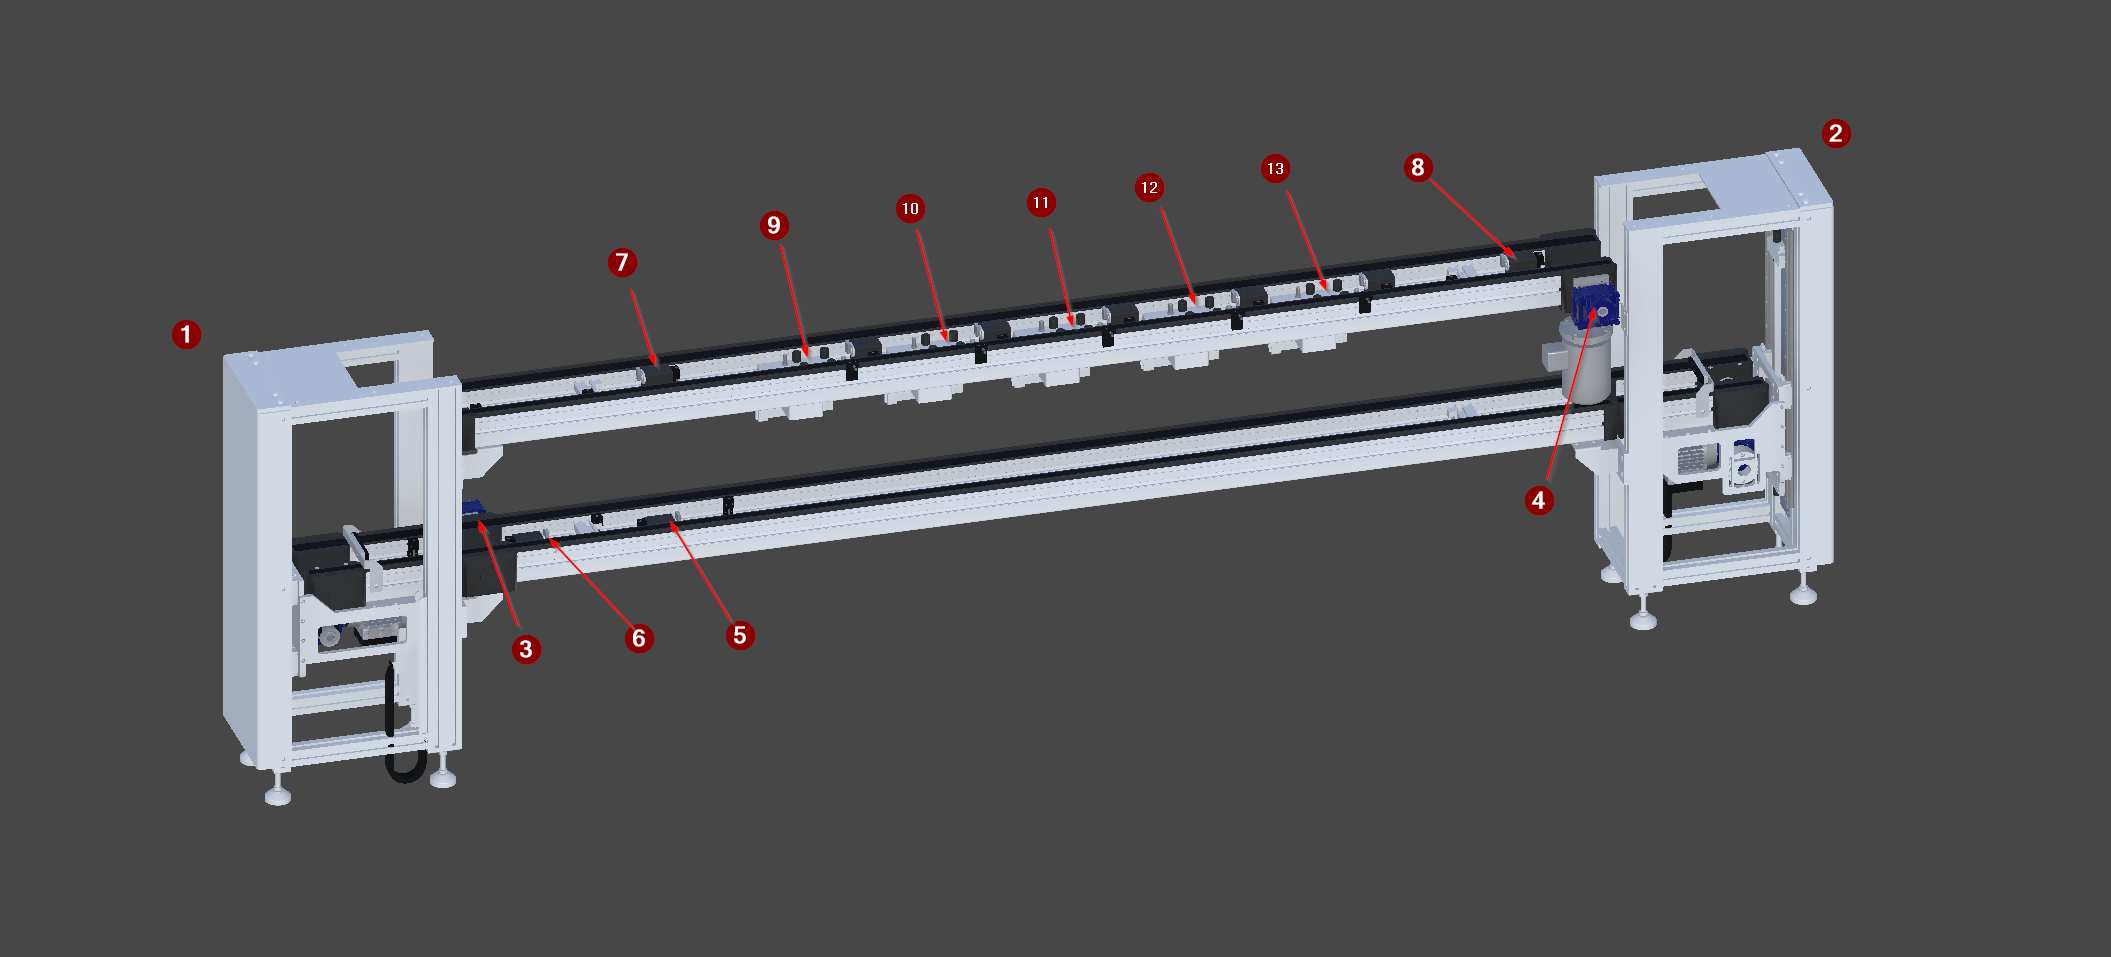
The two level pallet conveyor, isolated. Callouts name the transport modules; each module type has its own detail view below.
The numbered arrows name the station modules. Each has its own view below, and its devices are in the table further down.
1 Lift01 · 2 Lift02 · 3 Transport01/M_Conveyor · 4 Transport02/M_Conveyor · 5 Stopper01 · 6 Stopper02 · 7 Stopper03 · 8 Stopper04 · 9 Index01 · 10 Index02 · 11 Index03 · 12 Index04 · 13 Index05
Each module type below is a prefab instanced several times in this group. The figure is rendered from one instance and states which others it stands for - a claim the build checks, by comparing their devices.
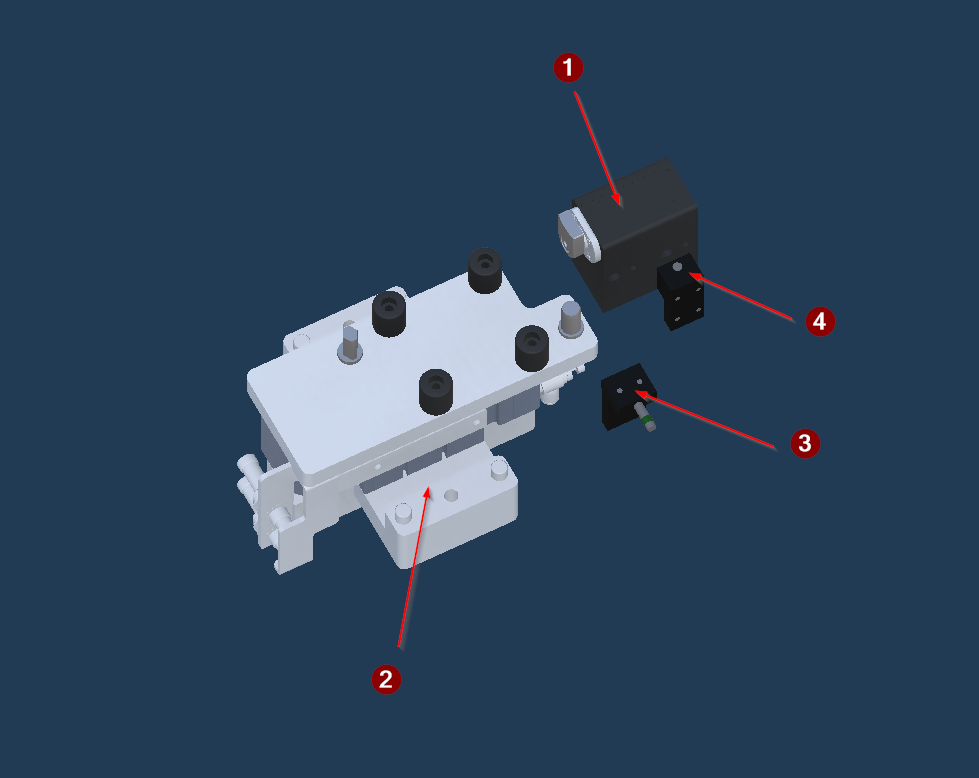
The index module, isolated. Stops a pallet and lifts it to fix the payload while its functional group runs.
Rendered from Index01. Stands for Index01, Index02, Index03, Index04, Index05. Its devices carry the callout number in the table below.
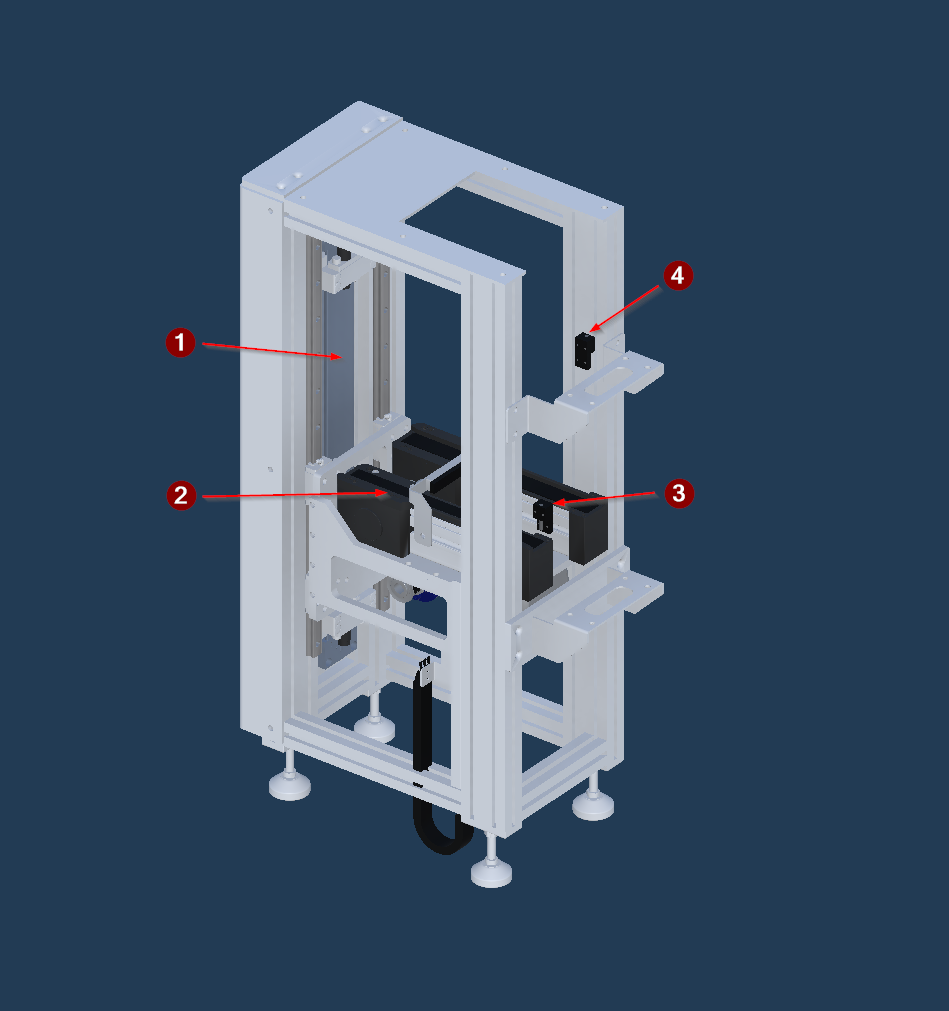
The lift module, isolated. Raises or lowers a pallet between the two conveyor levels and runs it off the carriage.
Rendered from Lift01. Stands for Lift01, Lift02. Its devices carry the callout number in the table below.
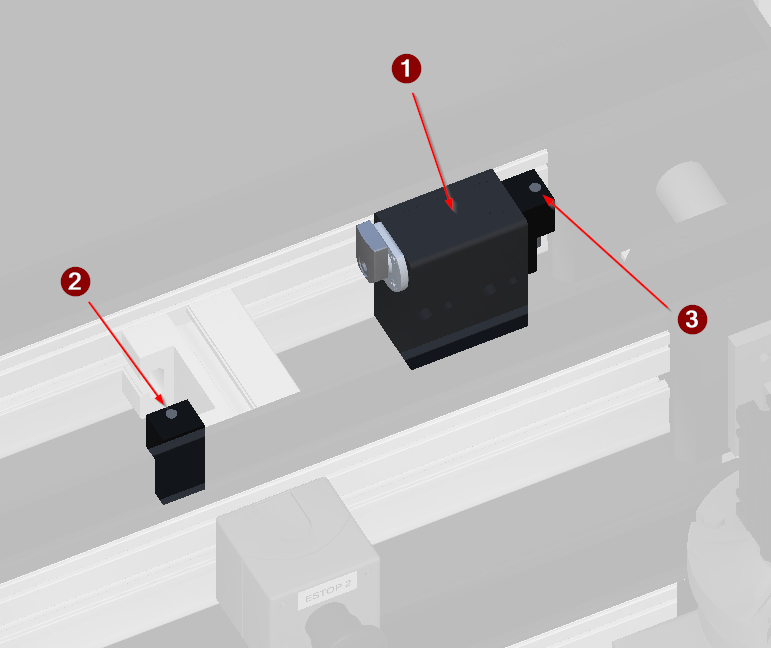
The stopper module, isolated. Holds and releases a pallet without lifting it.
Rendered from Stopper01. Stands for Stopper01, Stopper02, Stopper03, Stopper04. Its devices carry the callout number in the table below.
| # | Device | Type | Twin FB | Twin PLC path | What it does |
|---|---|---|---|---|---|
| 3 | B_Detect |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Index01_B_Detect |
Presence sensor at the stop position. Tells the unit a pallet has arrived and is ready to be indexed. |
| 4 | B_Exit |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Index01_B_Exit |
Exit sensor just past the stopper. Confirms the released pallet has actually left before the unit returns to idle. |
| 2 | Y_Lift |
Cylinder | FB_Cylinder |
MAIN.FG_Transport.Index01_Y_Lift |
Index lift cylinder. Raises the pallet off the conveyor to a repeatable position and fixes the payload while the station works on it. |
| 1 | Y_Stopper |
Cylinder | FB_Cylinder |
MAIN.FG_Transport.Index01_Y_Stopper |
Stopper cylinder. Retracted holds an incoming pallet at the station; extending releases it once the next station is free. |
| 3 | B_Detect |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Index02_B_Detect |
Presence sensor at the stop position. Tells the unit a pallet has arrived and is ready to be indexed. |
| 4 | B_Exit |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Index02_B_Exit |
Exit sensor just past the stopper. Confirms the released pallet has actually left before the unit returns to idle. |
| 2 | Y_Lift |
Cylinder | FB_Cylinder |
MAIN.FG_Transport.Index02_Y_Lift |
Index lift cylinder. Raises the pallet off the conveyor to a repeatable position and fixes the payload while the station works on it. |
| 1 | Y_Stopper |
Cylinder | FB_Cylinder |
MAIN.FG_Transport.Index02_Y_Stopper |
Stopper cylinder. Retracted holds an incoming pallet at the station; extending releases it once the next station is free. |
| 3 | B_Detect |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Index03_B_Detect |
Presence sensor at the stop position. Tells the unit a pallet has arrived and is ready to be indexed. |
| 4 | B_Exit |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Index03_B_Exit |
Exit sensor just past the stopper. Confirms the released pallet has actually left before the unit returns to idle. |
| 2 | Y_Lift |
Cylinder | FB_Cylinder |
MAIN.FG_Transport.Index03_Y_Lift |
Index lift cylinder. Raises the pallet off the conveyor to a repeatable position and fixes the payload while the station works on it. |
| 1 | Y_Stopper |
Cylinder | FB_Cylinder |
MAIN.FG_Transport.Index03_Y_Stopper |
Stopper cylinder. Retracted holds an incoming pallet at the station; extending releases it once the next station is free. |
| 3 | B_Detect |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Index04_B_Detect |
Presence sensor at the stop position. Tells the unit a pallet has arrived and is ready to be indexed. |
| 4 | B_Exit |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Index04_B_Exit |
Exit sensor just past the stopper. Confirms the released pallet has actually left before the unit returns to idle. |
| 2 | Y_Lift |
Cylinder | FB_Cylinder |
MAIN.FG_Transport.Index04_Y_Lift |
Index lift cylinder. Raises the pallet off the conveyor to a repeatable position and fixes the payload while the station works on it. |
| 1 | Y_Stopper |
Cylinder | FB_Cylinder |
MAIN.FG_Transport.Index04_Y_Stopper |
Stopper cylinder. Retracted holds an incoming pallet at the station; extending releases it once the next station is free. |
| 3 | B_Detect |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Index05_B_Detect |
Presence sensor at the stop position. Tells the unit a pallet has arrived and is ready to be indexed. |
| 4 | B_Exit |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Index05_B_Exit |
Exit sensor just past the stopper. Confirms the released pallet has actually left before the unit returns to idle. |
| 2 | Y_Lift |
Cylinder | FB_Cylinder |
MAIN.FG_Transport.Index05_Y_Lift |
Index lift cylinder. Raises the pallet off the conveyor to a repeatable position and fixes the payload while the station works on it. |
| 1 | Y_Stopper |
Cylinder | FB_Cylinder |
MAIN.FG_Transport.Index05_Y_Stopper |
Stopper cylinder. Retracted holds an incoming pallet at the station; extending releases it once the next station is free. |
| — | B_AxisMax |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Lift01_B_AxisMax |
Upper travel limit of the carriage. Made at the top of travel, above the upper conveyor level. |
| — | B_AxisMin |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Lift01_B_AxisMin |
Lower travel limit of the carriage and its homing reference. Made at the bottom of travel, below the lower conveyor level. |
| 3 | B_Detect |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Lift01_B_Detect |
Presence sensor on the lift carriage. Confirms a pallet is aboard before the carriage moves. |
| 4 | B_Exit |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Lift01_B_Exit |
Exit sensor on the lift. Confirms the pallet has transferred off the carriage. |
| 2 | M_Conveyor |
DriveSimple | FB_Drive |
MAIN.FG_Transport.Lift01_M_Conveyor |
Drive for the conveyor section on the lift carriage. |
| 1 | Y_Lift |
DrivePosition | FB_Sercos_VC |
MAIN.FG_Transport.Lift01_Y_Lift |
Lift servo drive. Positions the carriage between the lower and upper conveyor levels. |
| — | B_AxisMax |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Lift02_B_AxisMax |
Upper travel limit of the carriage. Made at the top of travel, above the upper conveyor level. |
| — | B_AxisMin |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Lift02_B_AxisMin |
Lower travel limit of the carriage and its homing reference. Made at the bottom of travel, below the lower conveyor level. |
| 3 | B_Detect |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Lift02_B_Detect |
Presence sensor on the lift carriage. Confirms a pallet is aboard before the carriage moves. |
| 4 | B_Exit |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Lift02_B_Exit |
Exit sensor on the lift. Confirms the pallet has transferred off the carriage. |
| 2 | M_Conveyor |
DriveSimple | FB_Drive |
MAIN.FG_Transport.Lift02_M_Conveyor |
Drive for the conveyor section on the lift carriage. |
| 1 | Y_Lift |
DrivePosition | FB_Sercos_VC |
MAIN.FG_Transport.Lift02_Y_Lift |
Lift servo drive. Positions the carriage between the lower and upper conveyor levels. |
| 2 | B_Detect |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Stopper01_B_Detect |
Presence sensor at the stop position. Tells the unit a pallet is waiting. |
| 3 | B_Exit |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Stopper01_B_Exit |
Exit sensor past the stopper. Confirms the released pallet has left before the unit accepts the next one. |
| 1 | Y_Stopper |
Cylinder | FB_Cylinder |
MAIN.FG_Transport.Stopper01_Y_Stopper |
Stopper cylinder. Retracted holds the pallet at this accumulation point; extending releases it when the next position is free. |
| 2 | B_Detect |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Stopper02_B_Detect |
Presence sensor at the stop position. Tells the unit a pallet is waiting. |
| 3 | B_Exit |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Stopper02_B_Exit |
Exit sensor past the stopper. Confirms the released pallet has left before the unit accepts the next one. |
| 1 | Y_Stopper |
Cylinder | FB_Cylinder |
MAIN.FG_Transport.Stopper02_Y_Stopper |
Stopper cylinder. Retracted holds the pallet at this accumulation point; extending releases it when the next position is free. |
| 2 | B_Detect |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Stopper03_B_Detect |
Presence sensor at the stop position. Tells the unit a pallet is waiting. |
| 3 | B_Exit |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Stopper03_B_Exit |
Exit sensor past the stopper. Confirms the released pallet has left before the unit accepts the next one. |
| 1 | Y_Stopper |
Cylinder | FB_Cylinder |
MAIN.FG_Transport.Stopper03_Y_Stopper |
Stopper cylinder. Retracted holds the pallet at this accumulation point; extending releases it when the next position is free. |
| 2 | B_Detect |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Stopper04_B_Detect |
Presence sensor at the stop position. Tells the unit a pallet is waiting. |
| 3 | B_Exit |
SensorBinary | FB_SensorBinary |
MAIN.FG_Transport.Stopper04_B_Exit |
Exit sensor past the stopper. Confirms the released pallet has left before the unit accepts the next one. |
| 1 | Y_Stopper |
Cylinder | FB_Cylinder |
MAIN.FG_Transport.Stopper04_Y_Stopper |
Stopper cylinder. Retracted holds the pallet at this accumulation point; extending releases it when the next position is free. |
| 3 | M_Conveyor |
DriveSimple | FB_Drive |
MAIN.FG_Transport.Transport01_M_Conveyor |
Conveyor drive for a straight transport section. Runs continuously while MIL is enabled. |
| 4 | M_Conveyor |
DriveSimple | FB_Drive |
MAIN.FG_Transport.Transport02_M_Conveyor |
Conveyor drive for a straight transport section. Runs continuously while MIL is enabled. |
# is the numbered arrow on the figure above.
The twin path is not the control path. A control platform spells these devices differently - it may fold a twin child into its parent unit, or address it from another root entirely - and only the control spelling works in a binding or a link, where the twin's fails silently. The verified control path for each row is on the vendor page linked below.
None.
The scene tree. The comment on each line is what the node is; † marks one that differs between scenes.
Transport01:       # grouping, not a device
  M_Conveyor:      # DriveSimple
  Surface:         # grouping, not a device
  Source:          # grouping, not a device
  Sink:            # grouping, not a device
Transport02:       # grouping, not a device
  M_Conveyor:      # DriveSimple
  Surface:         # grouping, not a device
Lift01:            # grouping, not a device
  Y_Lift:          # DrivePosition
  Axis_Lift:       # grouping, not a device
    TU_Linear:     # grouping, not a device
      M_Conveyor:  # DriveSimple
      Surface:     # grouping, not a device
    B_Detect:      # SensorBinary
  B_Exit:          # SensorBinary
  B_AxisMin:       # SensorBinary
  B_AxisMax:       # SensorBinary
Lift02:            # grouping, not a device
  Y_Lift:          # DrivePosition
  Axis_Lift:       # grouping, not a device
    TU_Linear:     # grouping, not a device
      M_Conveyor:  # DriveSimple
      Surface:     # grouping, not a device
    B_Detect:      # SensorBinary
  B_Exit:          # SensorBinary
  B_AxisMin:       # SensorBinary
  B_AxisMax:       # SensorBinary
Index01:           # grouping, not a device
  Y_Stopper:       # Cylinder
    Axis:          # grouping, not a device
  Y_Lift:          # Cylinder
  Axis:            # grouping, not a device
    Surface:       # grouping, not a device
  B_Detect:        # SensorBinary
  B_Exit:          # SensorBinary
Index02:           # grouping, not a device
  Y_Stopper:       # Cylinder
    Axis:          # grouping, not a device
  Y_Lift:          # Cylinder
  Axis:            # grouping, not a device
    Surface:       # grouping, not a device
  B_Detect:        # SensorBinary
  B_Exit:          # SensorBinary
Index03:           # grouping, not a device
  Y_Stopper:       # Cylinder
    Axis:          # grouping, not a device
  Y_Lift:          # Cylinder
  Axis:            # grouping, not a device
    Surface:       # grouping, not a device
  B_Detect:        # SensorBinary
  B_Exit:          # SensorBinary
Index04:           # grouping, not a device
  Y_Stopper:       # Cylinder
    Axis:          # grouping, not a device
  Y_Lift:          # Cylinder
  Axis:            # grouping, not a device
    Surface:       # grouping, not a device
  B_Detect:        # SensorBinary
  B_Exit:          # SensorBinary
Index05:           # grouping, not a device
  Y_Stopper:       # Cylinder
    Axis:          # grouping, not a device
  Y_Lift:          # Cylinder
  Axis:            # grouping, not a device
    Surface:       # grouping, not a device
  B_Detect:        # SensorBinary
  B_Exit:          # SensorBinary
Stopper01:         # grouping, not a device
  Y_Stopper:       # Cylinder
    Axis:          # grouping, not a device
  B_Detect:        # SensorBinary
  B_Exit:          # SensorBinary
Stopper02:         # grouping, not a device
  Y_Stopper:       # Cylinder
    Axis:          # grouping, not a device
  B_Detect:        # SensorBinary
  B_Exit:          # SensorBinary
Stopper03:         # grouping, not a device
  Y_Stopper:       # Cylinder
    Axis:          # grouping, not a device
  B_Detect:        # SensorBinary
  B_Exit:          # SensorBinary
Stopper04:         # grouping, not a device
  Y_Stopper:       # Cylinder
    Axis:          # grouping, not a device
  B_Detect:        # SensorBinary
B_Exit: # SensorBinaryTwin animation: SequenceConveyor.cs — behaviour contract is in transport-behaviour.md
Transport01 — MAIN.FG_Transport.Transport01 · not a PLC symbol
- Function — Straight conveyor section carrying pallets between transfer points.
- Role — Upper level conveyor section.
M_Conveyor — MAIN.FG_Transport.Transport01_M_Conveyor · DriveSimple
- Signal — Simple drive: forward and backward run bits out, one drive-active bit back. No speed reference and no encoder.
Surface — `` · not a PLC symbol
- Function — The driven belt surface of a straight conveyor section.
- Twin — TransportLinear on a Rigidbody, from TU Linear Typ 1. Moves any rigidbody resting on it by surface velocity.
- Approximation — No friction, no slip and no accumulation pressure. A pallet held by a stopper simply stops while the surface keeps commanding motion.
Source — `` · not a PLC symbol
- Function — Spawns the pallets that circulate through the machine.
- Twin — OC Source (a Detector) with Create() / Delete(), carrying _typeId and _uniqueId. The UniqueId it stamps is what FG_01's camera later reads back as the serial number.
- Approximation — Pallets appear from nothing on the source's own schedule. There is no upstream machine, no infeed sensor and nothing the PLC can command here.
Sink — `` · not a PLC symbol
- Function — Destroys pallets at the end of the return run, closing the circulation.
- Twin — OC Sink (a Detector) with Delete(). Removes any payload that reaches it.
- Approximation — Parts are destroyed rather than unloaded, so nothing downstream of FG_05 is modelled and no PLC signal marks a finished part leaving the cell.
Transport02 — MAIN.FG_Transport.Transport02 · not a PLC symbol
- Function — Straight conveyor section carrying pallets between transfer points.
- Role — Lower level return conveyor section.
M_Conveyor — MAIN.FG_Transport.Transport02_M_Conveyor · DriveSimple
- Signal — Simple drive: forward and backward run bits out, one drive-active bit back. No speed reference and no encoder.
Surface — `` · not a PLC symbol
- Function — The driven belt surface of a straight conveyor section.
- Twin — TransportLinear on a Rigidbody, from TU Linear Typ 1. Moves any rigidbody resting on it by surface velocity.
- Approximation — No friction, no slip and no accumulation pressure. A pallet held by a stopper simply stops while the surface keeps commanding motion.
Lift01 — MAIN.FG_Transport.Lift01 · not a PLC symbol
- Function — Vertical transfer between the two conveyor levels. Takes a pallet on its own short conveyor, moves it to the other level and hands it on.
- Role — Lift 1. Raises pallets from the lower accumulation level to the upper processing level, feeding Index01.
Y_Lift — MAIN.FG_Transport.Lift01_Y_Lift · DrivePosition
- Signal — Position-controlled. Referenced on B_AxisMin, which reads 0 mm; the lower conveyor level is at 10 mm and the upper at 364 mm.
Axis_Lift — MAIN.FG_Transport.Lift01_Axis_Lift · not a PLC symbol
- Function — Kinematic axis of the lift carriage, driven by Y_Lift.
TU_Linear — MAIN.FG_Transport.Lift01_TU_Linear · not a PLC symbol
- Function — Short conveyor section mounted on the lift carriage, used to draw a pallet on and push it off.
M_Conveyor — MAIN.FG_Transport.Lift01_M_Conveyor · DriveSimple
- Signal — Simple drive: forward and backward run bits out, one drive-active bit back. No speed reference and no encoder.
Surface — `` · not a PLC symbol
- Function — The lift carriage's own short belt, which draws a pallet aboard and pushes it off again.
- Twin — TransportLinear on a Rigidbody, from TU Linear Typ 2. Reversible - backward draws a pallet in, forward pushes it out.
- Caution — The belt may only run while the carriage is AT a level. Between levels it drives the pallet into a fixed edge; the PLC enforces this in CyclicLogic for every state and mode.
B_Detect — MAIN.FG_Transport.Lift01_B_Detect · SensorBinary
- Signal — Binary presence sensor. Active while a pallet is at this station. Occupied and CanAccept are computed from it.
B_Exit — MAIN.FG_Transport.Lift01_B_Exit · SensorBinary
- Signal — Binary presence sensor. Its RISING EDGE clears the transfer latch, in every PackML state. Read the edge, never the level.
B_AxisMin — MAIN.FG_Transport.Lift01_B_AxisMin · SensorBinary
- Signal — Travel limit: while made, motion further down is blocked. Referencing sets the axis position here to 0 mm.
B_AxisMax — MAIN.FG_Transport.Lift01_B_AxisMax · SensorBinary
- Signal — Travel limit: while made, motion further up is blocked.
Lift02 — MAIN.FG_Transport.Lift02 · not a PLC symbol
- Function — Vertical transfer between the two conveyor levels. Takes a pallet on its own short conveyor, moves it to the other level and hands it on.
- Role — Lift 2. Lowers pallets from the upper level after FG_05 onto the return conveyor.
Y_Lift — MAIN.FG_Transport.Lift02_Y_Lift · DrivePosition
- Signal — Position-controlled. Referenced on B_AxisMin, which reads 0 mm; the lower conveyor level is at 10 mm and the upper at 364 mm.
Axis_Lift — MAIN.FG_Transport.Lift02_Axis_Lift · not a PLC symbol
- Function — Kinematic axis of the lift carriage, driven by Y_Lift.
TU_Linear — MAIN.FG_Transport.Lift02_TU_Linear · not a PLC symbol
- Function — Short conveyor section mounted on the lift carriage, used to draw a pallet on and push it off.
M_Conveyor — MAIN.FG_Transport.Lift02_M_Conveyor · DriveSimple
- Signal — Simple drive: forward and backward run bits out, one drive-active bit back. No speed reference and no encoder.
Surface — `` · not a PLC symbol
- Function — The lift carriage's own short belt, which draws a pallet aboard and pushes it off again.
- Twin — TransportLinear on a Rigidbody, from TU Linear Typ 2. Reversible - backward draws a pallet in, forward pushes it out.
- Caution — The belt may only run while the carriage is AT a level. Between levels it drives the pallet into a fixed edge; the PLC enforces this in CyclicLogic for every state and mode.
B_Detect — MAIN.FG_Transport.Lift02_B_Detect · SensorBinary
- Signal — Binary presence sensor. Active while a pallet is at this station. Occupied and CanAccept are computed from it.
B_Exit — MAIN.FG_Transport.Lift02_B_Exit · SensorBinary
- Signal — Binary presence sensor. Its RISING EDGE clears the transfer latch, in every PackML state. Read the edge, never the level.
B_AxisMin — MAIN.FG_Transport.Lift02_B_AxisMin · SensorBinary
- Signal — Travel limit: while made, motion further down is blocked. Referencing sets the axis position here to 0 mm.
B_AxisMax — MAIN.FG_Transport.Lift02_B_AxisMax · SensorBinary
- Signal — Travel limit: while made, motion further up is blocked.
Index01 — MAIN.FG_Transport.Index01 · not a PLC symbol
- Function — Pallet index station. Stops an incoming pallet, lifts it to a stable position to fix the payload, triggers the functional group it serves, then releases the pallet to the next station.
- Role — Serves FG_01, the barcode read and laser marking station. Releases to Index02.
Y_Stopper — MAIN.FG_Transport.Index01_Y_Stopper · Cylinder
- Signal — Double solenoid with both limits read. RETRACTED (min) holds the pallet; EXTENDING (max) releases it - the blade drops out of the way.
Axis — `` · not a PLC symbol
- Function — Kinematic axis that raises and lowers the stopper blade.
- Twin — OC Axis on the TS Stopper Typ 1 prefab. Cylinder._limits {0, 20} and axis _factor -0.001, so the cylinder's MAX limit puts the blade DOWN and min puts it UP.
- Caution — RETRACTED (min, blade up) HOLDS THE PALLET; EXTENDING (max, blade down) RELEASES IT. The opposite sense to the FG_01 guard gates. Nine authored entries once had this backwards.
Y_Lift — MAIN.FG_Transport.Index01_Y_Lift · Cylinder
- Signal — Double solenoid with both limits read. EXTENDED raises the carriage and fixes the pallet clear of the belt; retracted is home.
Axis — `` · not a PLC symbol
- Function — Kinematic axis that lifts the whole index carriage, fixing the pallet clear of the conveyor for the station to work on.
- Twin — OC Axis on the TS Index Unit prefab, carrying the Surface below it.
Surface — `` · not a PLC symbol
- Function — The driven belt surface of an index unit - what a pallet actually rides on.
- Twin — TransportLinear on a Rigidbody. Moves any rigidbody resting on it by surface velocity; it is not a physics conveyor and applies no friction model.
B_Detect — MAIN.FG_Transport.Index01_B_Detect · SensorBinary
- Signal — Binary presence sensor. Active while a pallet is at this station. Occupied and CanAccept are computed from it.
B_Exit — MAIN.FG_Transport.Index01_B_Exit · SensorBinary
- Signal — Binary presence sensor. Its RISING EDGE clears the transfer latch, in every PackML state. Read the edge, never the level.
Index02 — MAIN.FG_Transport.Index02 · not a PLC symbol
- Function — Pallet index station. Stops an incoming pallet, lifts it to a stable position to fix the payload, triggers the functional group it serves, then releases the pallet to the next station.
- Role — Serves FG_02, the optical inspection station. Releases to Index03.
Y_Stopper — MAIN.FG_Transport.Index02_Y_Stopper · Cylinder
- Signal — Double solenoid with both limits read. RETRACTED (min) holds the pallet; EXTENDING (max) releases it - the blade drops out of the way.
Axis — `` · not a PLC symbol
- Function — Kinematic axis that raises and lowers the stopper blade.
- Twin — OC Axis on the TS Stopper Typ 1 prefab. Cylinder._limits {0, 20} and axis _factor -0.001, so the cylinder's MAX limit puts the blade DOWN and min puts it UP.
- Caution — RETRACTED (min, blade up) HOLDS THE PALLET; EXTENDING (max, blade down) RELEASES IT. The opposite sense to the FG_01 guard gates. Nine authored entries once had this backwards.
Y_Lift — MAIN.FG_Transport.Index02_Y_Lift · Cylinder
- Signal — Double solenoid with both limits read. EXTENDED raises the carriage and fixes the pallet clear of the belt; retracted is home.
Axis — `` · not a PLC symbol
- Function — Kinematic axis that lifts the whole index carriage, fixing the pallet clear of the conveyor for the station to work on.
- Twin — OC Axis on the TS Index Unit prefab, carrying the Surface below it.
Surface — `` · not a PLC symbol
- Function — The driven belt surface of an index unit - what a pallet actually rides on.
- Twin — TransportLinear on a Rigidbody. Moves any rigidbody resting on it by surface velocity; it is not a physics conveyor and applies no friction model.
B_Detect — MAIN.FG_Transport.Index02_B_Detect · SensorBinary
- Signal — Binary presence sensor. Active while a pallet is at this station. Occupied and CanAccept are computed from it.
B_Exit — MAIN.FG_Transport.Index02_B_Exit · SensorBinary
- Signal — Binary presence sensor. Its RISING EDGE clears the transfer latch, in every PackML state. Read the edge, never the level.
Index03 — MAIN.FG_Transport.Index03 · not a PLC symbol
- Function — Pallet index station. Stops an incoming pallet, lifts it to a stable position to fix the payload, triggers the functional group it serves, then releases the pallet to the next station.
- Role — Serves FG_03, the slot 1 to slot 2 transfer station. Releases to Index04.
Y_Stopper — MAIN.FG_Transport.Index03_Y_Stopper · Cylinder
- Signal — Double solenoid with both limits read. RETRACTED (min) holds the pallet; EXTENDING (max) releases it - the blade drops out of the way.
Axis — `` · not a PLC symbol
- Function — Kinematic axis that raises and lowers the stopper blade.
- Twin — OC Axis on the TS Stopper Typ 1 prefab. Cylinder._limits {0, 20} and axis _factor -0.001, so the cylinder's MAX limit puts the blade DOWN and min puts it UP.
- Caution — RETRACTED (min, blade up) HOLDS THE PALLET; EXTENDING (max, blade down) RELEASES IT. The opposite sense to the FG_01 guard gates. Nine authored entries once had this backwards.
Y_Lift — MAIN.FG_Transport.Index03_Y_Lift · Cylinder
- Signal — Double solenoid with both limits read. EXTENDED raises the carriage and fixes the pallet clear of the belt; retracted is home.
Axis — `` · not a PLC symbol
- Function — Kinematic axis that lifts the whole index carriage, fixing the pallet clear of the conveyor for the station to work on.
- Twin — OC Axis on the TS Index Unit prefab, carrying the Surface below it.
Surface — `` · not a PLC symbol
- Function — The driven belt surface of an index unit - what a pallet actually rides on.
- Twin — TransportLinear on a Rigidbody. Moves any rigidbody resting on it by surface velocity; it is not a physics conveyor and applies no friction model.
B_Detect — MAIN.FG_Transport.Index03_B_Detect · SensorBinary
- Signal — Binary presence sensor. Active while a pallet is at this station. Occupied and CanAccept are computed from it.
B_Exit — MAIN.FG_Transport.Index03_B_Exit · SensorBinary
- Signal — Binary presence sensor. Its RISING EDGE clears the transfer latch, in every PackML state. Read the edge, never the level.
Index04 — MAIN.FG_Transport.Index04 · not a PLC symbol
- Function — Pallet index station. Stops an incoming pallet, lifts it to a stable position to fix the payload, triggers the functional group it serves, then releases the pallet to the next station.
- Role — Serves FG_04, the press station. Releases to Index05.
Y_Stopper — MAIN.FG_Transport.Index04_Y_Stopper · Cylinder
- Signal — Double solenoid with both limits read. RETRACTED (min) holds the pallet; EXTENDING (max) releases it - the blade drops out of the way.
Axis — `` · not a PLC symbol
- Function — Kinematic axis that raises and lowers the stopper blade.
- Twin — OC Axis on the TS Stopper Typ 1 prefab. Cylinder._limits {0, 20} and axis _factor -0.001, so the cylinder's MAX limit puts the blade DOWN and min puts it UP.
- Caution — RETRACTED (min, blade up) HOLDS THE PALLET; EXTENDING (max, blade down) RELEASES IT. The opposite sense to the FG_01 guard gates. Nine authored entries once had this backwards.
Y_Lift — MAIN.FG_Transport.Index04_Y_Lift · Cylinder
- Signal — Double solenoid with both limits read. EXTENDED raises the carriage and fixes the pallet clear of the belt; retracted is home.
Axis — `` · not a PLC symbol
- Function — Kinematic axis that lifts the whole index carriage, fixing the pallet clear of the conveyor for the station to work on.
- Twin — OC Axis on the TS Index Unit prefab, carrying the Surface below it.
Surface — `` · not a PLC symbol
- Function — The driven belt surface of an index unit - what a pallet actually rides on.
- Twin — TransportLinear on a Rigidbody. Moves any rigidbody resting on it by surface velocity; it is not a physics conveyor and applies no friction model.
B_Detect — MAIN.FG_Transport.Index04_B_Detect · SensorBinary
- Signal — Binary presence sensor. Active while a pallet is at this station. Occupied and CanAccept are computed from it.
B_Exit — MAIN.FG_Transport.Index04_B_Exit · SensorBinary
- Signal — Binary presence sensor. Its RISING EDGE clears the transfer latch, in every PackML state. Read the edge, never the level.
Index05 — MAIN.FG_Transport.Index05 · not a PLC symbol
- Function — Pallet index station. Stops an incoming pallet, lifts it to a stable position to fix the payload, triggers the functional group it serves, then releases the pallet to the next station.
- Role — Serves FG_05, the capping station. Last station on the upper level - releases towards Lift 2.
Y_Stopper — MAIN.FG_Transport.Index05_Y_Stopper · Cylinder
- Signal — Double solenoid with both limits read. RETRACTED (min) holds the pallet; EXTENDING (max) releases it - the blade drops out of the way.
Axis — `` · not a PLC symbol
- Function — Kinematic axis that raises and lowers the stopper blade.
- Twin — OC Axis on the TS Stopper Typ 1 prefab. Cylinder._limits {0, 20} and axis _factor -0.001, so the cylinder's MAX limit puts the blade DOWN and min puts it UP.
- Caution — RETRACTED (min, blade up) HOLDS THE PALLET; EXTENDING (max, blade down) RELEASES IT. The opposite sense to the FG_01 guard gates. Nine authored entries once had this backwards.
Y_Lift — MAIN.FG_Transport.Index05_Y_Lift · Cylinder
- Signal — Double solenoid with both limits read. EXTENDED raises the carriage and fixes the pallet clear of the belt; retracted is home.
Axis — `` · not a PLC symbol
- Function — Kinematic axis that lifts the whole index carriage, fixing the pallet clear of the conveyor for the station to work on.
- Twin — OC Axis on the TS Index Unit prefab, carrying the Surface below it.
Surface — `` · not a PLC symbol
- Function — The driven belt surface of an index unit - what a pallet actually rides on.
- Twin — TransportLinear on a Rigidbody. Moves any rigidbody resting on it by surface velocity; it is not a physics conveyor and applies no friction model.
B_Detect — MAIN.FG_Transport.Index05_B_Detect · SensorBinary
- Signal — Binary presence sensor. Active while a pallet is at this station. Occupied and CanAccept are computed from it.
B_Exit — MAIN.FG_Transport.Index05_B_Exit · SensorBinary
- Signal — Binary presence sensor. Its RISING EDGE clears the transfer latch, in every PackML state. Read the edge, never the level.
Stopper01 — MAIN.FG_Transport.Stopper01 · not a PLC symbol
- Function — Accumulation stopper between stations. Holds one pallet and releases it only when the next station is free, so a single pallet travels from stopper to stopper.
Y_Stopper — MAIN.FG_Transport.Stopper01_Y_Stopper · Cylinder
- Signal — Double solenoid with both limits read. RETRACTED (min) holds the pallet; EXTENDING (max) releases it - the blade drops out of the way.
Axis — `` · not a PLC symbol
- Function — Kinematic axis that raises and lowers the stopper blade.
- Twin — OC Axis on the TS Stopper Typ 1 prefab. Cylinder._limits {0, 20} and axis _factor -0.001, so the cylinder's MAX limit puts the blade DOWN and min puts it UP.
- Caution — RETRACTED (min, blade up) HOLDS THE PALLET; EXTENDING (max, blade down) RELEASES IT. The opposite sense to the FG_01 guard gates.
B_Detect — MAIN.FG_Transport.Stopper01_B_Detect · SensorBinary
- Signal — Binary presence sensor. Active while a pallet is at this station. Occupied and CanAccept are computed from it.
B_Exit — MAIN.FG_Transport.Stopper01_B_Exit · SensorBinary
- Signal — Binary presence sensor. Its RISING EDGE clears the transfer latch, in every PackML state. Read the edge, never the level.
Stopper02 — MAIN.FG_Transport.Stopper02 · not a PLC symbol
- Function — Accumulation stopper between stations. Holds one pallet and releases it only when the next station is free, so a single pallet travels from stopper to stopper.
Y_Stopper — MAIN.FG_Transport.Stopper02_Y_Stopper · Cylinder
- Signal — Double solenoid with both limits read. RETRACTED (min) holds the pallet; EXTENDING (max) releases it - the blade drops out of the way.
Axis — `` · not a PLC symbol
- Function — Kinematic axis that raises and lowers the stopper blade.
- Twin — OC Axis on the TS Stopper Typ 1 prefab. Cylinder._limits {0, 20} and axis _factor -0.001, so the cylinder's MAX limit puts the blade DOWN and min puts it UP.
- Caution — RETRACTED (min, blade up) HOLDS THE PALLET; EXTENDING (max, blade down) RELEASES IT. The opposite sense to the FG_01 guard gates.
B_Detect — MAIN.FG_Transport.Stopper02_B_Detect · SensorBinary
- Signal — Binary presence sensor. Active while a pallet is at this station. Occupied and CanAccept are computed from it.
B_Exit — MAIN.FG_Transport.Stopper02_B_Exit · SensorBinary
- Signal — Binary presence sensor. Its RISING EDGE clears the transfer latch, in every PackML state. Read the edge, never the level.
Stopper03 — MAIN.FG_Transport.Stopper03 · not a PLC symbol
- Function — Accumulation stopper between stations. Holds one pallet and releases it only when the next station is free, so a single pallet travels from stopper to stopper.
Y_Stopper — MAIN.FG_Transport.Stopper03_Y_Stopper · Cylinder
- Signal — Double solenoid with both limits read. RETRACTED (min) holds the pallet; EXTENDING (max) releases it - the blade drops out of the way.
Axis — `` · not a PLC symbol
- Function — Kinematic axis that raises and lowers the stopper blade.
- Twin — OC Axis on the TS Stopper Typ 1 prefab. Cylinder._limits {0, 20} and axis _factor -0.001, so the cylinder's MAX limit puts the blade DOWN and min puts it UP.
- Caution — RETRACTED (min, blade up) HOLDS THE PALLET; EXTENDING (max, blade down) RELEASES IT. The opposite sense to the FG_01 guard gates.
B_Detect — MAIN.FG_Transport.Stopper03_B_Detect · SensorBinary
- Signal — Binary presence sensor. Active while a pallet is at this station. Occupied and CanAccept are computed from it.
B_Exit — MAIN.FG_Transport.Stopper03_B_Exit · SensorBinary
- Signal — Binary presence sensor. Its RISING EDGE clears the transfer latch, in every PackML state. Read the edge, never the level.
Stopper04 — MAIN.FG_Transport.Stopper04 · not a PLC symbol
- Function — Accumulation stopper between stations. Holds one pallet and releases it only when the next station is free, so a single pallet travels from stopper to stopper.
Y_Stopper — MAIN.FG_Transport.Stopper04_Y_Stopper · Cylinder
- Signal — Double solenoid with both limits read. RETRACTED (min) holds the pallet; EXTENDING (max) releases it - the blade drops out of the way.
Axis — `` · not a PLC symbol
- Function — Kinematic axis that raises and lowers the stopper blade.
- Twin — OC Axis on the TS Stopper Typ 1 prefab. Cylinder._limits {0, 20} and axis _factor -0.001, so the cylinder's MAX limit puts the blade DOWN and min puts it UP.
- Caution — RETRACTED (min, blade up) HOLDS THE PALLET; EXTENDING (max, blade down) RELEASES IT. The opposite sense to the FG_01 guard gates.
B_Detect — MAIN.FG_Transport.Stopper04_B_Detect · SensorBinary
- Signal — Binary presence sensor. Active while a pallet is at this station. Occupied and CanAccept are computed from it.
B_Exit — MAIN.FG_Transport.Stopper04_B_Exit · SensorBinary
- Signal — Binary presence sensor. Its RISING EDGE clears the transfer latch, in every PackML state. Read the edge, never the level.
The twin is master for structure, and that is all this page states. The control module, the twin device layer, the verified control PLC paths and the terminal mapping is the control platform's own knowledge base:
- Beckhoff
- Siemens — no knowledge base published yet