Repository navigation
Machine FG_04
This page is generated from the Unity twin. Published from
_docs/context/fg-04.md— edit it there, not here. Changes made in the wiki are overwritten on the next sync.
| Scene path | Project/FG_04 |
| Twin PLC path | MAIN.FG_04 |
| Served by |
Index04 (FG_Transport) |
| Symbols | 2 |
| Behaviour | fg-04-behaviour.md |
Presses the part home into its slot and checks that it seated correctly.
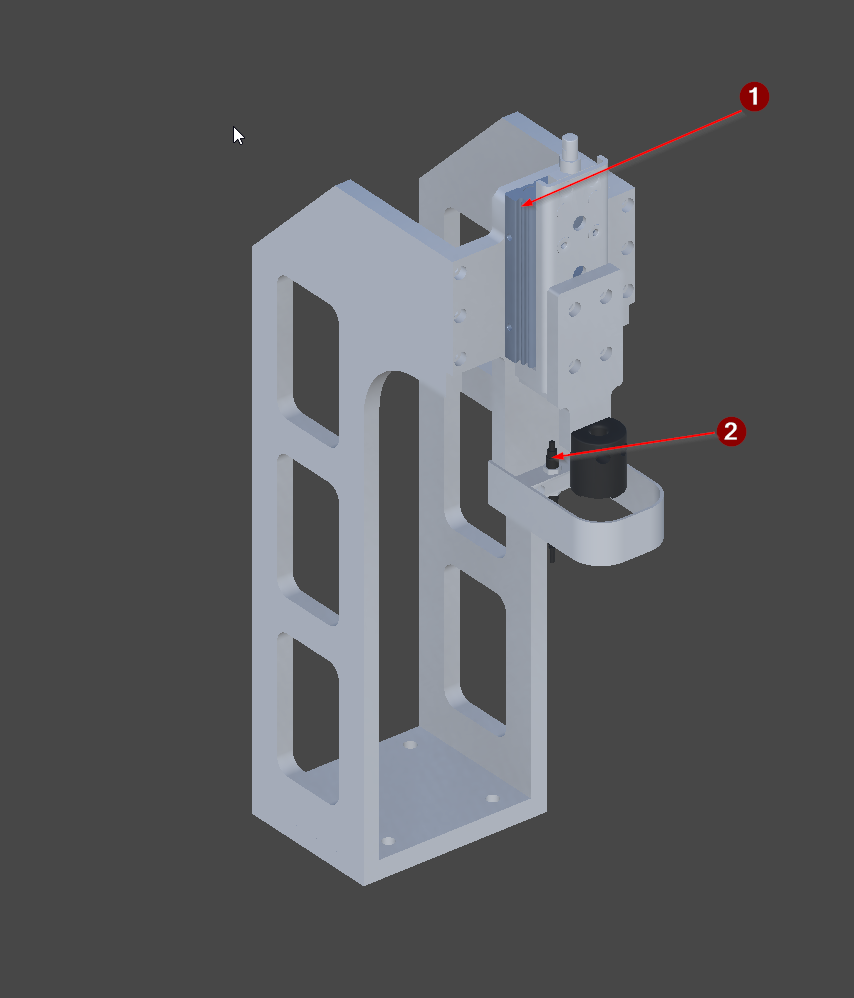
The FG_04 press station, isolated.
| # | Device | Type | Twin FB | Twin PLC path | What it does |
|---|---|---|---|---|---|
| 1 | Y_AxisZ |
Cylinder | FB_Cylinder |
MAIN.FG_04.Y_AxisZ |
Press cylinder. Strokes down to seat the part in its slot, holds 1 s, then retracts. |
| 2 | B_NIO |
SignalBinary | FB_SensorBinary |
MAIN.FG_04.B_NIO |
Not in order signal for the press. PartPressDetector raises it when the press cylinder has reached its bottom limit but the seating sensor sees no part - press completed with nothing correctly seated. |
# is the numbered arrow on the figure above.
The twin path is not the control path. A control platform spells these devices differently - it may fold a twin child into its parent unit, or address it from another root entirely - and only the control spelling works in a binding or a link, where the twin's fails silently. The verified control path for each row is on the vendor page linked below.
None.
The scene tree. The comment on each line is what the node is; † marks one that differs between scenes.
Y_AxisZ:   # Cylinder
Axis_Z:    # grouping, not a device
B_NIO:     # SignalBinary
Sensor: # SensorBinary · simulation only, no PLCTwin animation: SequenceUnit4.cs — behaviour contract is in transport-behaviour.md
Simulation only - they talk to no PLC at all:
-
Sensor(SensorBinary)
Y_AxisZ — MAIN.FG_04.Y_AxisZ · Cylinder
- Signal — Double solenoid with both limits read. EXTENDED presses down onto the part; retracted is clear. A double solenoid so an abort leaves it where it is.
Axis_Z — `` · not a PLC symbol
- Function — Kinematic axis carrying the press head down onto the part and back up.
- Twin — OC Axis driven by the Y_AxisZ cylinder. The seating verdict does not come from here - PartPressDetector raises B_NIO.
B_NIO — MAIN.FG_04.B_NIO · SignalBinary
- Signal — A VERDICT, not a sensor reading. Active means the press bottomed with nothing correctly seated. Only meaningful at the bottom limit with the hold expired.
Sensor — MAIN.FG_04.Sensor · SensorBinary · not a PLC symbol
- Function — Seating sensor under the press. Detects that a part is present and correctly seated.
- Signal — Not a PLC symbol - its Link is disabled. It feeds PartPressDetector locally, which publishes the result to the PLC as B_NIO.
The twin is master for structure, and that is all this page states. The control module, the twin device layer, the verified control PLC paths and the terminal mapping is the control platform's own knowledge base:
- Beckhoff
- Siemens — no knowledge base published yet